Anyone know a cracked engineer-in-the-making looking to intern on AI writing kernels for Waymo’s custom inference accelerator introduced at hot chips?
Lots of new problems, unlimited token budgets. Proof of work more important than credentials.
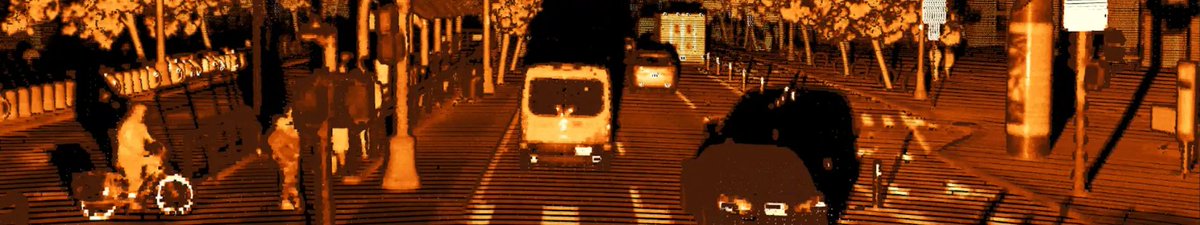
This is the output from our custom high speed lidar proceeding chips - before we do any ML. Beyond range, we track intensity, elongation and other metrics that give us an image like this - night or day.
After almost a decade at Waymo, I’m thrilled to publicly share a small glimpse of our work. Our sensor fusion chip makes real time decisions possible for the Waymo driver.
More technical details in my talk @hotchipsorg on Monday.
We’re putting our chips on the table. Learn more about our approach to engineering compute for fully autonomous driving and how we collaborate with industry leaders including AMD, Micron, NVIDIA, Samsung, Sandisk, Socionext, and TSMC to build the most capable computing system on the road: https://t.co/GlZZhBrw3F
Ten years after his Hot Chips keynote on silicon in self-driving cars, Daniel Rosenband returns with a new look at the road ahead.
Don’t miss his Waymo keynote:
“Compute in Motion: Challenges of Autonomous Driving.”
@0xBADB01E Sadly no one makes LP6 PHYs at N6. N6 is ironically a better choice for shoreline vs N3 as you’ll need at least 0.5x reticle for what you want or chiplets.
@jackcookjack Cool work! The paper shows how a hardware dot product unit can be designed for quantized values but the output quantization can take a non-trivial number of cycles - determine FP4 vs I4, doing bit manipulation for the signaling etc. What’s the overhead?