I am teaching LeRobot to pickup a pen, draw a square and put the pen back. It’s difficult to work with the cheap hardware, but its still absolutely amazing what you get for just a couple hundred dollars. This was the first episode
This is an example for remote controlling the robot via https://t.co/3P2sArhPLm💫
uncut, real-time, no filter. just screen recording myself controlling the robot to pick up a box and placing it on top of another box 🤖
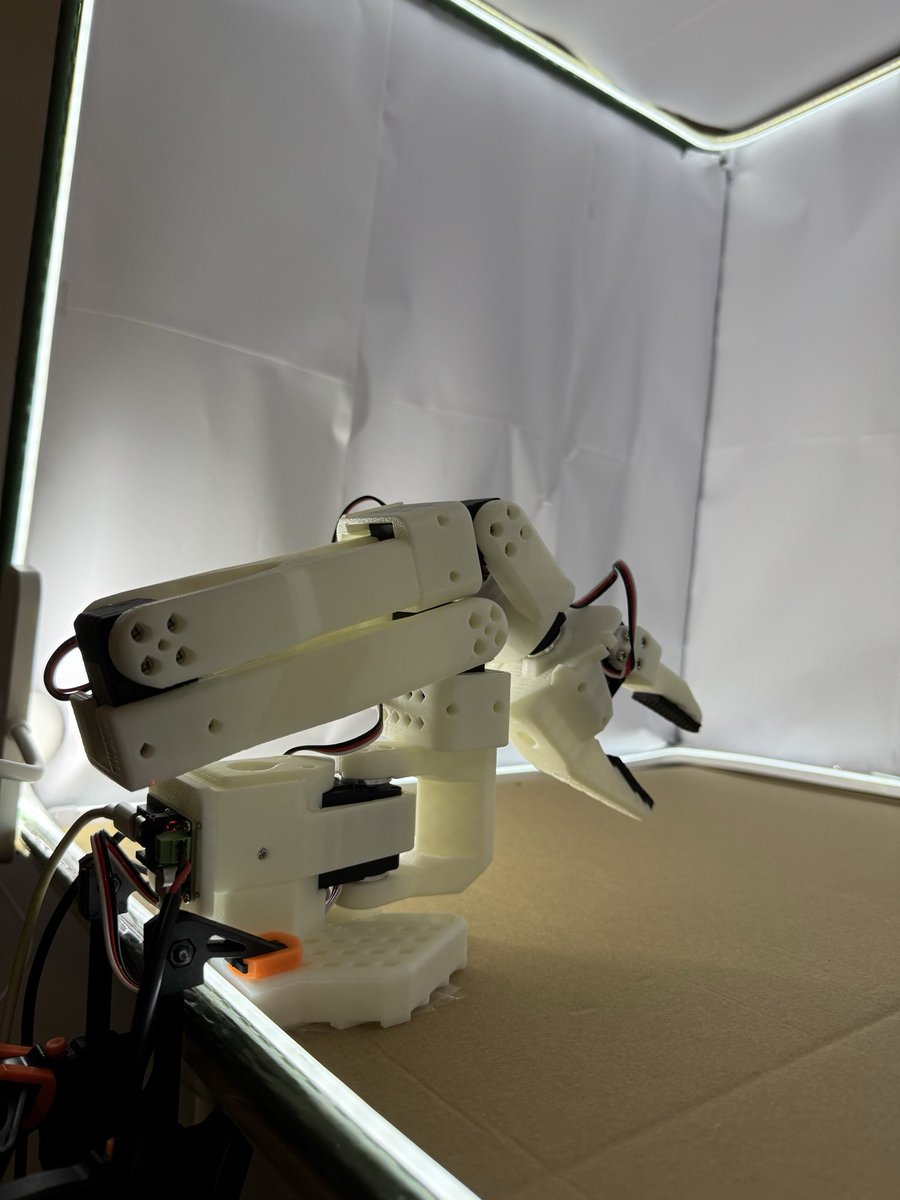
Next up: Preparing my SO-101 for autonomous tasks. 🤖
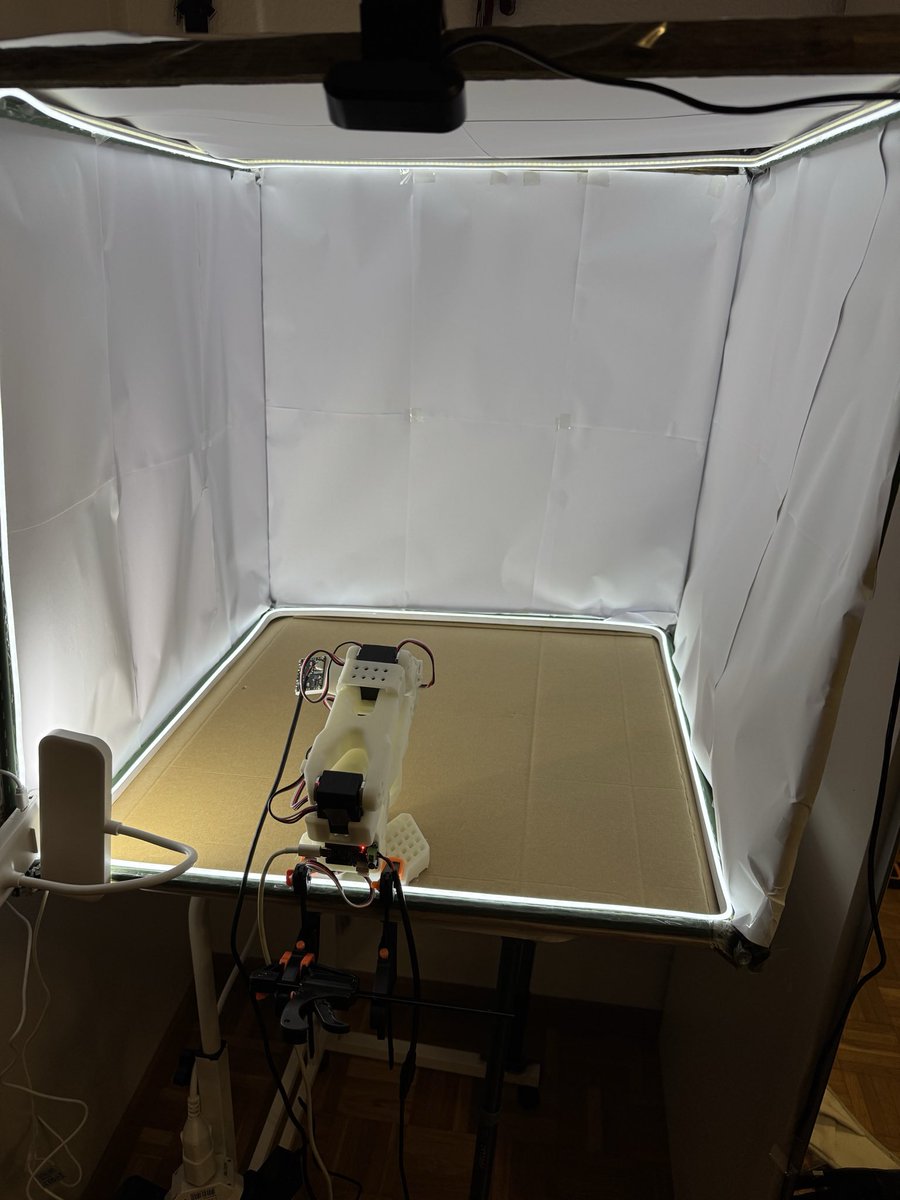
Built a simple white workspace to reduce visual distractions and create a more consistent environment for training.
Let’s see how well it works! 📦
robots are cool. i built a website for mine. the video feed is live. for now you can only trigger a simple movement. fully deterministic for now..
➡️ https://t.co/3P2sArhPLm
what would you like to see?
🤖 Built a web app to livestream and remotely control my SO-101 robot arm.
Two control modes:
- Direct joint control
- Cartesian control using inverse kinematics (IK)
One step closer to making my robot accessible from anywhere. 🌍
i got astra to move boxes inside a bowl under different lightning. it can recover from failures itself. but it takes ages to complete a run. sometimes 90min, i really need to improve on that. the goal is 30seconds. and what nobody tells you its ofc burning through lots of tokens
ditching the current imitation learning approach and letting #astra take over. currently calibrating the cameras. could be very interesting to use smart models for error recovery where latency, price and co are less relevant
i gave astra a robot, a paint brush, and a camera then asked it to paint the golden gate bridge in real life!
it figured out how to control the robot, and progressively got better throughout its attempts. the timelapse is sick
training failure recovery was more difficult than expected. the model learned from the failure recovery episodes and then didnt correctly aim at the boxes anymore
somehow lerobot was struggling to pick up boxes in some scenarios. to fix this i recorded episodes on failure recovery. this should help him understand and recover from his mistakes. currently the policy is being trained. cant wait to see after its done
@cdngdev imitation learning is over. if you think about it, humans dont need someone to demonstrate a task 50 times in order to learn it. once or twice is usually enough. i am trying similar experiments with my SO101 now
here some more cool impressions from the #allaboutautomation that took place around 2 weeks ago in zurich. these machines are really advanced and expensive. quite the contrast to the current state of #physicalai
had to postpone this setup. it requires a way better gripper. visible in the video too. so i am starting with an experiment to place boxes in a bowl. once this works reliably the next setup is maybe a dinner serving robot fully mounted on the dinning table of the shared flat 🤣
I am teaching LeRobot to pickup a pen, draw a square and put the pen back. It’s difficult to work with the cheap hardware, but its still absolutely amazing what you get for just a couple hundred dollars. This was the first episode
training the new more robust policy with error recovery takes so long in google colab. its literally running for a day now on an nvidia tesla t4, because it crashed a few times and progress was lost