Mobile ALOHA's hardware is very capable. We brought it home yesterday and tried more tasks! It can:
- do laundry👔👖
- self-charge⚡️
- use a vacuum
- water plants🌳
- load and unload a dishwasher
- use a coffee machine☕️
- obtain drinks from the fridge and open a beer🍺
- open doors🚪
- play with pets🐱
- throw away trash
- turn on/off a lamp💡
Project website: https://t.co/9rzIX8wLEp
Co-lead @tonyzzhao, advised by @chelseabfinn
(amazing photographing from @qingqing_zhao_ )
We deploy OM-1 on more humanoid tasks in both indoor and outdoor environments. OM-1 can power humanoids to do useful things robustly that other models or form factors cannot.
- last-mile delivery from a Cybertruck
- manipulation on stairs
We stress test OM-1 on last-mile delivery for packages from Amazon, Walmart, DHL, etc in different positions and orientations. Our model can reactively adjust, and let humanoids climb, navigate together with whole-body approaching, and hold packages firmly while climbing down.
We deployed OM-1 across an expanding range of humanoid tasks, both indoors and outdoors.
From last-mile delivery out of a Cybertruck to manipulation on stairs, OM-1 enables humanoids to reliably tackle useful real-world tasks that other models or form factors struggle with.
We deploy OM-1 on more humanoid tasks in both indoor and outdoor environments. OM-1 can power humanoids to do useful things robustly that other models or form factors cannot.
- last-mile delivery from a Cybertruck
- manipulation on stairs
We found a way to scale humanoid control that reduces GPU-hours by more than 1000×.
Across 129,514 motions, SuperMimic surpasses the state of the art (128 GPUs, 7 days) with 1 GPU in 3 hours.
Project: https://t.co/6gc9WKm9qY
Demo: https://t.co/OHRvx5ogQY
The only AGI on Earth emerged after billions of years of "physical self-play". Robots won't be any different.
This method scales, and we will scale it.
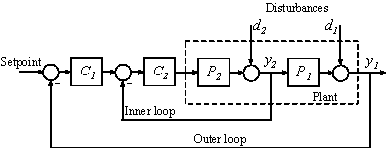
this reminds me of classic cascaded control: the outer loop outputs setpoints or trajectories, while the inner loop runs much faster and handles the low-level dynamics. For fast actions, waypoints alone aren’t enough—velocities and contact feedback matter too. Impedance control is a useful analogy: instead of rigidly following a path, the robot responds to contact like a spring and damper. IMO, getting this interaction right is one of the keys to fast, smooth motion.
a big challenge in building a generalist robot is the outer loop: mapping language& images into possible trajectories. A lot of the attention in robot AI goes there and stops there. RewardAI says that picking a good trajectory is only part of the problem; executing it smoothly when contact and loads change is just as important. The team is very serious about robotics, impressive and congrats.
Introducing OM-1, our first robot foundation model: zero-shot generalizing across table-top arms, industrial arms, and humanoids.
- Learned directly from human manipulation data
- No teleop or robot data
- Near human-level dexterity and efficiency
- Multi-robot collaboration
Introducing OM-1, our first robot foundation model, zero-shot generalizing to any robot: table-top arms, industrial arms and humanoids.
- learned directly from human manipulation data
- no teleop/robot data
- close to human-level dexterity and efficiency
- multi-robot collab
This is huge! 🤯
Reliance on real robot data and cross embodiment are big issues of robotics action models! Super excited to see OM1 solving both of them!
The motion is also fast and looks smart!
Great work @zipengfu@chenwang_j!