Real-time bilinear perspective correct texture mapping with bilinear perspective correct dynamic lightmaps in 1994. Showing a demo to Carmack and Abrash is why I have a "special thanks" in the Quake credits.
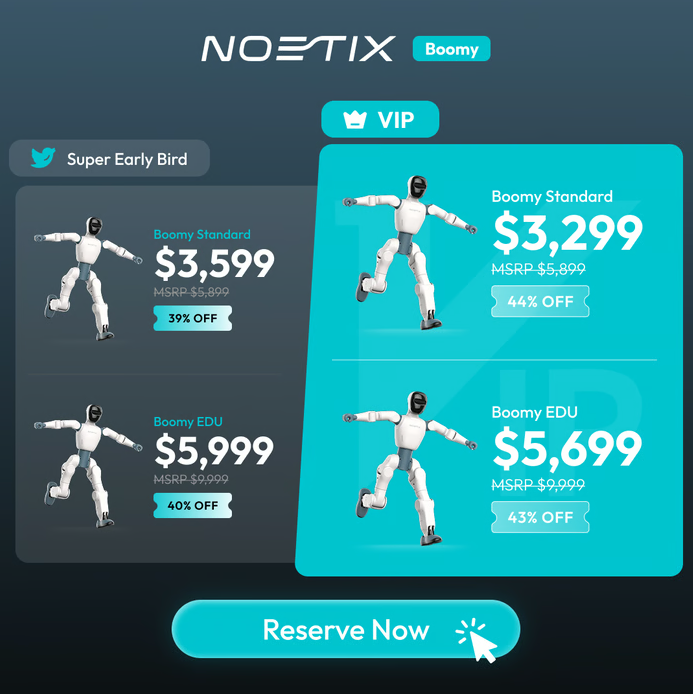
Neotix kickstarter just dropped.
Never signed the agreement to get my LUMOS NIX from their Edge Program for "reasons", but this one looks mod open.
Open access to a Boomy would be super handy right now considering all the whole body RL teleop work I am doing at the moment.
🤖 Meet Noetix Boomy — Your First Programmable Humanoid Robot.
Built to move, interact, and bring your ideas to life.
From bipedal motion and built-in actions to open programming and customization, Boomy gives you the freedom to explore, create, and make it your own.
🚀 Code It. Mod It. Make It Yours.
Coming soon on Kickstarter!
🔔 Follow our Kickstarter pre-launch page and get notified when we launch: https://t.co/y9PnQQ7cdw
#NoetixBoomy #NoetixRobotics #HumanoidRobot #ProgrammableRobot #Robotics #EmbodiedAI #Kickstarter
I've got 10 outstanding orders and I get one everyday.
I had a student to help me assemble them and he's doing a fantastic job.
The current lead time is about 4 weeks
https://t.co/1PJvFdtnJX
Stringman is $795. But after Friday I'm raising the price back to $965.
first impressions at CoRL2026: teleoperation is still robotics' dirty little secret. almost every humanoid demo on the floor was teleop. @Tesla_Optimus just waved, controlled from behind the curtain (bold choice). and watching @boosterobotics teleop technicians get trained showed just how difficult it was.
@stevenuecke Like a physical passive damper or driven? I just want to get rid of as many motors as possible for cost/weight reasons. I don't care if my robots can do backflips, just basic robust locomotion.
I was thinking of trying to get away with deleting ankle invev (roll) and was curious how well Sprout dealt with it, but after watching this I think it will at least have to be passive.
"It is a common misconception that if you have two otherwise identical electric motors, one with a low Kv and one with a high Kv, the lower Kv motor will be capable of producing more torque with less waste heat."
https://t.co/A0gfuK46M9
KV in motor explained! This is too confusing!
KV isn't kilovolts. The V stands for velocity: KV is the motor's velocity constant, the rpm it spins per volt with no load.
Power in is volts times amps. Power out is torque times speed. So torque per amp equals volts per unit of speed, which is 1/KV.
Fix the units and you get Kt ≈ 9.55/KV in N·m/A, the textbook relation. ODrive's docs call KV and Kt "two sides of the same coin".
Back-EMF and torque come from the same coils in the same magnetic field.
Real-time bilinear perspective correct texture mapping with bilinear perspective correct dynamic lightmaps in 1994. Showing a demo to Carmack and Abrash is why I have a "special thanks" in the Quake credits.
i found the optimal first interview question, difficulty: impossible
tell me about one concrete action in your career, in a way where I can understand why it is impressive given what you knew at the time. use as few words as possible
It's been a while, but we've got a new moteus to announce, the moteus-r5. This is a "spiritual successor" to the moteus-r4, first released in 2020 using everything we've learned in the last 6 years. Smaller, lighter, more capable, and cheaper!
https://t.co/9SXRWE7eR4
Nice. I was working towards something like this except I was going to allow for variable number of trackers. Now I have a nice inspirational baseline plus their comparison of other implementations in their technical blog.
Archon Robotics introduced Anchor 1, a whole-body controller for humanoid manipulation.
It turns sparse human targets (pelvis, wrists, ankles) into precise, stable robot motion, skipping online joint-space retargeting to avoid a common source of error.
It also separates motion encoding from feedback correction, pairing accurate tracking with smooth movement.
On a real robot, Anchor 1 posts the lowest tracking errors and highest task success against baselines including MimicLite, ScaleBFM, and SONIC, and collects teleoperation data more efficiently.
Weights and deployment code expected late 2026.
btw. Using https://t.co/yaT5iTxCNd for the volume raycasting. Very easy to make a viewer much nicer than the very basic one that ships on the scans DVD. Also you can customize it exactly for the findings.
Of course I had to make it work with the graphs! Added an external_roots concept so I can keep the data and custom nodes outside of robot_tycoon proper.
Will be using it as my main source of organization for the sidequest. Dogfooding FTW.