1/ Excited to announce that I’ve joined @BitRobotNetwork as COO!
Physical AI is the next disruptive platform shift. Crypto primitives enable global collaboration + open-source advancements in robotics. BitRobot is the platform to make this happen.
Heading to Singapore for @token2049?
Our co-founder @micoolcho will be on the stage at Solana Consumer Day to share how we're crowdsourcing robotics research and development on @solana
Thanks @SuperteamSG@SuperteamAU@SuperteamBlack for hosting this summit! RSVP below
Day 2 @ieeeiros recap in the competition area
Crowds gathered to watch participating teams attempt new benchmarks in dexterous manipulation, long-horizon loco-manipulation, and auto-navigation.
Results from the 1st BitRobot Grand Challenges will be shared soon 👀
Excited to co-organize the Origami Grand Challenge with @SharpaRobotics at @ieeeras IROS next week.
Sharpa builds advanced dexterous robotic hands and embodied AI models.
Over a dozen teams will put their policies to the test by autonomously folding a paper airplane.
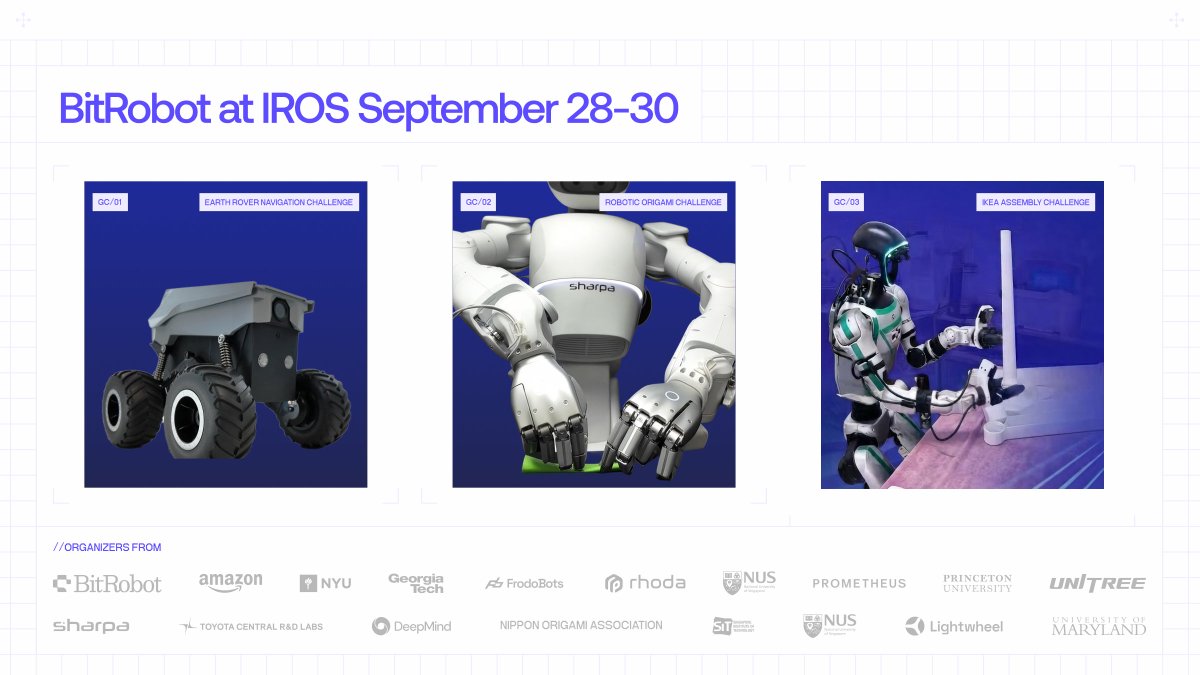
Next week, we’re heading to @ieee_ras_icra IROS 2026 in Pittsburgh with 50+ research teams pushing the frontier in 3 Grand Challenges:
> Autonomous navigation w/ Earth Rover
> Dexterity thru origami folding
> Loco-manipulation thru Ikea assembly
Excited to organize this w/ partners like @SharpaRobotics@LightwheelAI@UnitreeRobotics and more.
Earth Rover Mini+ spotted in-the-wild with @Meta Muse on board, building its own perception-to-action stack 🤯
Muse was told to find a black ball. So it installed PyTorch + Depth Anything itself, estimated the distance, then drove the rover.
Agentic robotics is getting real.
We’re building human-centric robotics from the data layer up, the missing piece for generalist robots.
RoboCap + Grounded API turn raw human action into metric 3D labels ready for training.
The hardware and the tooling have always been fragmented. We built them as one stack ↓
Great ego data at scale requires hand tracking to succeed in difficult in-the-wild scenarios, not just in carefully collected settings.
Here are some examples of our hand tracking in the tricky long-tail:
Today, we're announcing GSI and launching the foundational layer for the most scalable source of real-world robotics data: 3D models that extract manipulation data at scale from RoboCap, a 250g 6-camera hat.
Almost a decade ago, I was a freshman at Stanford who had just heard about AI. It posed an irresistible challenge to me: find a single algorithm that can match human intelligence. I was fortunate to meet someone with the same vision: @AdemiAdeniji, now my co-founder.
It became clear to me that the solution would be a well-engineered system, so I sought to learn how to create one. At Tesla Autopilot, I saw that the hardest research problems were often driven by data and formulation. The lesson stuck: great AI systems are not about research, but about the data mechanisms that align with the world.
Great robotics begins with great data at Internet scale. At GSI, we are starting with the most scalable data products for robotics.
1/ Better robot models come from better data.
That takes two things: hardware that captures it fully, and tooling that turns it into training signal.
We built the first. Today, @GroundedSI launches the second: Grounded API. Access both hardware + API ↓
Been awesome working with @GroundedSI on a purpose-built enrichment API for the @BitRobotNetwork RoboCap hardware platform
Calling all robotics builders: Buy RoboCaps and access industry leading hand-tracking, SLAM, and depth estimation in minutes ⚡️
Grounded API is live.
- SOTA on hand-tracking benchmarks (< 1 cm)
- SOTA on SLAM benchmarks
- In-the-wild ego data -> enriched data in minutes
- Integration with @huggingface@LeRobotHF & @rerundotio
- Built for @BitRobotNetwork RoboCap suite
Technical report & more↓
Better robotics models start with better human action data.
@GroundedSI is building the infra and models to unlock it at scale.
One of the sharpest teams we’ve worked with (UC Berkeley PhD, ex-NVIDIA, ex-Tesla). They emerge from stealth tmrw, give them a follow. 🦾