🚀RP1 is officially here.
🌍Putting control of robotics back in developers’ hands.
Introducing RP1 (ROBOTO 01) by RoboParty—a high-performance, fully open-source humanoid robotics platform for frontier robotics research and embodied AI model development.
🤖 Open across the full hardware and software stack:
• Robot platform: mechanical CAD, bill of materials, and assembly documentation
• Actuators: in-house ROMOMO joint designs and related technical resources
• Control: electrical systems, firmware, low-level drivers, and motion control implementations
• Development: simulation models, SDKs, data processing tools, and training tools
• Engineering foundations: technical documentation and research materials
Open the black box.
Understand the system.
Make it your own.
A deviation in motion can originate in the model, control policy, actuator response, or mechanical structure.
RP1 opens up the design and implementation of these layers so developers can trace problems, modify the system, and validate changes on real hardware.
Open-source algorithms for advanced motion control
RP1 has demonstrated continuous walking, recovery from disturbances, getting back up after a fall, and human motion tracking.
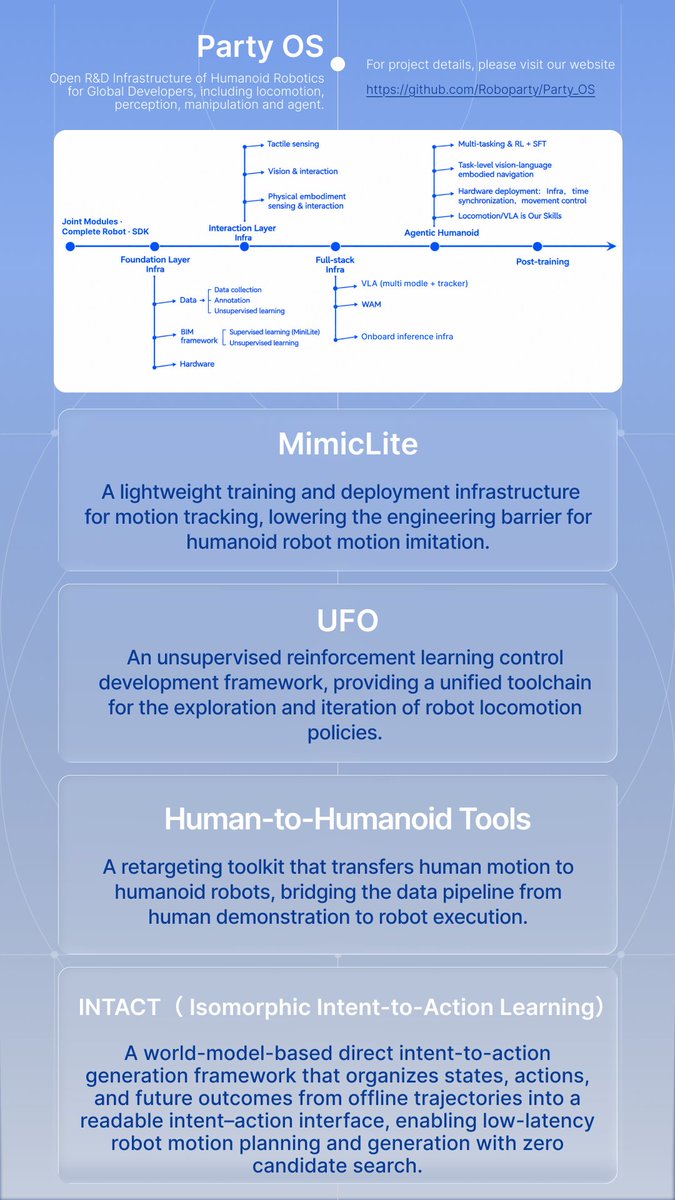
UFO and MimicLite connect motion learning, control policies, and execution on real hardware.
The open toolchain connects data collection, simulation training, hardware deployment, and experimental validation—supporting joint iteration across models, control, and hardware.
From RPO to RP1, we’re turning one team’s engineering experience into a starting point for many more.
Opening the future of embodied AI to everyone ready to explore it.
🔗RP1 on GitHub:
https://t.co/kMqFLi3eJ3
#RoboParty #RP1 #OpenSourceRobotics #EmbodiedAI
We built RP1 for robotics and embodied AI research.
Dynamic locomotion, balance recovery, whole-body control, and locomanipulation — all on RP1
Less time rebuilding the basics.
More time pushing robotics forward!!
Excited to see what the community builds next!
🔗RP1 on GitHub:
https://t.co/eWl6bwmYcH
Join our Discord community:
https://t.co/jJZS4AV00g
For ecosystem partnerships:
[email protected]
Join RoboParty and help build an open-source robotics ecosystem.
@Em_Nomadic Thanks, Emerson! We want developers to be able to inspect, modify, and extend RP1—from the software down to the hardware. Appreciate the work you’re doing at Tnkr to help more people get hands-on with open robotics 🤝
@techniahqrobot Our bet: getting all three to work reliably together. Improving one layer can reveal bottlenecks in another. That’s why being able to iterate across the stack matters. Where do you see the biggest challenge?
🚀RP1 is officially here.
🌍Putting control of robotics back in developers�� hands.
Introducing RP1 (ROBOTO 01) by RoboParty—a high-performance, fully open-source humanoid robotics platform for frontier robotics research and embodied AI model development.
🤖 Open across the full hardware and software stack:
• Robot platform: mechanical CAD, bill of materials, and assembly documentation
• Actuators: in-house ROMOMO joint designs and related technical resources
• Control: electrical systems, firmware, low-level drivers, and motion control implementations
• Development: simulation models, SDKs, data processing tools, and training tools
• Engineering foundations: technical documentation and research materials
Open the black box.
Understand the system.
Make it your own.
A deviation in motion can originate in the model, control policy, actuator response, or mechanical structure.
RP1 opens up the design and implementation of these layers so developers can trace problems, modify the system, and validate changes on real hardware.
Open-source algorithms for advanced motion control
RP1 has demonstrated continuous walking, recovery from disturbances, getting back up after a fall, and human motion tracking.
UFO and MimicLite connect motion learning, control policies, and execution on real hardware.
The open toolchain connects data collection, simulation training, hardware deployment, and experimental validation—supporting joint iteration across models, control, and hardware.
From RPO to RP1, we’re turning one team’s engineering experience into a starting point for many more.
Opening the future of embodied AI to everyone ready to explore it.
🔗RP1 on GitHub:
https://t.co/kMqFLi3eJ3
#RoboParty #RP1 #OpenSourceRobotics #EmbodiedAI
Turn one team’s work into a starting point for many more.
We invite research teams, developers, and engineering partners to join the RP1 ecosystem.
Together, we can adapt algorithms, share demos on real robots, and exchange hardware modifications—making proven engineering work easier for others to build on.
Bring a research question, an algorithm, or an idea for a practical application.
Join our Discord community:
https://t.co/BO0hCm5xgr
For ecosystem partnerships:
[email protected]
Join RoboParty and help build an open-source robotics ecosystem.
Congratulations to RoboParty’s Ye Lei on this latest work, PredActor! 🎉 Excited to see predictive action diffusion advancing steerable humanoid control.
Can humanoid motion generation and control be unified in a single policy?
PredActor uses a single end-to-end diffusion policy rather than separate motion generation and tracking. With proprioceptive feedback, it predicts internal future states and directly outputs actions at 50 Hz onboard a Unitree G1. Text-conditioned motion, joystick steering, disturbance response, and semantic interpolation are supported in the single policy.
Project Page: https://t.co/Z3epHOPo3x
RoboParty’s RP1 made its first global public dynamic showcase at #IROS2026. Powered by UFO—an unsupervised RL framework for humanoid control—and RoboParty’s full-stack hardware, RP1 points toward an open foundation for humanoid robotics. Open-source coming in October. #RoboParty
RoboParty’s RP1 took the KickMe challenge at IROS 2026.
Pushed and kicked by visitors, RP1 recovered its balance and kept moving.
Powered by UFO, an unsupervised reinforcement learning framework for discovering humanoid skills.
#HumanoidRobotics#EmbodiedAI#OpenSource
Humanoid robotics needs to be open.
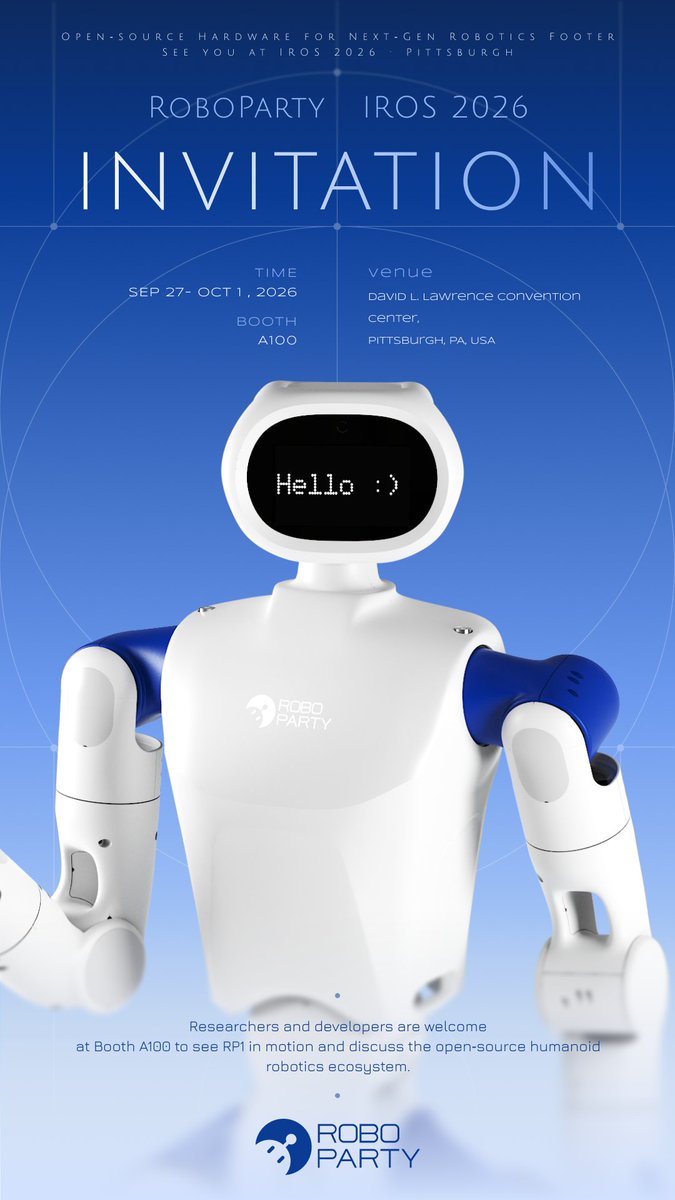
At #IROS2026, RoboParty will debut ROBOTO 01 (RP1)—a high-performance, full-stack open-source humanoid robot built for developers and researchers.
📍 Booth A100
📅 Pittsburgh | Sep 27–Oct 1
Come see RP1 in motion.