Point it, Strike it! Welcome to follow our recent work. In this work, we trained a single model in our developed wire/rope simulator DeformX 2.0 to allow a robot arm strike any 3D point with any direction! The model also supports different types of ropes, such as braided rope, plastic chains, etc.
arXiv: https://t.co/Z34oktTkEL
Website: https://t.co/T3oNcCq3Zh
There is also an interactive demo in our website, you can pick a target position and direction and see how the robot strikes the point in simulation. Try it!
A robot swings a rope and hits a falling balloon mid-air. Motion capture predicts where it will be; the policy strikes there.
Point It, Strike It: send a rope tip to any 3D point from a chosen direction. Across 25 targets on three real ropes, 87% of strikes land within 5 cm.
Thanks for the shoutout! For this work, we actually trained a policy in our simulator. This demo is from an improved version of DeformX with GPU acceleration. We trained a policy fully in sim to strike any reachable 3D point with any direction. See the project website with interactive demo: https://t.co/7MtxeGrIaI
Moving objects. Extreme illumination.
MAC-I² completes initialization and continues visual-inertial tracking in both sequences. Learned covariance adjusts how much each measurement contributes to fusion.
5/9
How dark is too dark?
The bottom-left panel shows the actual camera input: almost black. MAC-I² initializes and continues visual-inertial tracking in this dark-room demo.
Watch the transition from “Initializing” to “Run VIO.”
7/9
So cool! Reminds me of learning to ride an electric skateboard a few years ago. Took me quite a while... I definitely can't do what this robot is doing.
A first glimpse of the wildest robotics project of my PhD.
🛹 The Blind Skateboarder 🛹
No vision. No markers.
Paper, code, weights — coming soon. And we have more. 😉
Excited to introduce our new work, DeformX (Oral @ IROS 2026; Best Short Paper Award Runner-up @ SynData4CV, CVPR 2026 Workshop), a simulator for deformable linear objects such as wires, cables, and ropes.
DeformX delivers physically faithful simulation, powered by a Cosserat rod engine, alongside visually realistic rendering with CAD support and a modern rendering pipeline. It supports both visual data generation and robot learning.
Check out the demos in this thread! 🧵
Arxiv: https://t.co/gfkjHo5rUZ
Project: https://t.co/hyRvZjdJpY
A robot whips a rope to knock an apple off someone's head, using a policy trained only in simulation.
Introducing DeformX (Oral @ IROS 2026): Cosserat rod physics co-simulated with NVIDIA Isaac Sim, so cables bend, twist and collide like the real thing.
https://t.co/i4IvYcCPvR
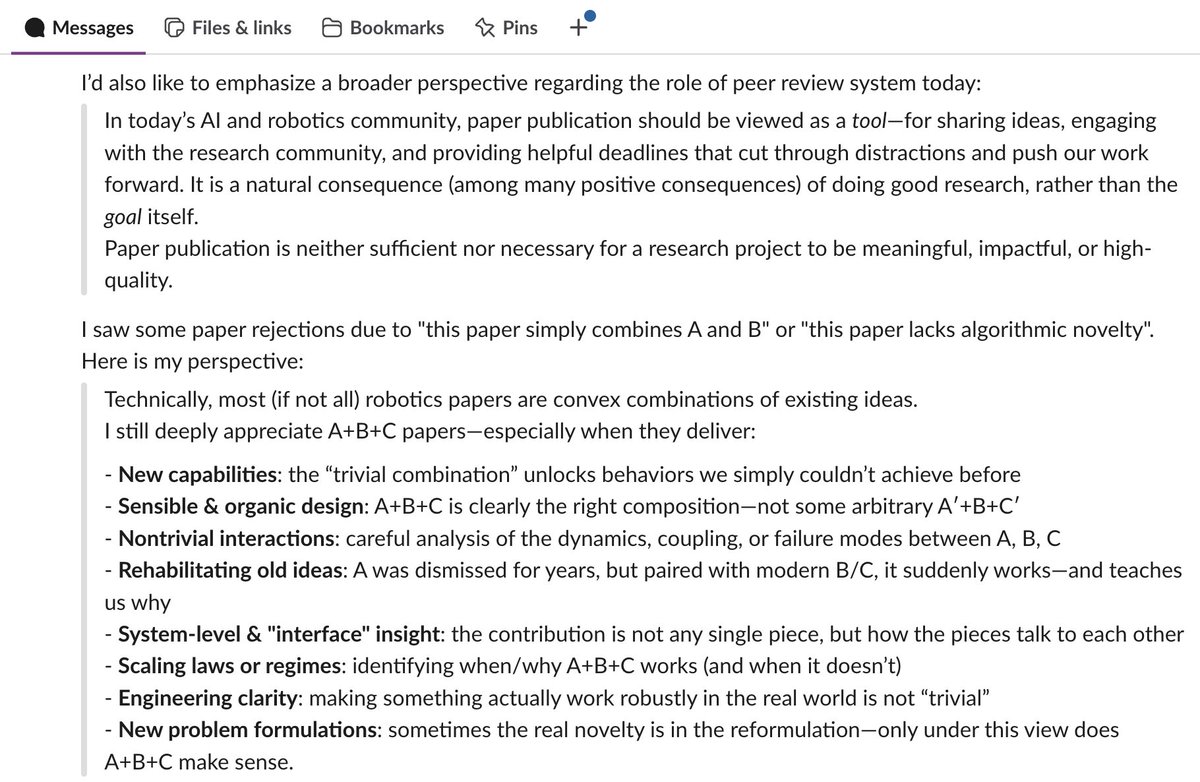
NeurIPS decisions brought joy to some and disappointment to others. My first NeurIPS paper was in 2020, but given how much AI and robotics have changed, it feels like a lifetime ago.
I’ve shared a few thoughts with my students on the role of publications and so-called “A+B” research, and I’d like to share them more broadly here.
MAC-I² learns how much to trust vision and IMU.
Metrics-aware covariance for both modalities enables robust VI fusion. We apply it to initialization and calibration in challenging scenes and motions.
https://t.co/uUiccfC2Sh
1/9
From benchmarks to real-world deployment.
Four demos: handheld motion, room-scale reconstruction, ZED point clouds and a workbench scene.
Watch the full videos on our project website:
https://t.co/uUiccfBv2J
8/9
Robots can see the world.
But can they sense themselves?
Humans don't rely solely on vision. Even in darkness, we continuously perceive motion through vestibular and proprioceptive sensing.
Today we have foundation models that understand images, language, and video. Perhaps the next frontier is a foundation model that helps robots sense themselves.
We’re honored to open the IROS 2026 Learning IMU Odometry Challenge.
Workshop: https://t.co/kaWWIjuS1H
Challenge: https://t.co/aaoq9CvsGp
TartanIMU: https://t.co/QpONZbYl8B
Discord: https://t.co/wMjCeOl6AM
#Robotics #IROS2026 #EmbodiedAI #RobotLearning #FoundationModels #Proprioception #IMU #Humanoid #SLAM