Announcing AI4Space Workshop @ CVPR 2024:
https://t.co/BeEK9EXsqU
Papers due March 1. Accepted papers will appear in the CVPRW proceedings and be presented at CVPR 2024 (Seattle). Exciting Invited Seminars by Soon-Jo Chung (Caltech and JPL) and Gianluca Furano (ESA).
Presented an invited talk on Challenges to Robotic Perception in Space at the Safe Autonomy Workshop at #RSS2023 @ Daegu. Thank you Luca and Rajat for organising this amazing event! https://t.co/uLgeIlRbkk
we extended the deadline for the #SafeAutonomy workshop at #RSS2023@RoboticsSciSys to June 12! submit your extended abstract/short paper & compete in the "Perception failure" video competition to get a $300 award! https://t.co/pnbFCcwFDj
-- with @TalakRajat,@drmapavone,TJ Chin
This new paper formalizes the need for metric-semantic hierarchical representations in large-scale robot perception and presents state-of-the-art algorithms to build #3DSceneGraphs in real-time: https://t.co/GhEtkg0YCZ
Video: https://t.co/6BlnJwfYqa
Code: https://t.co/miYkDEHYH0
"The paper is well supported by extensive theoretical results, and also by experimental results. This is a combination that I don't see often in literature. Well done to the authors." -- Anonymous Reviewer
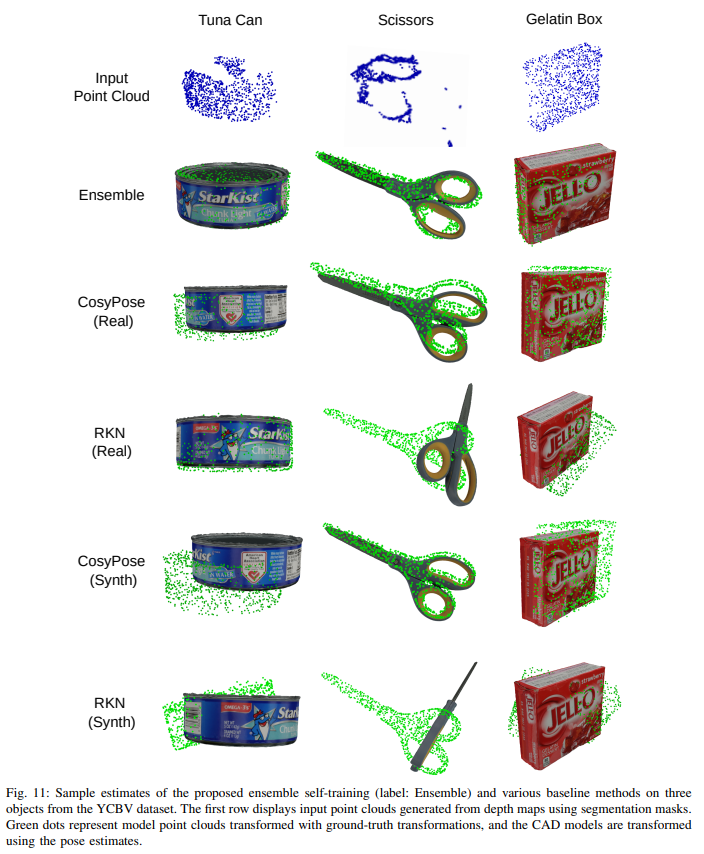
Delighted to share that our paper "Certifiable Object Pose Estimation: Foundations, Learning Models, and Self-Training" has been accepted for publication in the IEEE Trans. on Robotics@ieeeras.
arXiv Paper link: https://t.co/TP65tNJ1me
Co-authors: Lisa Peng and @lucacarlone1
The submission deadline for the #safeAutonomy#RSS2023 workshop is approaching (May 20, 2023).
Join us for an exciting discussion on safe autonomy. Show your work by
(1) submitting a short paper,
(2) participating in the deep learning fail competition.
https://t.co/A6CRa0IVs8
excited to have 2 papers accepted at #RSS2023 (@RoboticsSciSys). The first paper is on self-supervised object pose estimation: https://t.co/8QQzhBKOqU - with the amazing @jingnanshi , Rajat Talak, and Dominic Maggio. The second one will be on arxiv shortly! #mitSparkLab#robotics
We are organizing a full-day workshop at #RSS2023 on #SafeAutonomy.
The goal is to bring together researchers from diverse backgrounds including ML, CV, AI, Stats, and Robotics — and ignite a discussion toward:
1. Safety requirements
2. Methods to make robot perception safe
Was delighted to give an invited talk at the 29th National Conference on Communication held at IIT Guwahati. Sharing the video. https://t.co/FsnfbryP0f
Joint work with Vishrant Tripathi, Eytan Modiano, and @SertacKaraman
Finally, after a 3-month media silence period, we can freely talk on social media now. Our library paper got accepted to CVPR 2023. PDF is here: https://t.co/gjioG2AqDY
How to use AI models in safety-critical autonomous systems with high confidence? Join the #GTC23 session below to learn about the most recent results from the @nvidia's Autonomous Vehicle Research group: https://t.co/NjLfORExCE. @NVIDIADRIVE@NVIDIAAI
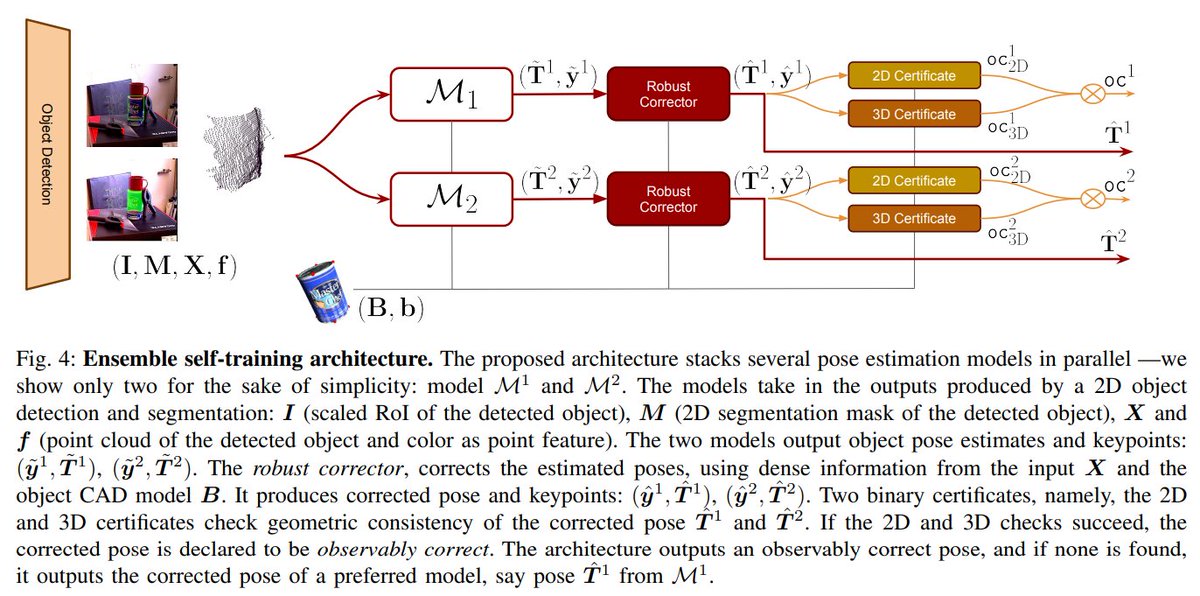
Turns out that obtaining certificates of correctness for perception enables self-supervised learning: this is our recent work on self-supervised object pose estimation: https://t.co/dqceCaUtG2 -- great work by Rajat Talak and Lisa Peng #robotPerception#computerVision#robotics
Continuing the @NeurIPSConf Robot Learning Workshop talk series, I am excited to share "A Vision for Certifiable Perception: from Outlier-Robust Estimation to Self-Supervised Learning" by @MIT's amazing @lucacarlone1 & @TalakRajat 1/2 https://t.co/SmtSuT5WZ2