In case the cicadas haven't told you, fall is just around the corner.
See what we've done this summer!
Read the latest Michigan Robotics newsletter:
https://t.co/eFaJIMa6iW
Are you ready to join the faculty of the University of Michigan Robotics Department?
We're looking for a new Department Chair and tenure-track faculty.
Find out more and apply:
https://t.co/xTeCm1pFHW
We invite applications and nominations for the position of Department Chair.
Find out more about this position and tenure-track faculty positions:
https://t.co/xTeCm1p7So
We invite applicants to join our mission to accelerate advances in robotics for the benefit of society.
We're looking for a new Department Chair to lead in defining the discipline of robotics.
We're also hiring tenure track faculty.
Find out more:
https://t.co/xTeCm1p7So
We're looking for a new Department Chair.
And tenure-track faculty.
Join us in our mission of creating the next generation of robotics and roboticists as force-multipliers for the benefit of society.
Learn more and apply: https://t.co/xTeCm1pFHW
Join our faculty!
@UMRobotics is searching for both:
• A new Department Chair to lead and shape the future of robotics.
• Tenure track faculty in the area of Human-Centered AI.
Get all the information and apply: https://t.co/xTeCm1p7So
SKF is accepted for @NeurIPSConf as spotlight!
Wow, I didn't expect it. Kudos to AC and reviewers for valuing basic research. We feel extra rewarded and motivated!
NEW ARTICLE: “Small robot propulsion: low-power twisting enables hopping, swimming.”
The mechanism works on challenging surfaces such as slippery cloth and grass-covered ground, producing frog-like motion. https://t.co/RqRgtviqnS
Big congrats to @XinYe_Eva on our new paper, Mitigating Human–Security Robot Conflict Through Fairness. We found that distributive and informational fairness reduce conflict and boost security robot acceptance.
@umsi@UMRobotics@BlackInRobotics
https://t.co/awSZ07prpz
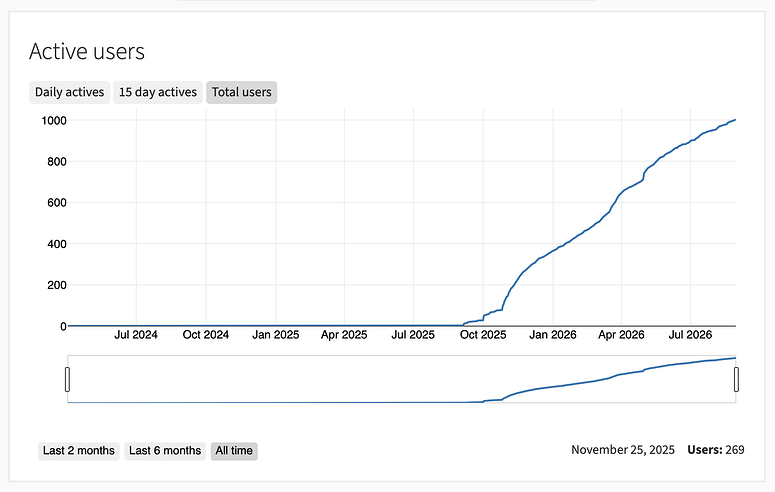
We just hit 1000 users on our Open Robotics @zulip server.
Zulip is our open source alternative to Discord.
We migrated late last year and the experience has been nothing short of fantastic; no bots, no spam, and threaded conversations!
⬇️⬇️⬇️
It's not yet September, but we have #IROS2026 on the mind.
Get tips for visiting Pittsburgh and the latest robotics research from Michigan roboticists in our IROS summary.
Read:
https://t.co/YvOTJyvRAN
We locally calibrate uncertainty in approximate dynamics models! By conditioning on latent observation embeddings, states, and actions, we enable uncertainty-aware planning in u̲n̲s̲e̲e̲n̲ test environments!
More on this @wafr_conf paper w/ @TheLuisMarques@UMRobotics below ⬇
The University of Michigan put their entire robotics degree on GitHub.
Not one course. The whole curriculum.
ROB 101 — Computational Linear Algebra for Robotics
ROB 311 — How to Build Robots and Make Them Move
ROB 501 — Mathematics for Robotics
ROB 530 — Mobile Robotics
Every lecture video on YouTube. Every textbook on GitHub. Every problem set, every exam, every line of code.
Professor Jessy Grizzle said it best when they launched it:
"Linear algebra has become the language of computer vision, machine learning, robotics, and autonomy."
So instead of making students wait four semesters of calculus before touching a robot... they built a curriculum that starts with the math that actually matters, applied to real robotics problems from day one.
This is what open education looks like when a top-10 engineering school decides to mean it.
Free. GitHub. YouTube.
📌 [https://t.co/3STu1hzAz2]
Follow for more robotics resources!
——
Weekly robotics and AI insights.
Subscribe free: https://t.co/9Nm01QUcw3
What if robot hands could acquire dexterity once, then reuse it to learn downstream tasks much faster?
Introducing ADEPT: a pre-training & post-training paradigm using RL entirely in sim, then zero-shot deploying visuo-tactile policies in the real world.
🔗https://t.co/jdIR1CnG4c with Dex team @NVIDIAAI