@zhanpeng_he Very cool! Can the policies you train with this system still use the full 5 fingers of many dexterous hands even without recording data from the ring and pinky?
Proud of this one! Geometric alignment between human and robot data feels like a key piece of making cheap, scalable human data more useful for robot learning. Great working with Julien, @MattStr10050461, and team!
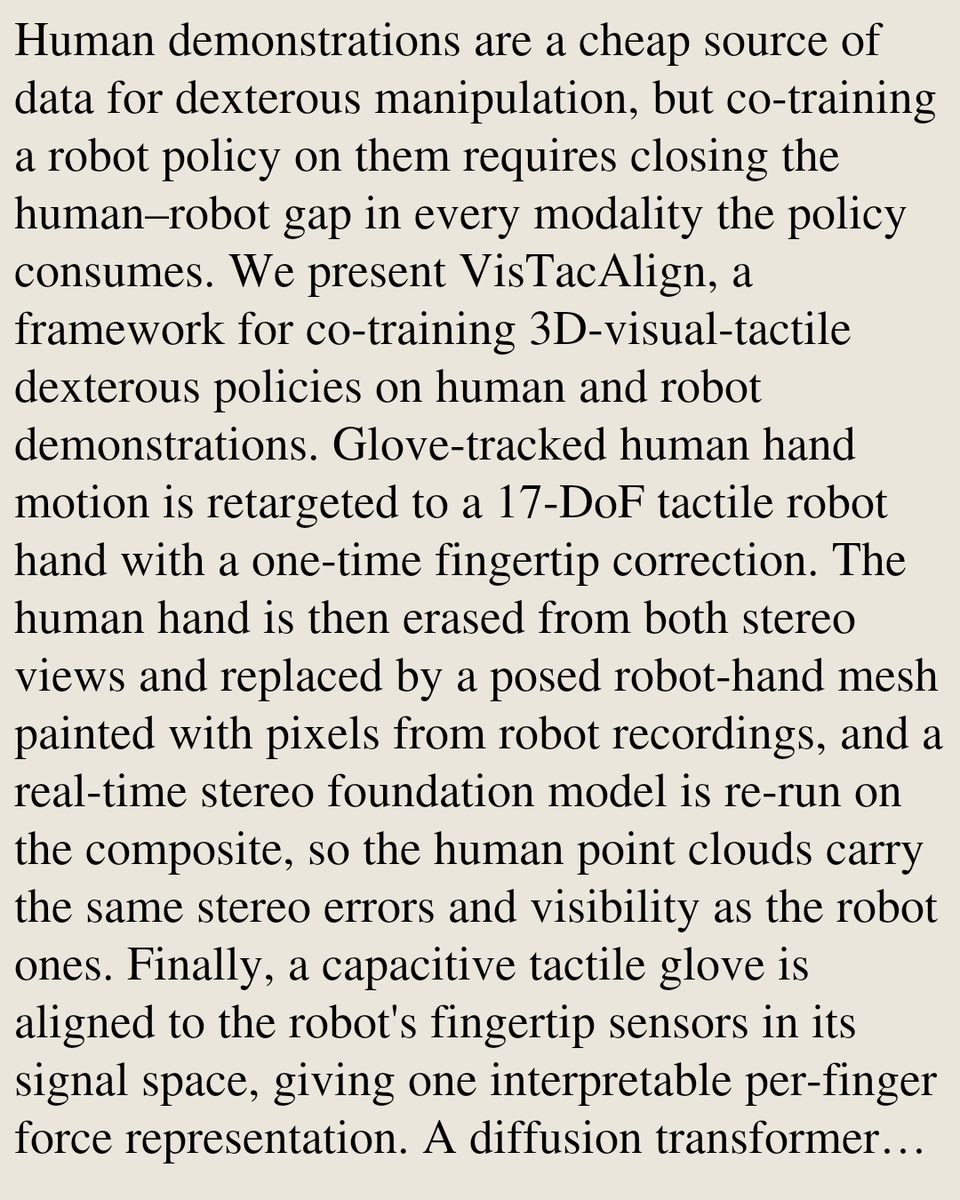
Introducing VisTacAlign 👁️👆📐: co-training dexterous policies on human demos collected with a different tactile sensor than the robot’s.
How we align vision and touch so cheap human data actually helps the robot! 🧵
Introducing VisTacAlign 👁️👆📐: co-training dexterous policies on human demos collected with a different tactile sensor than the robot’s.
How we align vision and touch so cheap human data actually helps the robot! 🧵