Frontier models too slow for robots?
Can't simulate every possible scene?
Frontier models already understand the world. We turn their reasoning into risk images. RL policies trained in sim on randomized risk, not rendered RGB, act on them in real time.
No motion capture. No tethers. Just onboard perception and reinforcement learning taking on the real world. Watch our vision-based policy handle noisy depth streams and intermittent visibility to roll, upright, and re-orient tires in an unmapped skatepark and learn how we built and trained this onboard system: https://t.co/8HfenhSfc2
It's been an amazing two years being part of the controls effort for the Ultra Mobility Vehicle. Today we can share a more elaborate treatment on the design of this robot and a preview of our controls effort!
While legged robots navigate unstructured environments well, their high energy use and low speeds can hinder longer journeys. Wheeled robots offer efficiency but can struggle with obstacles like curbs or stairs. To bridge this gap between speed, agility, and terrain versatility, we introduced the Ultra Mobility Vehicle (UMV), a single-track bicycle robot that combines wheeled efficiency with dynamic articulation.
Learn more about UMV's system design and how Reinforcement Learning (RL) is applied to control bike jumps, flips, bunny hops, and more in the October 2026 issue of @SciRobotics https://t.co/c3Sdkq7LZp
Happy #IROS2026! Stop by the RAI Institute booth #1102 to grab some stickers and check out some of our custom-built robots including the UMV, Roadrunner, and Koala grippers.
You can also catch Roadrunner in action in the robot demo area. Check the Exhibit Hall demo schedule for more details!
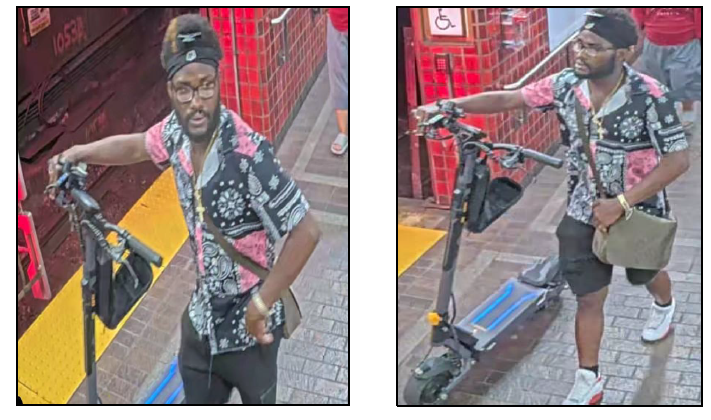
ID Sought re: Assault & Battery DW-Knife 7/11 630AM #MBTA Charles MGH. Recognize this person of interest? Pls contact our CIU at 617-222-1050 w/any info you may have. You can remain anonymous. TY
CRAFT hand🫳
1. Achieves all 33/33 dexterous grasps > 2x-20x $$ hands!
2. < $600
3. Handles fragile objects
4. Durable under contact
5. Open-sourced https://t.co/lCBAeklcVn
@leo_lin6 & @shivanshpatel35 (on market; hire him🚀) will happily share anything else that you may need. Details in 🧵
🌟 Big shout out to @kenny__shaw (Leap & v2), @irmakkguzey (RUKA), @orcahand (ORCA), and many others who helped build this open research community. Thank you!
Meet “Roadrunner,” a new 15kg (33 lb) bipedal wheeled robot prototype featuring multi-modal locomotion: side-by-side and inline wheel modes and and stepping. Its symmetric legs articulate at the knee for obstacle avoidance.
It was great to see our name amongst the other “AI Native” companies during @Nvidia’s #GTC keynote. NVIDIA Isaac™ Lab helps us train reinforcement learning policies that enable the UMV to drive, jump, flip, and hop like a pro!
Announcing our new partnership with @BostonDynamics! We're teaming up to advance humanoid robotics through reinforcement learning.
Learn more — https://t.co/75rWGjIW3t
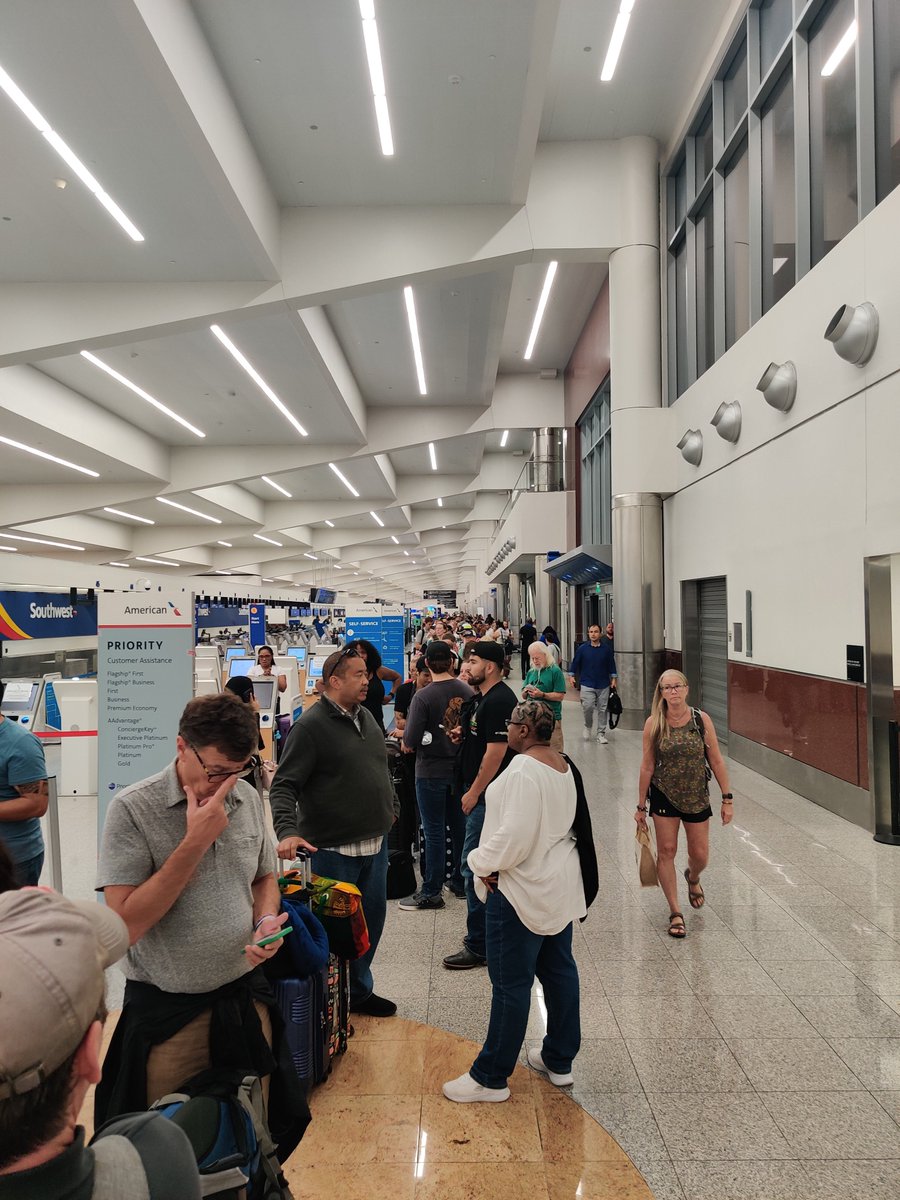
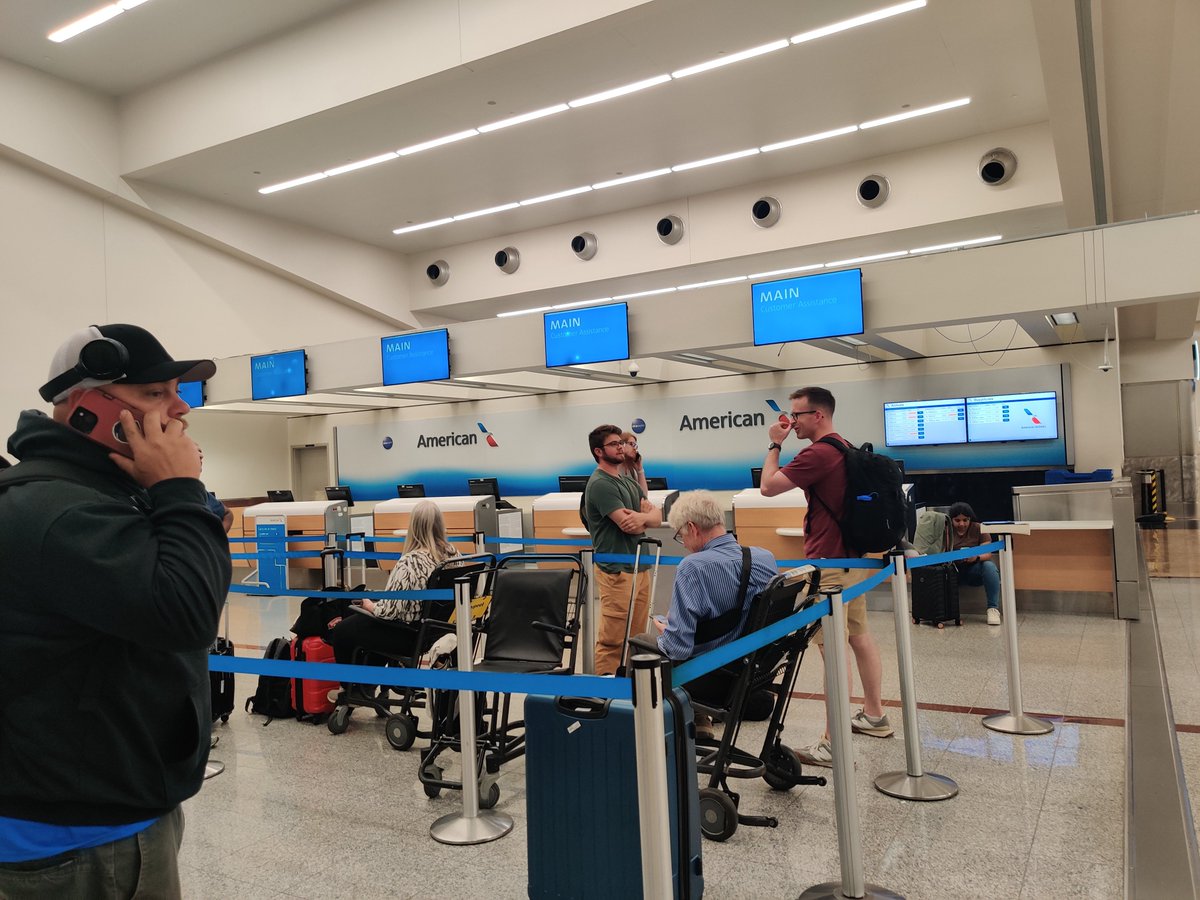
@AmericanAir has down right horrible customer service.
Stranded at Atlanta airport for 4 hours after flight to Charlotte got diverted. Takes an hour for a customer service representative to show up at the counter. Finally only one shows up to rebook 2 full stranded flights.
A professor at @iitbombay & docs in @TataMemorial developed a #cancer therapy over 7 yrs. Large pharma firms scoffed. Today, 98 patients have received the drug,50% show +response. Global scientists are shocked. How did they manage ? What’s their story? I find out @livemint