Coffee in one hand, a door in your way. You bump it open with your elbow. Can a robot do that? 🤔
We introduce WACL, which learns whole-arm manipulation from human demos. No teleop or simulation. Zero-shot transfer to a new robot. Thread 👇
https://t.co/kC1XBkrxij (1/9)
To learn more, check out our paper and chat with us at CoRL 2026 next week!
Huge thanks to @daniel_t_seita and @ebiyik_, USC LiraLab 💛
📄 https://t.co/kBmli8WWac
🌍 https://t.co/kC1XBkrxij
CoRL 2026 Austin, Poster Session 3 #58, 11/11 10:30 am. (9/9)
Coffee in one hand, a door in your way. You bump it open with your elbow. Can a robot do that? 🤔
We introduce WACL, which learns whole-arm manipulation from human demos. No teleop or simulation. Zero-shot transfer to a new robot. Thread 👇
https://t.co/kC1XBkrxij (1/9)
Does it transfer to another robot? 🤖
We swapped the xArm for a Franka FR3. Same policy, same human demos, no new data. With the robot-agnostic abstractions, WACL generalizes zero-shot to the FR3, with a 68% success rate under constraints. (8/9)
A reward model that works, zero-shot, across robots, tasks, and scenes?
Introducing Robometer: Scaling general-purpose robotic reward models with 1M+ trajectories.
Enables zero-shot: online/offline/model-based RL, data retrieval + IL, automatic failure detection, and more!
🧵 (1/12)
Life update ✨
I’ll be joining @umdcs as faculty starting Spring 2026!
I’m looking for motivated students (undergrad, MS, PhD) and postdocs interested in robotic manipulation, tactile sensing, and learning-driven hardware design.
Excited to build my group at UMD—let’s connect!
How do we unlock the full dexterity of robot hands with data, even beyond what teleoperation can achieve?
DEXOP captures natural human manipulation with full-hand tactile & proprio sensing, plus direct force feedback to users, without needing a robot👉https://t.co/rjfQ9nzofm
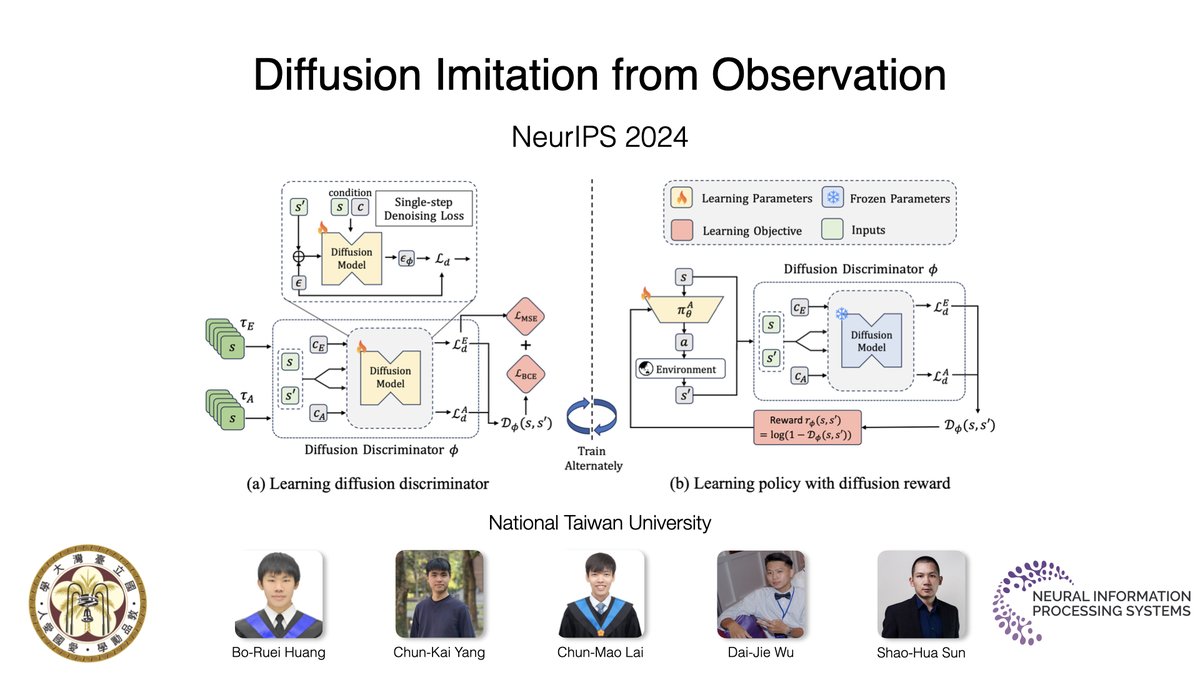
I'll present my work "Diffusion Imitation from Observation" with @shaohua0116 tomorrow at #NeurIPS2024. Please come to have a chat!
Thu 12/11 11am-2pm West Ballroom A-D #6307
[Project Page] https://t.co/AvsNNwCPRn
#NeurIPS2024@xinyun_chen_ (Google DeepMind), @levilelis (U of Alberta), and I will be giving a tutorial on programmatic reinforcement learning and code generation on Dec 10 (Tue) 1:30-4 PM @ East Exhibition Hall A. Come say hi!
A good hand can push intelligence development. Introducing Eyesight Hand, equipped with full-hand high-res tactile sensors and proprioceptive actuators. It is compliant, agile, and powerful. Good tactile sensing makes learning more efficient and robust. Shout out to Branden!