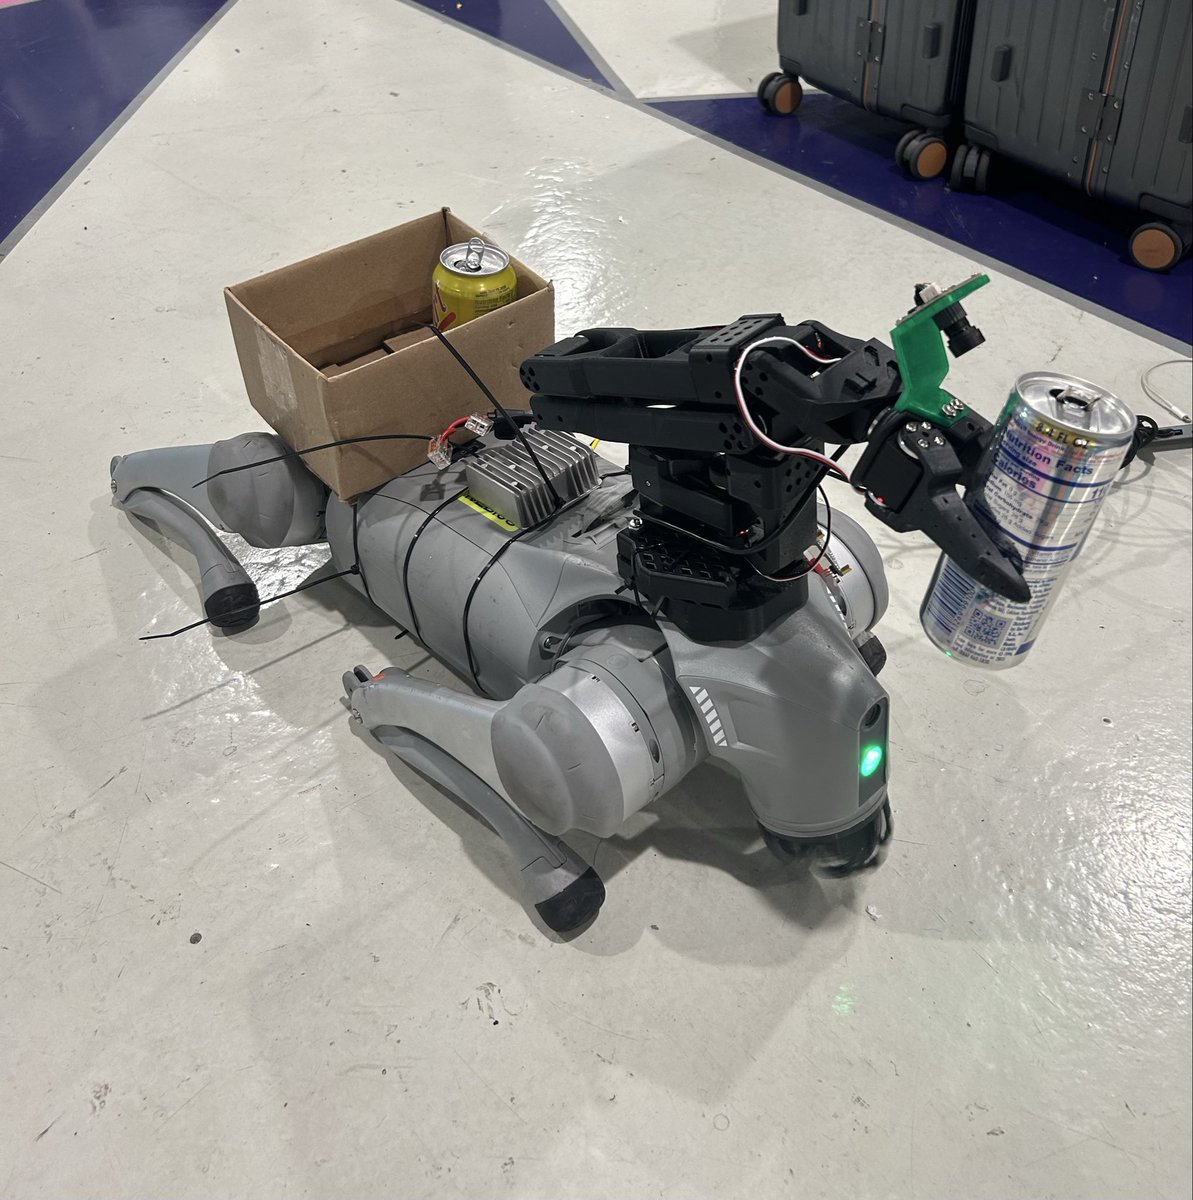
First look at the autonomous trash picking solution in action.
About its reachability, or "when you have to deal with the hardware at hand" :
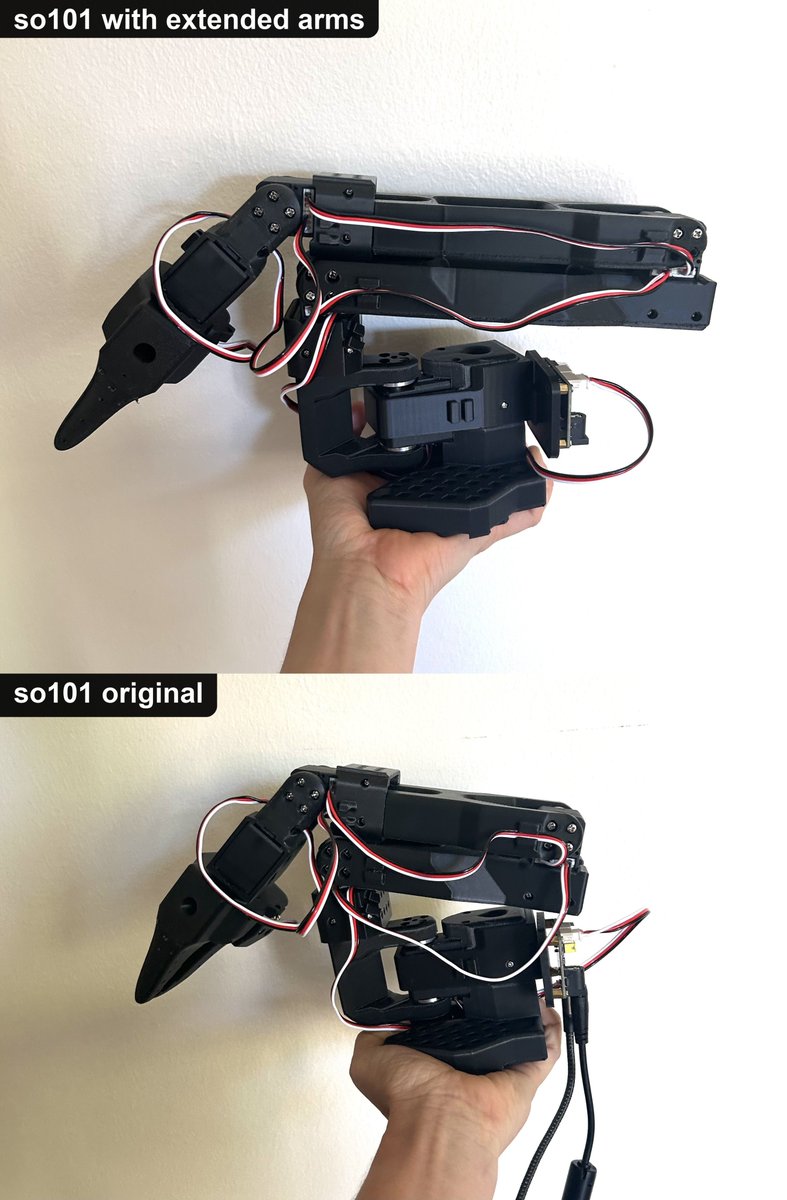
- Added extended links to the arm for a longer reach while keeping a reasonable payload capacity
- Defined a reachability region for the arm around the quadruped
- Made the quadruped crouch when the target object is detected inside that region
PS: The camera cable stresses me out too - Moving to an onboard Raspberry Pi 5 setup.
With a quadruped Go2 @UnitreeRobotics from @nebiusai@DhruvDiddi and arm SO101 @LeRobotHF :)
This is an episode for an ACT and VLA training. I’ve had better results from ACT in the past so focusing on that but will benchmark both. And yes, looking into a more « traditional » pipeline too (hence the seg model that is not just for classification but also potential grasp planning) - what will work best on the field :)
Bonjour 👋
First assembly of the quadruped + robotic arm, powered by the quadruped’s battery, for autonomous trash picking in various environments.
@nebiusai@DhruvDiddi
Just built the "beefed-up" version of the SO-101 for a special project.
An extra 55 mm per arm, for more reach. Found at : https://t.co/fbsWPVjQpX
Same motors as the original SO-101 follower were used since I didn't have higher-ratio 1:315 motors on hand - The payload will need to be lighter than the original SO-101 capacity, but should be fine for the use case.