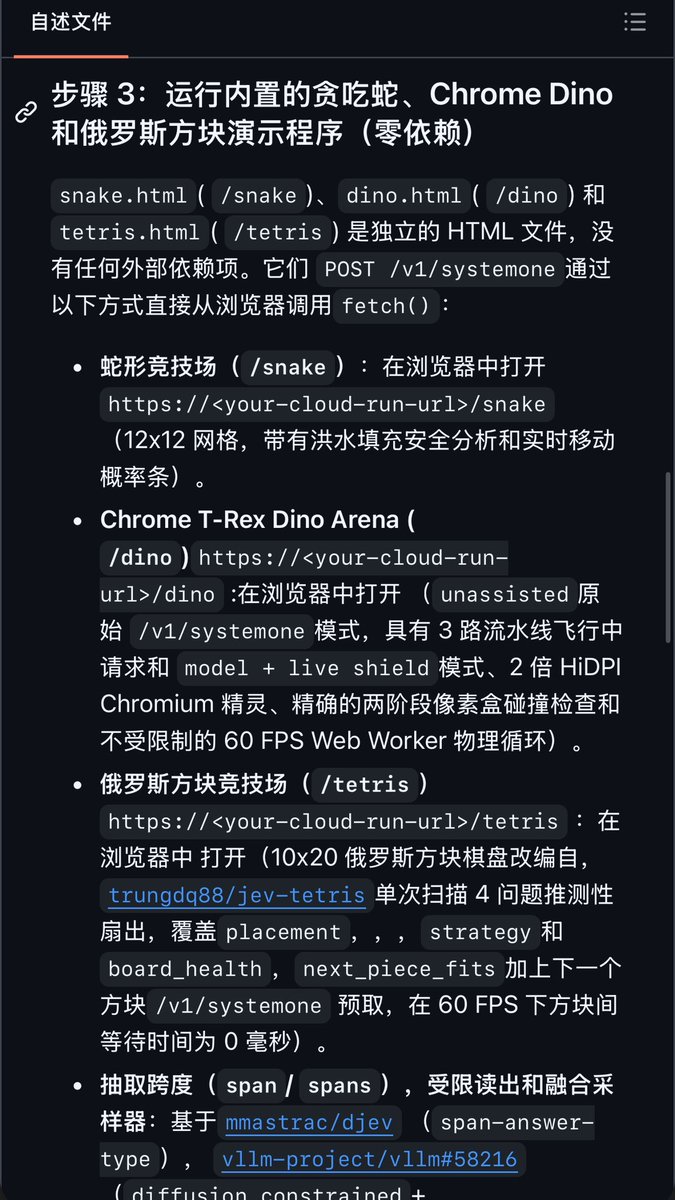
Deploy DiffusionGemma-Jev on Cloud Run with just a single command.
or just send this github repo to your agent: https://t.co/3K1wRJuJSt
Snake demo is super fun to watch.
A request as simple as “get me some water” can require a robot to reason through several decisions: where to go, which object to use, and what to do when the request is ambiguous.
In the @MLStreetTalk podcast, Ming-Yu Liu explains why physical AI needs a system-2 layer to turn an open-ended task into steps a robot can execute.
Watch 📺 https://t.co/Yq8dMR4VPB
Introducing Joga, a full-stack humanoid soccer system with active vision.
Agile dribbling. Tight direction changes. Receive → dribble → shoot/pass.
An actuated neck enables ball tracking with onboard vision.
Residual models for perception + actuation close the sim-to-real gap.
Paper coming soon!
Work done in collaboration with @Avi_Narula14@khai_ngx@venki1899@JohnMarangola@martinpeticco@pulkitology
🚨 BREAKING:
@Cognex_Corp is acquiring @RealSenseai for $500 million! 💰
439 days ago, RealSense spun out of Intel as an independent company.
Their CEO Nadav Orbach signed a lease, moved into offices in Cupertino, Beijing and Haifa, and put the team to work.
The results in under 15 months:
→ 3x quarterly revenue
→ 2 quarters of profitability
→ 6x return on capital to investors
→ $500M value created
→ 50%+ revenue growth in 2026 alone, expected to hit $ 80-90M this year
From Intel spinout to $500M acquisition in 439 days.
That is an EPIC execution story!
Cognex, the 40-year global leader in industrial machine vision, is paying that price because it sees what RealSense has built: the visual cortex of Physical AI. Depth cameras and 3D perception systems deployed across humanoids, AMRs, quadrupeds, industrial arms and autonomous systems worldwide.
The robotic perception market sits at $600M today. It's projected to grow 25%+ annually to $1.6 billion by 2030. Cognex just bought its way into the fastest-growing segment of that market.
Combined, the two companies offer a full-stack visual intelligence platform, from industrial ID and 2D machine vision all the way through to 3D depth perception and robotic navigation.
If robots need eyes to act intelligently in the physical world, Cognex and RealSense just became the company that provides them.
Congrats team! ❤️
~~
♻️ Join the weekly robotics newsletter, and never miss any news → https://t.co/GoA3ZuwoPB
Humanoid robots can now learn skills like climbing, balancing, and handling objects.
MotionDisco lets them learn without human demonstrations or remote control.
AI and motion planning help robots discover new ways to complete tasks.
Introducing Midcentury.
We’re building the data and simulation infra for physical AI.
Today, we’re coming out of stealth with a $15M Series Seed to scale robotics beyond polished demos.
We’re already supporting frontier labs with:
→ The world’s largest egocentric dataset: 2M+ hours, 50+ environments, 20,000+ tasks
→ Matrix: a frontier simulation platform scaled with our real-world data to evaluate and post-train policies at scale
Cactus Needle x MicroDuck: watch our 29MB action model drive @pollenrobotics' MicroDuck.
Needle acts as the intent brain, turning user input into action.
Excited to deploy on-device once the robot ships. We estimate a ≈150ms time-to-action on the Rockchip.
with jev, everyone is understanding the importance of calibrated confidence scores for discrete decision making
we've taken that approach one-step further and created grounded confidence scores for general schema-guided document extraction:
✅ this includes primitive types like bool, int, and float. the numbers don't have to be bounded
✅ this also includes free-form text extraction
✅ each extracted value also carries a bounding box directly back into the source document
calibrated confidence scores are extremely important for human review. By setting a threshold, you can let a human reviewer audit the lower confidence values while automating the extraction of higher confidence values.
If you have needs for large scale doc extraction, come check it out: https://t.co/i7kqplhxTm
Sign up to LlamaParse here: https://t.co/XYZmx5TFz8
Get better Jev probabilities with a one-line import change.
One problem with @typesafeai 's Jev as a decision model: reordering the same choices can change their probabilities.
pijev improves probability estimates by batching permutations into one API call and averaging the predictions—with negligible additional cost.
https://t.co/8lqxlGIIn9
Introducing Jev-Omni, the first multimodal system one model. (Other OSS versions miss atleast a modality)
Supports all modalities: text, images, audio and video !
On Par with Jev on Typed-benchmarks.
Scaled -> 30k examples on 8xH200 (data mix matters a lot)
< 100ms on 1 H100
https://t.co/ACieaM4hTi
More work is coming, so follow along !
At most physical AI companies, more than a third of engineering time is spent building & maintaining infrastructure systems.
Logging, ingest, transformation, indexing, search, training, eval metrics, internal tools... this work is critical to the pace of the company, but never shows up in the demo videos or customer stories.
Shout out to all the physical AI data & infrastructure engineers out there. Our mission is to accelerate your work and build the platform we wish we had.
Ok so...
JEV just accidentally helped me find backdoors on a family member's wifi network. 🤯
- Brought my laptop to code while visiting.
- Decided to experiment with a JEV-powered classifier for network packets fetched via Wireshark.
While building the tool for fun, JEV's classification caught some serious threats. At first I thought JEV was wrong, but then I got a frontier AI model to validate the findings
...and here we are factory resetting some of their devices and securing their network. 🛠️
@typesafeai's JEV powered cybersecurity is real! Crazy!!
And as always, I'm gonna be open sourcing the network packet analyzer soon.
지구상 모든 쾌락과 부귀영화를 끝까지 맛본 최고의 왕이 진짜 밝혀낸 인생 최고의 비밀을 아십니까?
솔로몬 왕 아시죠. 역사상 제일 돈 많고, 권력 다 가졌고, 지혜까지 신한테 인정받아서 1등 먹었던 그분. 성경 전도서 보면 이 형님이 자기 인생 끝판왕 경험담을 솔직하게 털어놓거든. 궁전 짓고, 금은보화 싹 끌어모으고, 몸에 좋다는 건 다 해보고, 부귀영화 레이스를 완전히 끊어봤음. 요즘 말로 하면 초고급 리치 앤 페이머스 라이프의 끝을 본 거지.
근데 그 끝에서 이 형이 던진 한마디가 진짜 소름임. “다 해봤는데 결국 헛되고 헛되더라.”
그러고 나서 솔로몬이 내린 진짜 결론이 전도서 3장 22절에 딱 나옴.
“그러므로 나는 사람이 자기 일에 즐거워하는 것보다 더 나은 것이 없음을 보았나니 이는 그것이 그의 몫이기 때문이라”
인간이 누릴 수 있는 진짜 최상의 행복은 남한테 보여주는 부와 명예가 아니었음. 그냥 자기 손으로 땀 흘려서 자기에게 주어진 일을 즐기고, 그 과정 자체를 기쁘게 누리는 거. 그거 이상으로 인간한테 좋은 게 없다고 아예 도장을 찍어버린 거임.
이거 보면서 소름 돋았던 게, 우리가 요즘 왜 이렇게 조급하고 피곤한지 이유가 딱 나오지 않음?
우리 보통 남들 인스타그램 보고, 옆 동네 아파트 값 보고, 남의 주식 계좌 보면서 ‘아 나는 왜 이거밖에 안 되나’ 비교하느라 정신없잖아. 유한한 게임판 안에서 남의 떡만 보면서 내 인생을 자꾸 남한테 맞추니까 아무리 벌어도 허기지고 불안한 거임.
결국 제일 무서운 건 누구도 뺏을 수 없는 내면의 부를 쌓는 거고, 남과 비교하는 게 아니라 어제의 나와 비교하면서 내가 좋아하는 일에 미쳐보는 거더라. 외부의 평가나 타이틀은 시장 상황 따라 언제든 날아갈 수 있지만, 내가 내 일을 집요하게 파고들면서 얻은 성장과 몰입의 쾌감은 아무도 못 뺏어가니까.
테슬라나 스페이스X 만드는 머스크 보셈. 수틀리면 욕먹고 폭망할 리스크 안고서도 지구상에서 제일 미친 짓을 매일 새로 벌이잖아. 그게 남들한테 잘 보이려고 하는 짓이겠음? 자기 일 자체에 미쳐서 어제의 한계를 깨부수는 그 미친 몰입감이 좋으니까 저러는 거지.
솔로몬 형님 썰대로면 인생 진짜 간단함. 세상이 말하는 정답 찾느라 남 눈치 보지 말고, 진짜 내 가슴 뛰게 만드는 일을 찾아서 어제의 나보다 딱 한 걸음만 더 나아가는 것. 그게 결국 인생 승리하는 치트키가 아닐까 싶은데.
오늘 퇴근길에는 남들 잘나가는 거 보면서 배아파하지 말고, 내가 오늘 내 일에 얼마나 몰입했는지, 어제의 나보다 한 단계 성장했는지만 딱 돌아보는 건 어떨까?
Introducing the Decision Index 0.1 ⚖️
a rigorous leaderboard comparing jev with 30+ open weights decision models
35+ benchmarks. asking 130K questions to each model
testing knowledge 🧠, automation ⚙️, understanding 🤔and even creativity 🎨
https://t.co/Su4OXqJwz0
JevBench v1.3.0 is live.
Original Jev remains 👑 at 74.4.
But it's challenged by 47 competitors now, and some get very close. 👀
Check it out here:
https://t.co/hFQ5fX4JEb
지금 전 세계 개발자 커뮤니티가 발칵 뒤집힌 이유.
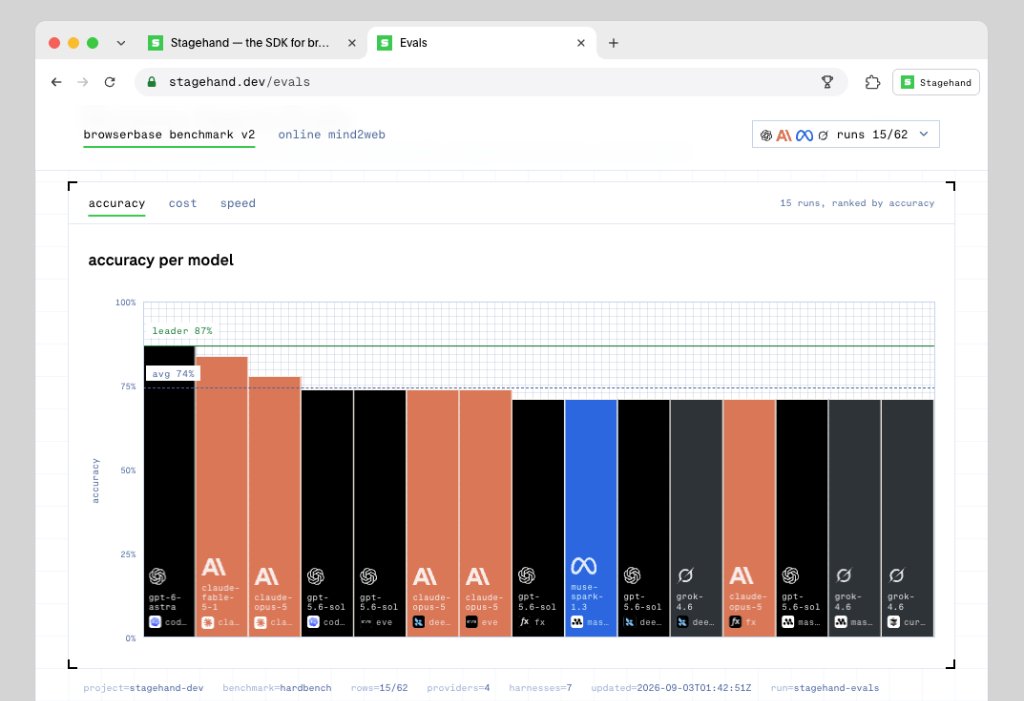
Playwright 쓰던 사람들이 단체로 갈아탈 수밖에 없게 만든 오픈소스 'Stagehand v4'가 나옴.
최근 화제인 Jev까지 붙으면서 LLM 호출 97% 삭감, 속도 11배 폭증.
반복 실행 비용이 '0원'으로 수렴해버리는 미친 자동화의 비밀 👇 (타래)