Thrilled to be awarded the Royal Academy of Engineering UKIC Fellowship to develop AI Based Security Solutions for Air Traffic Infrastructure working at @cranfielddartec@cranfieldaero@CranfieldUni
We are thrilled to reveal the seven new appointments made to the UK Intelligence Community Postdoctoral Research Fellowships. Projects include insect-inspired drones and systems that prevent cyberattacks. Get to know them: https://t.co/gv6VcttRaz #RAEngResearch
EasyNav now supports hot reconfiguration during navigation 🚀
For example, a robot can use GPS-based localization and, if GNSS is lost, switch online to a laser-based approach such as AMCL.
https://t.co/0zZRNtdeEE
#Navigation#MobileRobotics#Adaptation#Reconfiguration
Dyna just announced two things at once: a new brain and a new body.
The brain: Dyna-2.1, which they call the world's first "physical agent" that runs an entire workflow on its own, not just a task. Customers don't buy tasks, they buy a whole AI-employee. A robot that folds for hours but needs a human to refill and reset it is just a "robot babysitter."
The body: Taku, a semi-humanoid with a wheeled base, human-shaped upper body, and folding torso, so it can grab a dropped towel off the floor, reach into a washer, and stack high and low shelves in one flow.
Under the hood: RL whole-body control (100Hz), the DYNA-2 policy learned from human video, and a VLM orchestrator that reasons, remembers, and picks the next step.
The new bar isn't what a robot does in a clip. It's how long it does the job without intervention.
The demo: an uncut 1-hour hotel laundry shift, fully autonomous:
We are excited to share our paper "Temporal Cascading of Planning and Control for Quadrotor MPC," published in the IEEE Transactions on Robotics, where, instead of separating planning and control, we unify them in a single #ModelPredictiveController: a high-fidelity model controls the near future, while a low-fidelity model plans the long horizon!
PDF: https://t.co/eqJ7ld79zd
Narrated video: https://t.co/Yip58934GH
Traditionally, planning and control are treated separately: a simplified model plans a trajectory over a long horizon, and a high-fidelity controller then tries to track it. This is computationally convenient, but suboptimal: the controller is constrained by a plan that does not fully capture the drone dynamics.
We introduce a different way of looking at this problem. Instead of separating planning and control, we put them into one MPC optimization, but use different models at different points in time: a high-fidelity quadrotor model over the near future for accurate control, followed by a computationally cheap point-mass model over the longer horizon for planning. In other words: control precisely nearby, plan efficiently far ahead.
The key contribution is that the two horizons are not simply stacked: they are coupled through transition and feasibility constraints, so that what the simplified model plans remains compatible with what the real quadrotor can execute. We also use parallel low-fidelity planners and progressive obstacle smoothing to escape local minima in cluttered environments without slowing down the real-time control loop.
The result is long-horizon planning with iteration times below 5 ms, and in simulation and real-world flights, up to 75% lower closed-loop cost than standard MPC and conventional hierarchical planner-controller approaches under comparable computational budgets.
To recap: rather than choosing between an accurate short-horizon model and an efficient long-horizon model, use both at the time scales where each matters most!
Kudos to Rudolf Reiter, Chao Qin, Leonard Bauersfeld!
@uzh_ifi@UZH_Science@UZH_en@UZHspacehub@ERC_Research@UZH_ai@AUTOASSESS_EU
What If a Drone Could Navigate Without GPS?
This open-source project builds a PX4 and ROS 2 navigation stack for drones flying indoors or underground without GNSS or a prebuilt map.
It combines stereo visual-inertial odometry, 3D mapping, D* Lite path planning and GPU-accelerated MPPI obstacle avoidance.
The whole system can be tested in Gazebo with PX4 SITL, including challenging 3D environments.
I like projects like this because you can study the complete autonomy stack instead of looking at localization, planning or control in isolation.
Would you try building a GPS-denied drone with this stack?
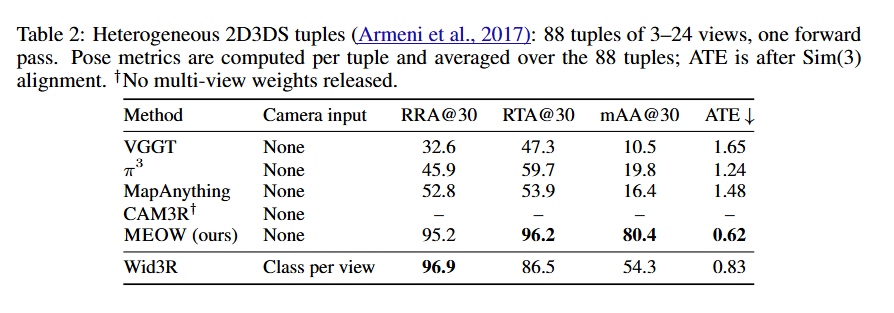
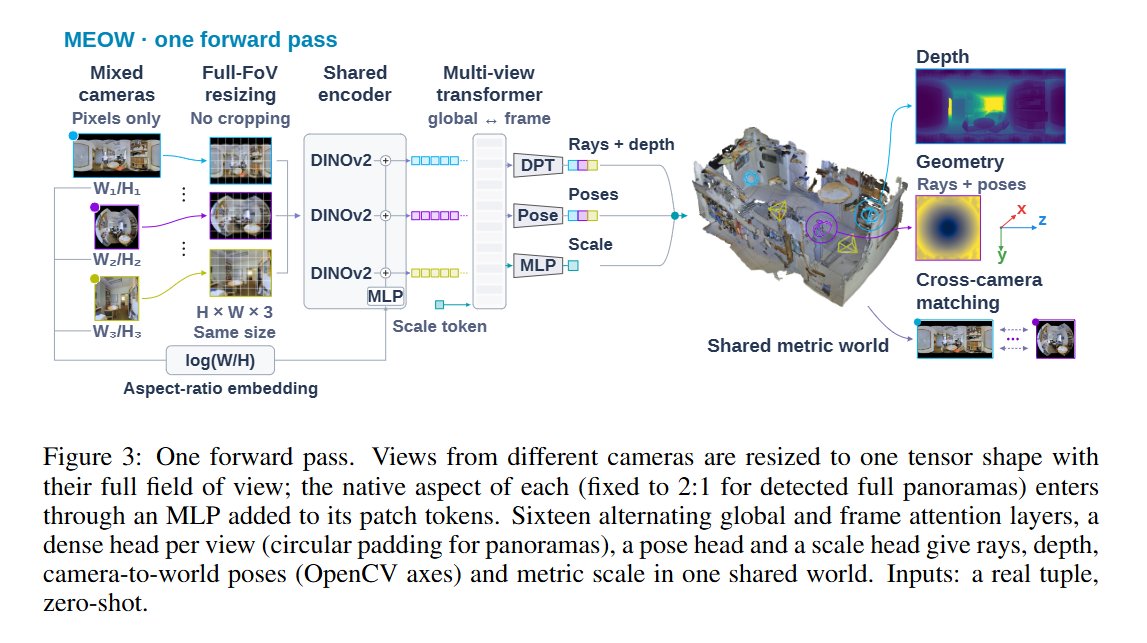
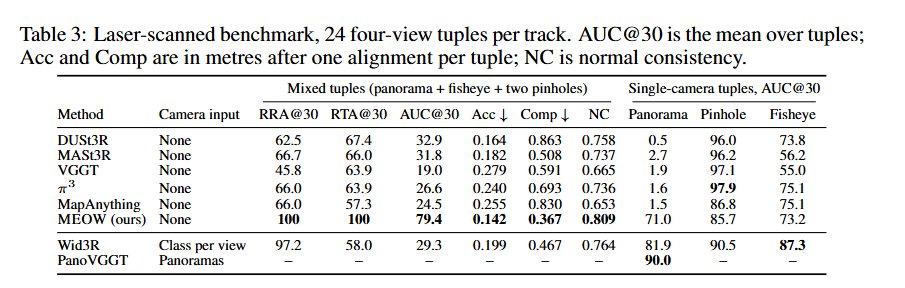
Many Eyes, One World: Feed-Forward 3D Reconstruction from Mixed Cameras
Qiaoge Li, Yifan Zhan, Haijun Yang, Haiyang Liu, Yiyi Cai, Chenchi Luo
tl;dr: perspective, fisheye and full-panorama images in a single forward pass
https://t.co/iGYBUbyY3E
Mighty can now output pose at 60 Hz even when the camera runs at 15 Hz!
It integrates IMU measurements between camera frames to deliver smooth position and orientation updates at 60 Hz. This gives robots and drones a more continuous estimate of how they’re moving.
INSTEAD OF WATCHING NETFLIX TONIGHT. Spend 2 hour with this. Claude AI FULL COURSE that teaches you how to BUILD and AUTOMATE anything. The people who watch this tonight will wake up tomorrow with a new skill. Watch it and bookmark it now.
AMB3R-SLAM: Kilometer-scale SLAM
with Hierarchical Backend
https://t.co/9iCtzB9ijY
TL;DR: 1) A training-free, model-agnostic SLAM system that scales to kilometer-scale trajectories in real time on one consumer GPU; 2) A hierarchical backend that enforces local, mid-level, and global consistency without bundle adjustment, so dynamic scenes work out of the box; 3) One framework that extends to stereo, RGB-D, and LiDAR.
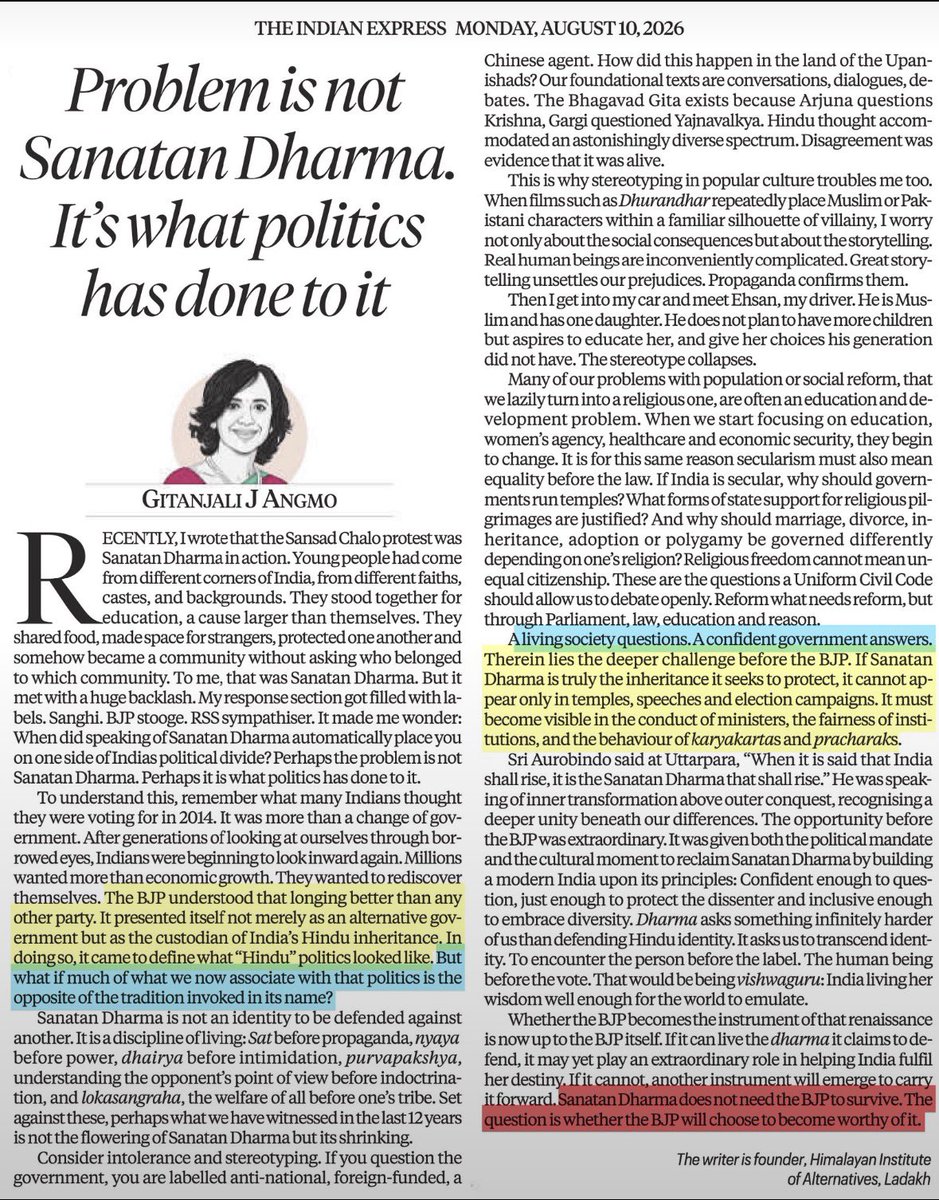
My op-ed in #IndianExpress today makes a simple argument:
How the BJP has reduced a spiritual civilisation to a political identity.
Sanatana Dharma does not depend on the BJP. The BJP must rise to Sanatana Dharma.
We should not support a party simply because it claims our civilisational inheritance. We should ask whether its politics reflects its values: Satya, Nyaya, fearlessness, pluralism and human unity.
Sanatana Dharma is far greater than any party. Perhaps the task is not to politicise Dharma, but to dharmicise politics.
@kushal_mehra Actually there is nothing to be proud of high birth rates earlier, it's the boomer women who were married off in their teens, earlier which accounts for the number. Currently that has reduced a lot.
Foundations of LLMs
This amazing new LLM book just dropped on arXiv.
200+ pages!
It covers areas such as pre-training, prompting, and alignment methods.
It looks like a great intro to LLMs for devs and researchers.
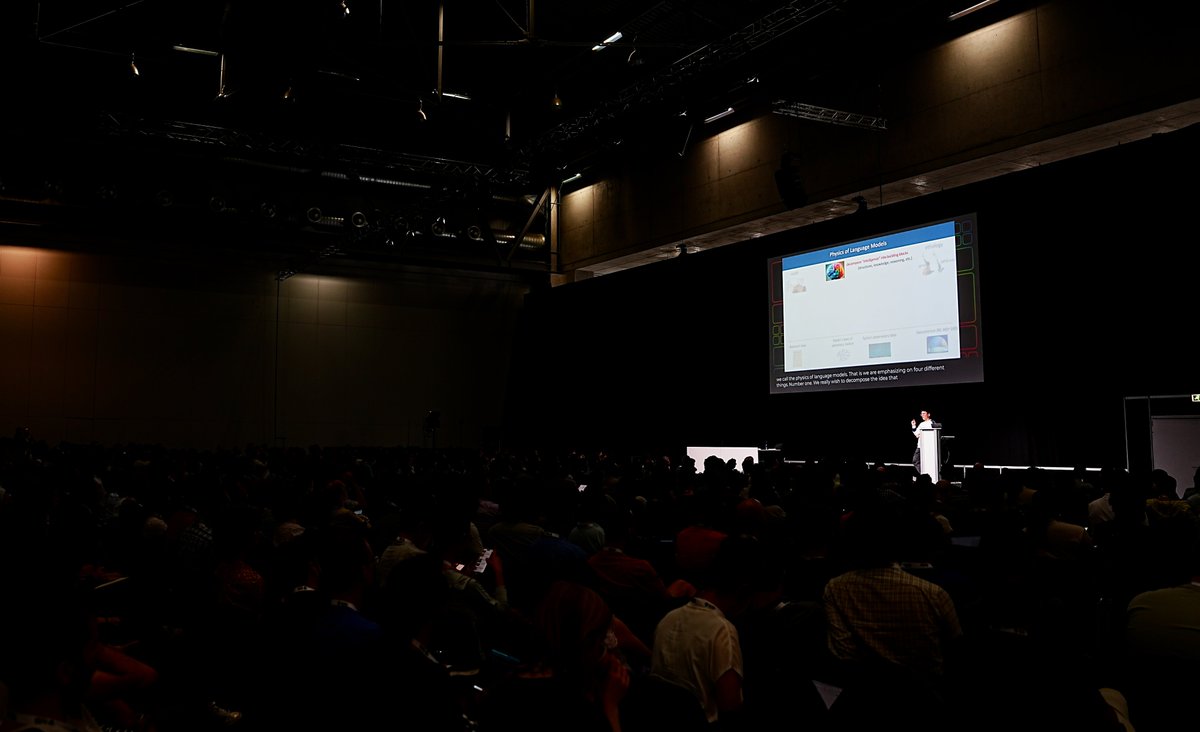
Incredibly honored and humbled by the overwhelming response to my tutorial, and thank you everyone who attended in person. Truly heartwarming to hear how much you enjoyed it. Many have been asking for a recording, and I prepared one with my own subtitles https://t.co/RjTm9ZHpId
If you are a student or academic researcher and want to make progress towards human-level AI:
>>>DO NOT WORK ON LLMs<<<
LLMs are an off ramp.
Thousands of engineers are working on LLMs with enormous computing resources.
The only way you could possibly contribute is by analyzing existing LLMs and showing their power and limitations.
But it's more fun and impactful to come up with new ideas and new architectures and show that they might work, even on small problems.
Scientific publishing etiquette:
1. Scientists should be allowed to publish their research.
2. Publications should include the names of all contributors in the author list.
3. Junior contributors who actually did the work should be placed at the beginning of the author list.
4. Managers and senior contributors should almost always be listed at themtail end of the author list.
5. Managers should never be listed just because they are managers. To be a coauthor, they must have made non-negligible technical contributions.
6. Managers should never, ever put themselves in competition with researchers in their organization.
If you stop researchers from publishing, you kill their career.
That means you have to buy their life, and you'll only get people whose scientific aspirations are sufficiently low to be for sale.
"I can grow while also contributing something to the whole community" - @deepakdep spoke to @GREATBritain about his experience of advancing his R&D career as an @RAEngNews Research Fellow: https://t.co/8fH7HIODHY #RAEngResearch