⚡ One policy, millions of embodiments, over 200 robot models. Can we add yours?
We're building γ₀, a generalist RL policy for motion control trained across millions of randomized embodiments derived from a growing collection of more than 200 robot models.
Instead of asking what tactile sensor to use — we combined them!
MiTaS fuses slow + fast tactile sensing for contact-rich robot manipulation → 80% success vs 31% vision-only 📈
Now accepted at #CoRL2026!
Website: 🌐 https://t.co/bRUOAoLLKg
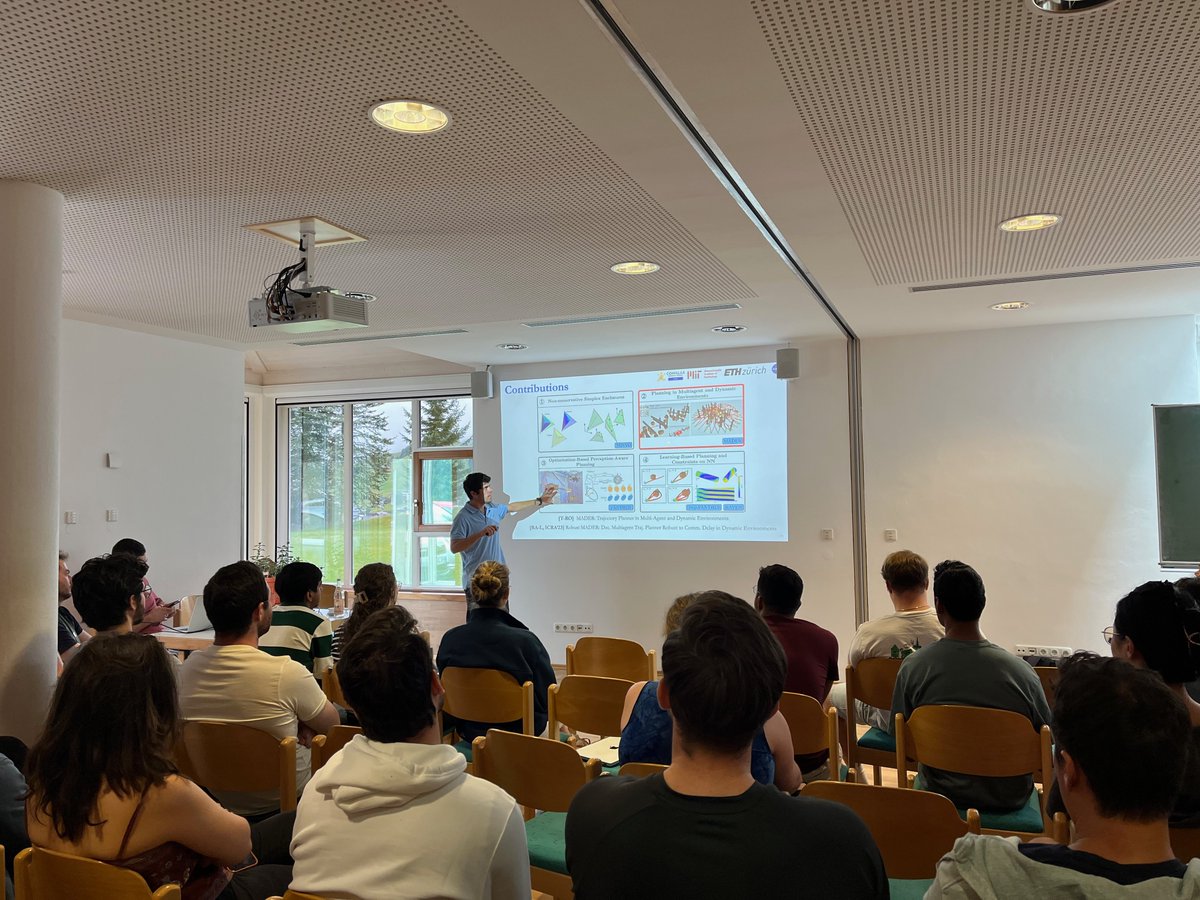
A few moments from IWIALS 2026 in Kleinwalsertal!
Thanks to @m_wulfmeier, Jesús Tordesillas, and @breadli428 for their talks; to everyone who joined us for a week of research fun; and to @Jan_R_Peters, @mdrolet01, and @erikhelmut for organizing!
Great honor and fun to talk about robotic world models at International Workshop of Intelligent Autonomous Learning Systems @ias_tudarmstadt.
First time as a speaker invited by @Jan_R_Peters with Jesus and @m_wulfmeier.
Excited to learn talented people around in robot learning!
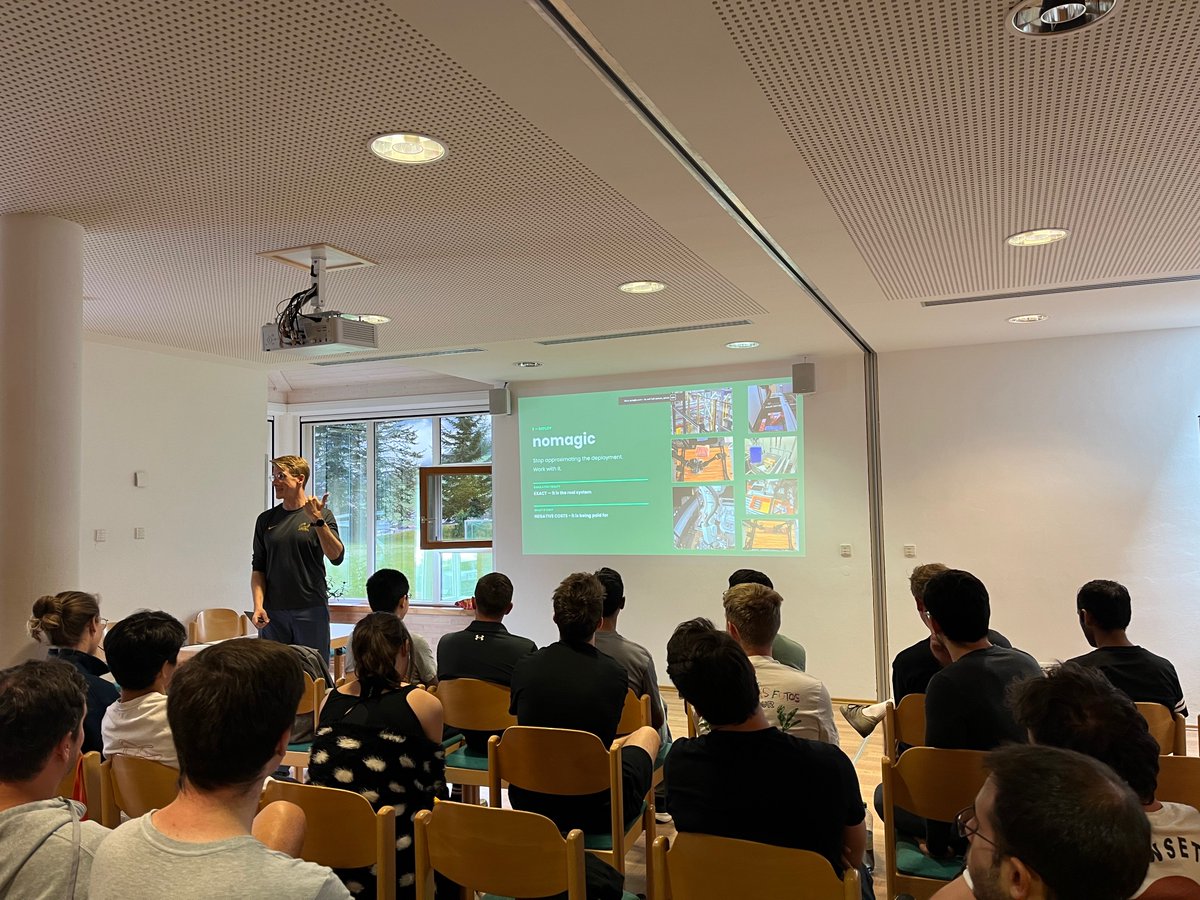
Deeply enjoyed talking about mastery-first physical AI at the IWIALS workshop! Old friends and many new ones - looking forward to how this group will continue to shape European AI.
On mastery: we've made strides on generality and now need to demonstrate real-world more than ever before to justify funding. Even generalisation to 99% is only reducing per-task budget by 50% following Chinchilla scaling (which is a bit pessimistic but even optimistic versions leave 30%). New recipes, data sources, and more is needed!
Thanks to the invitation to @Jan_R_Peters@mdrolet01@erikhelmut! Hope we get to catch up soon @breadli428@RLioutikov! We're continuing to hire masterful RSs and REs @nomagicAI!
A first glimpse of the wildest robotics project of my PhD.
🛹 The Blind Skateboarder 🛹
No vision. No markers.
Paper, code, weights — coming soon. And we have more. 😉
Excited to be at #ICRA2026 in Vienna this week 🇦🇹
Tomorrow I'll be presenting our work on FARM at the Interactive Session — come by if you're around 👋
📅 Tue, June 2
🕘 09:00 – 10:30
📌 VIECON, Hall C (TuI1I.229)
🚀 Thrilled to announce that our paper „Tactile-Conditioned Diffusion Policy for Force-Aware Robotic Manipulation“ (FARM) got accepted at @ieee_ras_icra 2026!
TL;DR: Our tactile-conditioned diffusion policy integrates high-dimensional force profiles from @gelsight Mini via FEATS force estimates into a force-aware action space, enabling seamless transfer from handheld UMI demonstrations to actuated gripper precision with adaptive closed-loop force control. 🤖🔧
The big problem in contact-rich manipulation: Most imitation learning methods treat tactile sensing only as an extra observation. The robot can “see” the contact through high-res tactile sensors like GelSight Mini, but the actual grasp forces remain an uncontrolled side-effect of simple position or gripper commands.
Result? Fragile objects get crushed, deformable ones slip, and dynamic tasks become unreliable. Touch is perceived… but never truly controlled.
FARM solves exactly that. 👇
We turn tactile feedback into a first-class action: our diffusion policy jointly predicts robot pose, grip width, and target grip force, conditioned on rich high-dimensional force distributions (shear + normal) extracted from GelSight Mini images using FEATS.
Paired with our custom Actuated UMI gripper (perfect geometric match to the handheld demo version) and a smart dual-mode controller, FARM enables zero-retargeting transfer + real-time closed-loop force control.
Huge thanks to my amazing co-authors @n_w_funk@timschneider94@cristianaFar and @Jan_R_Peters with support from @ias_tudarmstadt@TUDarmstadt@DFKI@HessianAI@CentreForCogSci and RIG 🙏
→ 🌱 FARM: https://t.co/kCvpdkdNAg
→ FEATS: https://t.co/iN1v9MvaBO
→ 🦾 Actuated UMI: https://t.co/mZq224300J
#ICRA2026 #Robotics #TactileSensing #DiffusionPolicy #RobotLearning
Solving contact-rich manipulation tasks even under disco light🪩?
Incorporate multiple sensors using MSDP and obtain a robust policy in under 55 min!
Excited to share our work accepted at RA-L: Self-Supervised Multisensory Pretraining for Contact-Rich Robot Reinforcement Learning
🚀 Thrilled to announce that our paper „Tactile-Conditioned Diffusion Policy for Force-Aware Robotic Manipulation“ (FARM) got accepted at @ieee_ras_icra 2026!
TL;DR: Our tactile-conditioned diffusion policy integrates high-dimensional force profiles from @gelsight Mini via FEATS force estimates into a force-aware action space, enabling seamless transfer from handheld UMI demonstrations to actuated gripper precision with adaptive closed-loop force control. 🤖🔧
The big problem in contact-rich manipulation: Most imitation learning methods treat tactile sensing only as an extra observation. The robot can “see” the contact through high-res tactile sensors like GelSight Mini, but the actual grasp forces remain an uncontrolled side-effect of simple position or gripper commands.
Result? Fragile objects get crushed, deformable ones slip, and dynamic tasks become unreliable. Touch is perceived… but never truly controlled.
FARM solves exactly that. 👇
We turn tactile feedback into a first-class action: our diffusion policy jointly predicts robot pose, grip width, and target grip force, conditioned on rich high-dimensional force distributions (shear + normal) extracted from GelSight Mini images using FEATS.
Paired with our custom Actuated UMI gripper (perfect geometric match to the handheld demo version) and a smart dual-mode controller, FARM enables zero-retargeting transfer + real-time closed-loop force control.
Huge thanks to my amazing co-authors @n_w_funk@timschneider94@cristianaFar and @Jan_R_Peters with support from @ias_tudarmstadt@TUDarmstadt@DFKI@HessianAI@CentreForCogSci and RIG 🙏
→ 🌱 FARM: https://t.co/kCvpdkdNAg
→ FEATS: https://t.co/iN1v9MvaBO
→ 🦾 Actuated UMI: https://t.co/mZq224300J
#ICRA2026 #Robotics #TactileSensing #DiffusionPolicy #RobotLearning
Pushing for #icra but still missing real robot experiments? 😰
Skip the ROS headaches — get your Franka robot running in minutes with franky! 🦾
Super beginner-friendly, Pythonic, and fast to set up.
🔗 https://t.co/Modc3KX2TY
@ias_tudarmstadt@Jan_R_Peters
🧵👇
Super excited to share our work on force estimation for the @gelsight mini optical tactile sensor! 🚀 We introduce FEATS—Finite Element Analysis (FEA) for Tactile Sensing—a U-net that predicts 3D force distributions from tactile images leveraging FEA. Why does it matter? 👇
Our paper will be presented at the 2nd Workshop on Touch Processing: From Data to Knowledge at #NeurIPS24! https://t.co/NXJ7uAnPI4 💥
Check out our project page for more details: https://t.co/dYuGNW8TSf 🔍
Researchers from @ias_tudarmstadt and @lasr_lab present a novel, open-source event-based optical #tactilesensor called Evetac. By applying this sensor, the researchers are able to create fast and robust closed-loop grasp controllers for manipulation.
https://t.co/R6ejt8mPME
Deep #Generative Models lecture in @CS_TUDarmstadt just ended. I am fascinated by the creativity and enthusiasm of the students on the final presentation. Check out this #tarantino-esque chest x-ray generated with Neural Cellular Automata: https://t.co/hZH2NQTpTK