You don’t have to have a ticket to #DevDay to witness frontier AI.
You can just call a Waymo!
Rey and I got to experience the culmination of over a decade of progress on our ride into work this morning.
Grippers have landed in the office. 🦾
We’re dogfooding our own product to live in the same pain our customers do.
This was our first successful trajectory was captured by yours truly. I’m just glad I didn’t rip my coat
VLAs ground language unevenly, and apparently in a consistent order...
We keep seeing VLMs fumble scene understanding in robotics.
According to the paper the order goes: color first, then object, spatial (left vs right), verb, size
The verbs come last.
https://t.co/FLiZKboHPU
A teleoperated robot episode doesn't start when the recording does - the operator is still setting up while the camera rolls.
The robot's own joint positions tell you which frames matter without decoding a single pixel. With this method, trimming all of DROID - 500 hours of robot data - took 32 seconds on a laptop.
https://t.co/qvQcRoxE9N
The product is physical intelligence.
Systems that move and change things
in the real world.
Web engineering runs on server-grade hardware.
Cloud instances. Comfortable.
Physical AI runs somewhere else.
Hand-pose annotation is the plumbing between raw robot video and a trained model. daft-physical-ai packages it into a single Daft UDF.
This is how it works: track_hands in daft-physical-ai passes a Daft image column and gets a hand-pose column back. MediaPipe (CPU/2D) or WiLoR (GPU/3D MANO), same schema either way. Lazy, batched, distributed — Daft handles execution.
On EgoDex: detect=100%, [email protected]/.2/.3 = 49/84/96.
Try it: pip install daft-physical-ai
Check more use cases here https://t.co/HkEIbQeXBi
@daftengine is a compute engine as much as a dataframe library. You can run models with it, scale heterogenous compute, all with world class IO.
Vectorizing LLM or embedding operations across text and images is effectively trivial once you have the model downloaded.
Here's how that looks with @huggingface Transformers — local inference, no API key with Daft's AI functions: prompt, embed_text, and embed_image.
Excited to announce: daft-physical-ai, a new Python data processing library for physical AI.
We're starting with two use cases: hand tracking and reward scoring - essential steps for making robot data useful for training.
https://t.co/4WiP1oHk5L
Some founders find their calling at 30.
Sammy found his at 12.. and it led to Eventual.
Why is he the one to do this?
Number one: he loves robots.
He's a Transformers guy.
But even before that, at 12 years old,
he was building robotics.
He's much older than 12 now.
After DeepScale, he worked at a number of self-driving companies,
all circling the same question.
How do you sift through all the data
and train the models
so we can make robots real?
Where does he see himself in ten years?
Working on robotics. https://t.co/AITR39Lm1V
Some founders find their calling at 30.
Sammy found his at 12.. and it led to Eventual.
Why is he the one to do this?
Number one: he loves robots.
He's a Transformers guy.
But even before that, at 12 years old,
he was building robotics.
He's much older than 12 now.
Some founders find their calling at 30.
Sammy found his at 12.. and it led to Eventual.
Why is he the one to do this?
Number one: he loves robots.
He's a Transformers guy.
But even before that, at 12 years old,
he was building robotics.
He's much older than 12 now.
He still is that kid.
Then came the decade.
Berkeley, where he was a researcher in computer vision.
Then chief architect at a self-driving startup called DeepScale.
He sold it to Tesla.
Eventual is his second company.
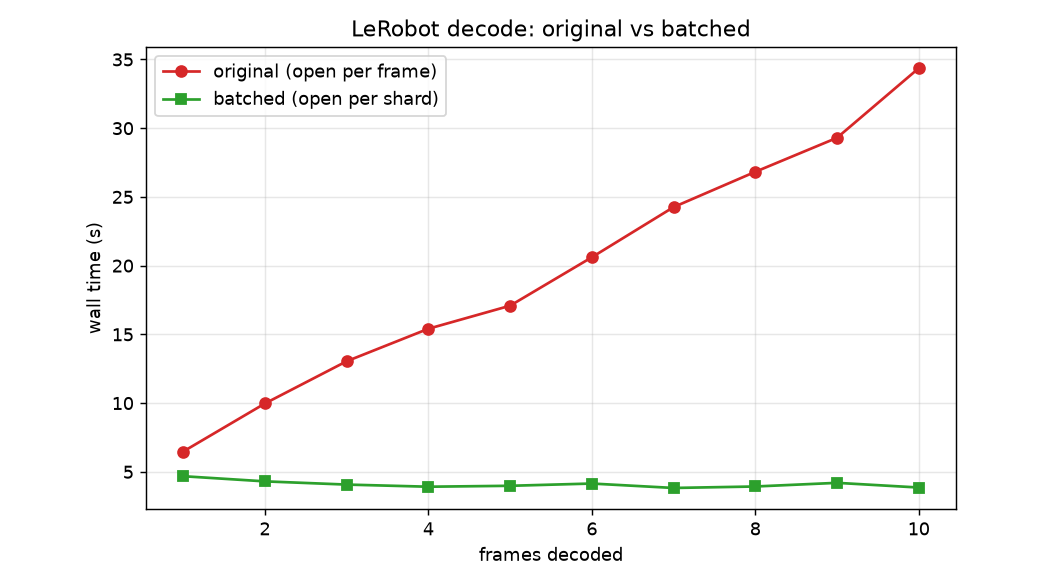
.@LeRobotHF is becoming the dominant open format for robot data.
We recently introduced a native LeRobot reader in Daft, and we've now made it up to 15× faster.
We're excited to share that the Eventual team will be at AUTONOMOUS: The Future of Robotics & Physical AI
We're looking forward to meeting with some of the most talented builders and investors in the industry.
See you on July 16th at The Midway, San Francisco.
#PhysicalAI #Robotics #AUTONOMOUS2026
How well do you know the open source physical ai community?
I asked claude to help me craft an awesome list of 178 repos across 11 categories: VLAs, sim, world models, RL infra, middleware, perception, data, evals, and deployment.
https://t.co/HvQ2LPNiYB
Breaking: @huggingface and @CommonCrawl partnered to democratize access to the largest dataset for AI
You can now load Common Crawl in one LoC from ANYWHERE and for FREE
thx to pre-warmed CDN in multi-region/multi-cloud, no data movement fees, and to @daftengine@everettkleven
So excited to finally announce this collaboration with @huggingface@daftengine + @CommonCrawl is the best way to work with petabytes of internet data.
Stay tuned, we’re just getting started💪🦾
Processing images, audio, and video alongside structured data in one pipeline is painful. Daft (@daftengine) is an open-source data engine built for multimodal AI workloads, with GPU/CPU co-scheduling and 5x lower memory than alternatives. More specs in the next post. #DevTools