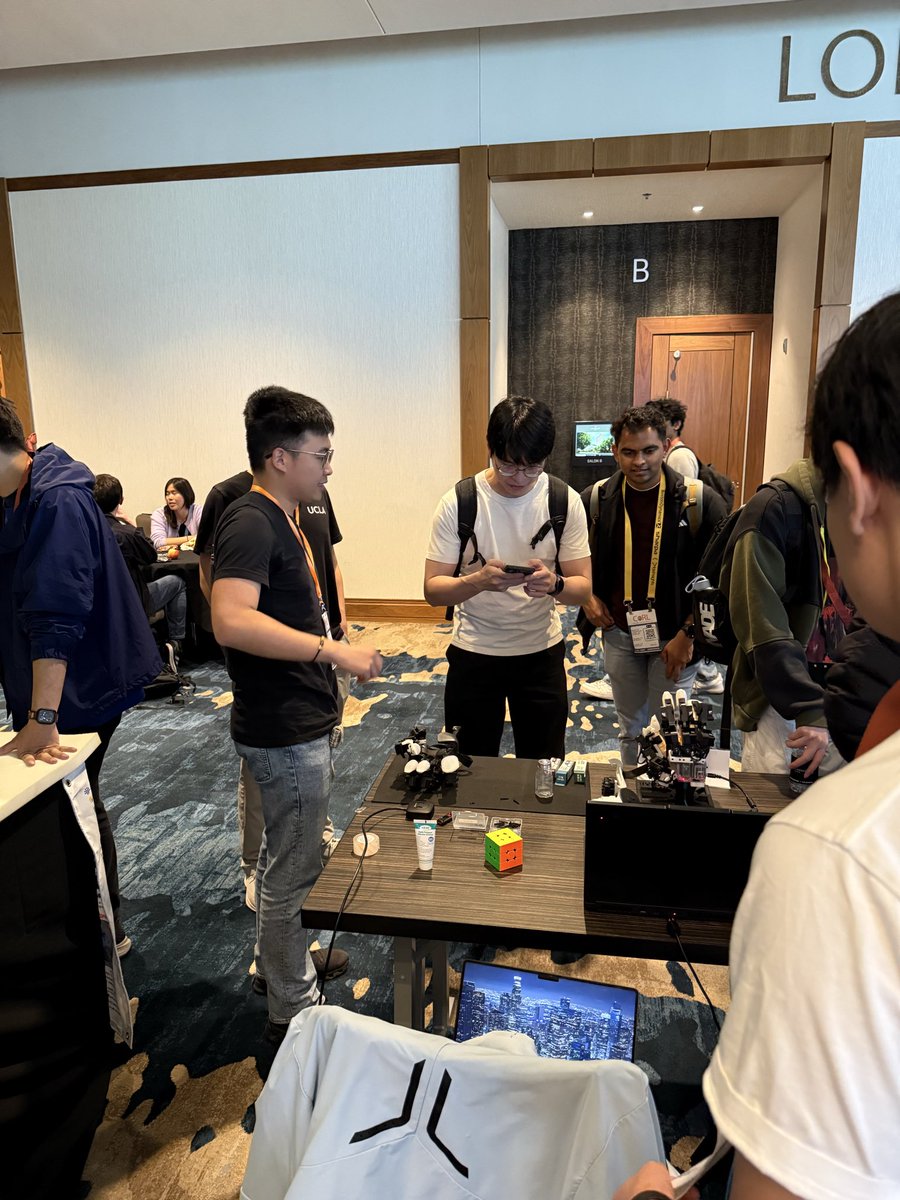
Excited to release TriMI: a tri-modal manipulation interface for direct demonstration, robotic execution, and joint-level haptic teleoperation.
Accepted to the CoRL UMI Arena Workshop — come try it hands-on! #CoRL2026
Webpage: https://t.co/fs2RXiGz3D
🧵(1/8)
You can try it in your browser: drag the arm and drive the hand with your own webcam on the project page.
📄 https://t.co/leJHkvBSQ5
🌐 https://t.co/cZAQFLQ1h5
Thanks to our amazing team: Chris Wang, Jonathan Liu, @alvinyzhu , @FredWang0628, Han Fang, Feng Xu, and @normanzmz_zhu, and to Prof. Yuchen Cui and Prof. @DennisHongRobot for their advising.
Just grab the robot.
DexDirect is accepted to #Humanoids2026 🎉
Drag the arm by its handle, drive the fingers with one webcam.
- 3.2× more successful demos than TeleDex, 17.2× vs AnyTeleop
- A policy trained on DexDirect demos: 90% success
https://t.co/ubYXvTJ5fm
🧵(1/n)
10-person user study, 5 contact-rich tasks: Jenga, USB unplugging, Lazy Susan, whiteboard erasing, keyboard typing.
DexDirect had the highest success rate on every task, finished 1.8–4.8× faster than TeleDex, and scored the lowest NASA-TLX workload.
TriMI made the Top 3 at The UMI Arena, #CoRL2026! 🏆
A glove that doubles as a robot hand: direct demonstration, joint-level haptic teleoperation, and robotic execution in one device.
Thanks to everyone who stopped by to try it, to the UMI Arena organizers, to Prof. @DennisHongRobot and amazing team @normanzmz_zhu, @FredWang0628, Jonathan Liu, @Alden_Copps, Daniel Koh, @alvinyzhu
Saw TRIMI by @DennisHongRobot and team at CoRL and thought it was really fun to use. The idea here is that it's a robot hand that you can also wear -- sort of the logical extension of an UMI system. Impressively dexterous and presumably gives you "perfect" data with no remapping.
Saw TRIMI by @DennisHongRobot and team at CoRL and thought it was really fun to use. The idea here is that it's a robot hand that you can also wear -- sort of the logical extension of an UMI system. Impressively dexterous and presumably gives you "perfect" data with no remapping.
Excited to release TriMI: a tri-modal manipulation interface for direct demonstration, robotic execution, and joint-level haptic teleoperation.
Accepted to the CoRL UMI Arena Workshop — come try it hands-on! #CoRL2026
Webpage: https://t.co/fs2RXiGz3D
🧵(1/8)
Human & robot hands are different, making it hard for robots to learn from human demonstrations.
So I jokingly asked my students:
“What if we cut off our hands & replace them with robot hands?”
That crazy question led to #TRIMI
Guess what it does?
Hint: THREE things!
#CoRL2026
MIDAS is an open-source tactile dexterous hand platform developed by @RoMeLaUCLA for robot learning, teleoperation, manipulation, and sim-to-real research featuring 16 DOF, 13 active actuators, and 283 3-axis taxels.
https://t.co/OcLFusuq8s
🤖 The last day of #ICRA2026 has arrived!
🌟 Over the past few days, we connected with brilliant minds and had inspiring conversations around embodied intelligence and where things are heading. At booth 94, we are showcasing our latest integration with @RoMeLaUCLA 's 𝗠𝗜𝗗𝗔𝗦 𝗛𝗮𝗻𝗱 — a fully open-source dexterous robotic hand embedded with tactile sensors, designed for manipulation, data collection, and robot learning research.
Only one day left for you to visit us! Let’s meet at 𝗛𝗮𝗹𝗹 𝗕, 𝗕𝗼𝗼𝘁𝗵 𝟵𝟰 to explore more!
#Paxini #UCLA #ICRA2026 #MIDASHand #DexterousHand #TactileSensor
UCLA RoMeLa just open-sourced a dexterous hand that hits the rare combo: tactile sensing, humanlike form factor, and a roughly $3K build cost. 🖐️
MIDAS packs 16 DoF, 13 active + 3 passive DoF architecture, 283 3-axis tactile taxels, open-source hardware and software, a MuJoCo contact model, and a vision-based teleoperation pipeline.
The real value is not just price; it is a repairable, tactile-rich hand built for manipulation, teleoperation, and robot learning work that usually costs far more to prototype.
If dexterous manipulation is going to leave locked lab stacks, this is the kind of hardware more researchers need on the bench.
🤖Excited to release MIDAS Hand, and we will be bringing it to #ICRA2026!
MIDAS is a fully open-source, tactile-sensor integrated dexterous robotic hand platform for manipulation, data collection, and robot learning research.
Website: https://t.co/HUHz90TJ5b
🧵👇
Incredibly proud to finally share the MIDAS Hand! 🦾
It’s been an amazing journey pushing the boundaries of dexterous manipulation with this squad. A true team effort.
🤖Excited to release MIDAS Hand, and we will be bringing it to #ICRA2026!
MIDAS is a fully open-source, tactile-sensor integrated dexterous robotic hand platform for manipulation, data collection, and robot learning research.
Website: https://t.co/HUHz90TJ5b
🧵👇