UniSim-SLAM: Feed-Forward SLAM with Unified Sim(3) Optimization(ECCV 2026)
https://t.co/fP92bB4kia
UniSim-SLAM applied to an image sequence captured with a mobile phone.
📝 온라인 교육계의 유튜브인 칸 아카데미의 창립자 살 칸의 기고글.
“Sal Khan, 학교 AI와 Khanmigo(AI를 활용한 교육 실험)의 현실을 되돌아보다”
Sal Khan은 처음에 AI가 교육을 크게 바꿀 것이라고 기대했지만, 실제로는 교육 혁명은 아직 일어나지 않았다고 봄.
많은 학생들이 AI 튜터(Khanmigo)를 적극적으로 사용하지 않았고, 대부분에게 큰 변화를 주지는 못했음.
문제는 학생들이 자발적으로 활용하는 구조가 아니었고, 필요할 때만 사용하는 수동적 형태였기 때문임.
즉, 현재 AI는 학생이 먼저 찾아야 작동하는, 수동적인 형태에 머물러 있음.
AI 튜터가 교육을 바꾸려면 수업 안에 자연스럽게 녹아들고, 교사와 함께 작동하며, 학생을 적극적으로 참여시킬 수 있어야 함.
(아직까지는)AI는 보조 도구일 뿐, 학습 동기, 관계 형성, 사회적 성장 등은 여전히 인간 교사가 담당해야 함.
https://t.co/WVG0NwzxG9
[1/n]
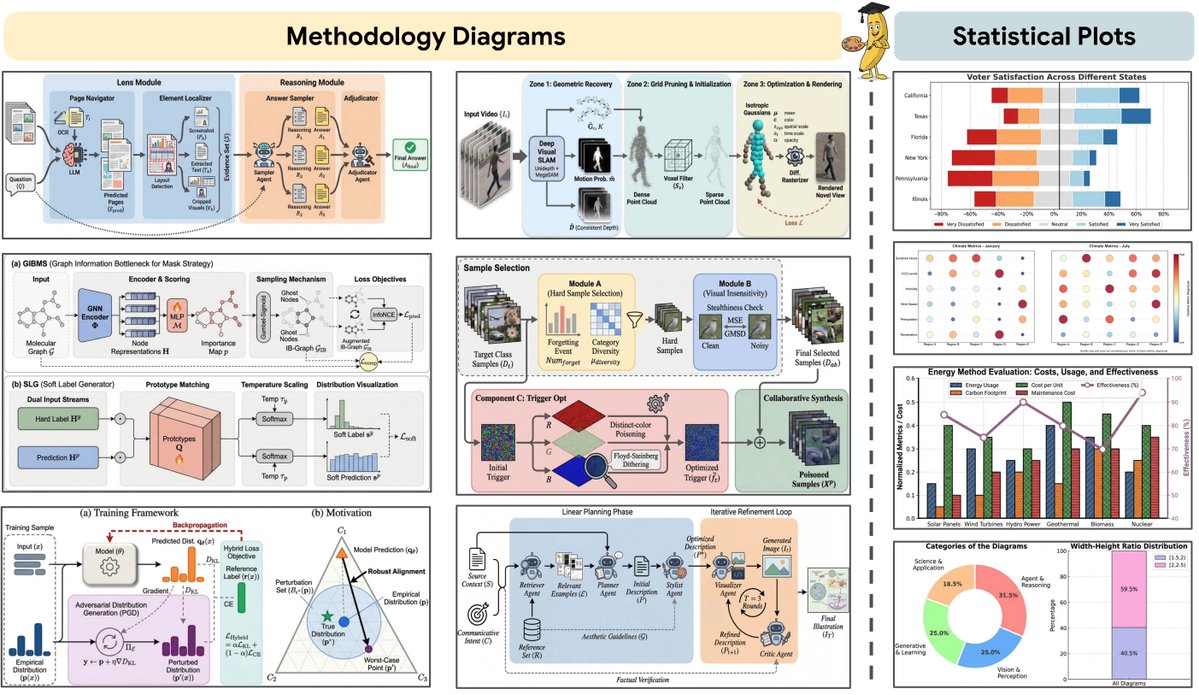
Super excited to introduce PaperBanana 🍌! (PKU x Google Cloud AI)
As AI researchers, we often spend way too much time crafting diagrams and plots instead of focusing on the ideas 🤯. To rescue us from this burden, we built an Agentic Framework to auto-generate NeurIPS-quality paper illustrations!
📄 Paper: https://t.co/2NbQeEhzMv
🌐 Page: https://t.co/05dKkjVs7f
Key Features:
🌟 Human-like Workflow: Retrieve 🔍 -> Plan 📝 -> Style 🎨 -> Render 🖼️ -> Critique 🔄. This ensures both academic fidelity and aesthetics.
🌟 Versatile: Supports both illustrative diagrams and statistical plots.
🌟 Polishing: Also effective for polishing existing human-drawn diagrams.
Here are some example diagrams and plots generated by our PaperBanana:
“KAIST 학생이 직접 쓰려고 만든 AI 강의 필기앱
# 10,000시간을 써도 무료⏤ 서버, API 비용이 안들기 때문에 가능합니다. 결제도 안 붙였어요.
# 로컬 AI⏤ 서버가 없기 때문에 인터넷이 필요없어요.
# 철저한 보안⏤모든 내용은 사용자 PC에만 저장됩니다.
# 실시간 번역“
https://t.co/daGkEgkqVJ
Full draft of the SLAM Handbook now released --- available as a free PDF, with a printed version coming soon. Now including Part 3, "From SLAM to Spatial AI" (I knew it would catch on eventually), with contributions from @HideMatsu82 and me.
#SpatialAI
https://t.co/efM6qCM4vQ
Introducing VGGT (CVPR'25), a feedforward Transformer that directly infers all key 3D attributes from one, a few, or hundreds of images, in seconds! No expensive optimization needed, yet delivers SOTA results for:
✅ Camera Pose Estimation
✅ Multi-view Depth Estimation
✅ Dense Point Cloud Reconstruction
✅ Point Tracking
Project Page: https://t.co/Qoc1ipqozq
Code & Weights: https://t.co/1GkCpRATkE
MASt3R-SLAM code release!
https://t.co/VFc4zyMdA3
Try it out on videos or with a live camera
Work with @eric_dexheimer*, @AjdDavison (*Equal Contribution)
An Invitation to 3D Vision: A Tutorial for Everyone
It aims to make beginners understand basic theories on 3D vision and implement its applications using OpenCV. In addition to tutorial slides, example codes are provided in the purpose of education.
https://t.co/pIjLu60Pj5
This MIT computer science class teaches you all the things that other classes don't teach you, like...
🖥️ Shell tools and scripting
🖥️ Vim
🖥️ Data wrangling
🖥️ Command-line environment
🖥️ Version control
Watch all 11 lectures for free: https://t.co/oc0tr2QAZt
We are proud to announce ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual-Inertial and Multi-Map SLAM.
Paper: https://t.co/y77D4UmzNN
Code: https://t.co/1fwh9MKCM9
Videos: https://t.co/wWO863EqW4
InteriorNet, a new mega-scale, high quality synthetic dataset of indoor scenes from my colleagues at Imperial and collaborators at https://t.co/9AjI8uNKRx and USC. Includes ground truth inc. IMU, semantics, events, and realistic trajectories.
https://t.co/sTk7rJSGqC via @YouTube