@tylerlum23 and I have been busy bringing Play2Perfect to new robots and simulators! Here’s a sneak peek at two robot setups in IsaacLab and MJLab 👇
Come chat with us at our poster today at 5pm at #CoRL2026!
Four posters from our lab at #CoRL2026 Poster Session 1 today, 5–6:30 PM at the JW Marriott 🤖
🟣 #45 MessyMem
🔵 #72 CHORUS
🟢 #120 Mixture of Frames
🟠 #155 MessyNav
Come say hi! Links below 👇
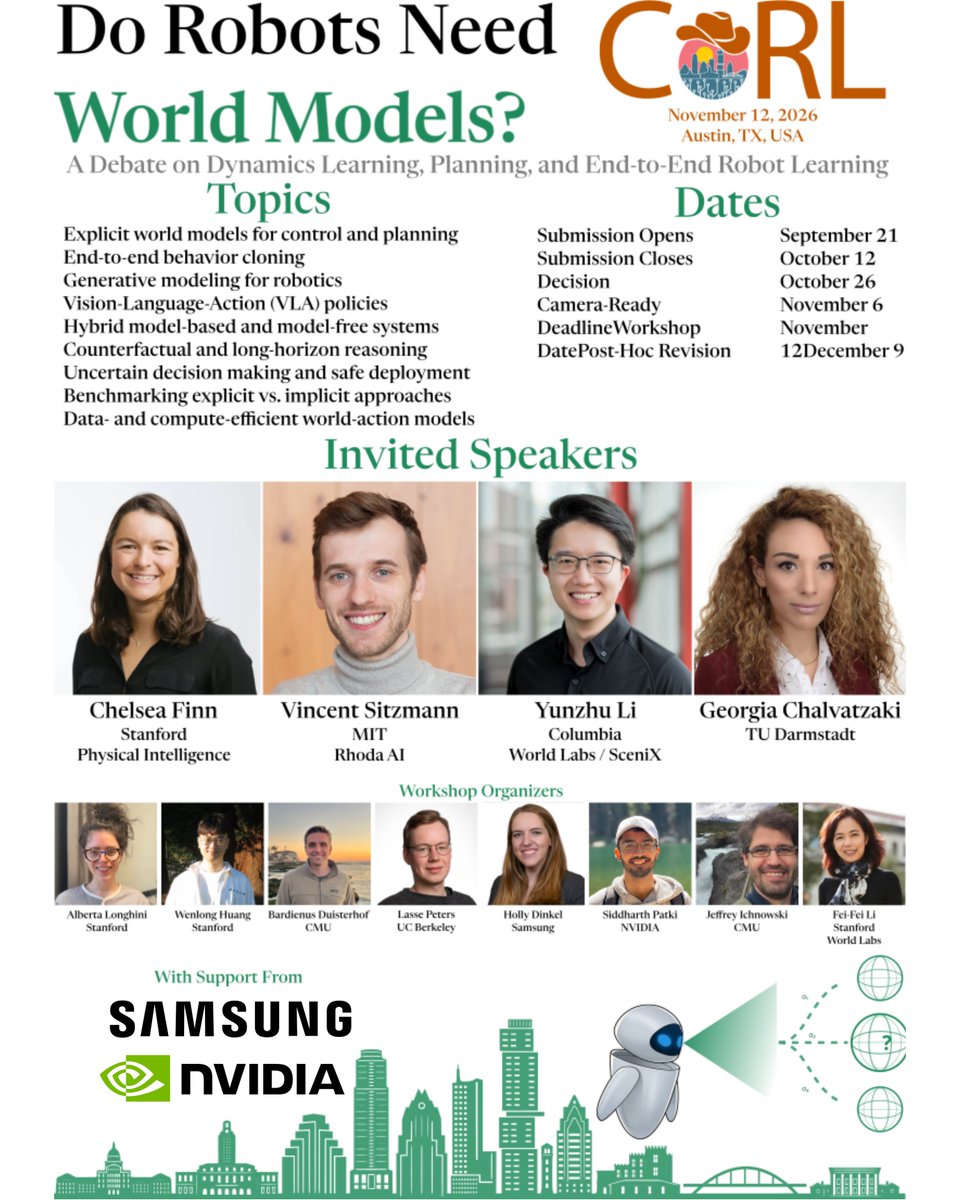
Do robots need world models? Join us at #CoRL2026 for the workshop on Thursday!
🌎 https://t.co/yoYUliYeBp
🕣 November 12 · 8:30 AM–12:30 PM CST
📍 Brazos room, JW Marriott Austin
Heading to #CoRL2026 🤠!
Will be presenting our spotlight paper "Demystifying When and Why VLAs Fail in Contact-Rich Tasks and How to Fix Them" at the following sessions:
🎤 Talk: Tue 11/10, 2 PM
🪧 Poster #166: Tue 5–6:30 PM
Come say hi 👋
Want to know how well agents can really control robots directly?
In RoboARCade, we systematically evaluate and diagnose frontier agents controlling robots directly using tens of thousands of dollars’ worth of agent trajectories. RoboARCade contains diverse, precise, and long-horizon tasks. Paper, code, assets and every trace are out today. https://t.co/WCCWpc4V4C
Robots need memory 🧠: remembering where your favorite cup is or which drawer is locked.
How can a robot remember across large spaces, interactions, & fine-grained detail?
Introducing MessyMem (accepted to #CoRL2026 🚀): Learning-from-Doing Memory for Mobile Manipulation. 🧵
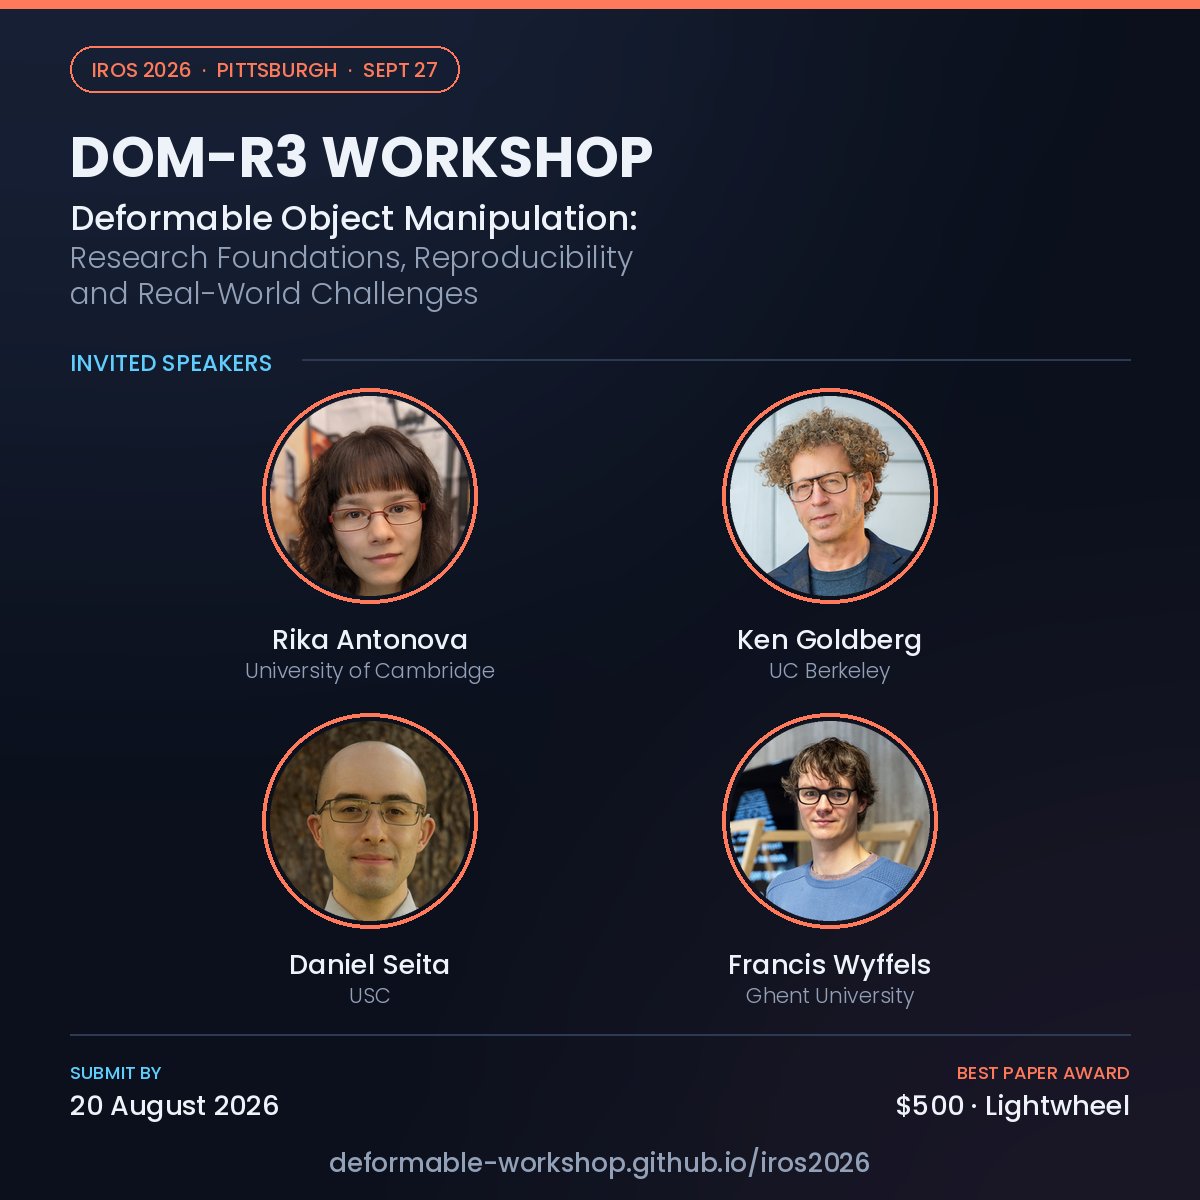
4/ Topics: representation & state estimation, simulation & modeling, sim-to-real, RL & learning from demos, perception, control & planning, foundation models, specialized grippers/sensors.Submit → https://t.co/YijvTYM8Ek
3/ Beyond talks: spotlight presentations, a poster session, top-3 talks from the LeHome Garment Manipulation Challenge, and a panel on reproducibility & benchmarking — evaluation protocols, dataset sharing, comparing results across platforms.📅 Sept 27, Pittsburgh (hybrid)
Curious why your VLA struggles with contact-rich, precision-critical tasks? 🤖
Check out @carlotapares latest work to uncover why these failures happen, from precision to force, and how we can address both with FACT.
Why do Vision-Language-Action (VLA) models still struggle with contact-rich manipulation? 🤖
Excited to share our new paper: Demystifying When and Why VLAs Fail in Contact-Rich Tasks and How to Fix Them. 🧵 (1/8)
🤔 Can we train one VLA policy to control multi-robot teams without any explicit communication?
✨ Introducing CHORUS: a single policy for decentralized, multi-embodiment collaboration
🧵⬇️
Can we build generalist robots with zero teleoperation? Come participate in the discussion and weigh in at our ICRA'26 workshop, BeyondTeleop, starting at 8.45 am CEST today (June 5th)!
📍 Strauss 3
@jiaying_fang0 and I are presenting Masquerade this morning at #ICRA26
In Masquerade 🎭 we replace the human hands with robot hands and train a visual encoder that is far more effective than prior work.
Interactive Session 3 − WeI1I Hall C - 9-10:30am
https://t.co/6Q175pVnYJ
🚀CFP open: #RSS2026 Workshop on Robot World Models 🇦🇺🐨🌏
📜Submit 4 page novel work or 1 pages abstract of published work!
⏳Deadline: June 5, 2026
💰🥇✈️More info about awards and travel grants:
https://t.co/Z7Oim9MKVm