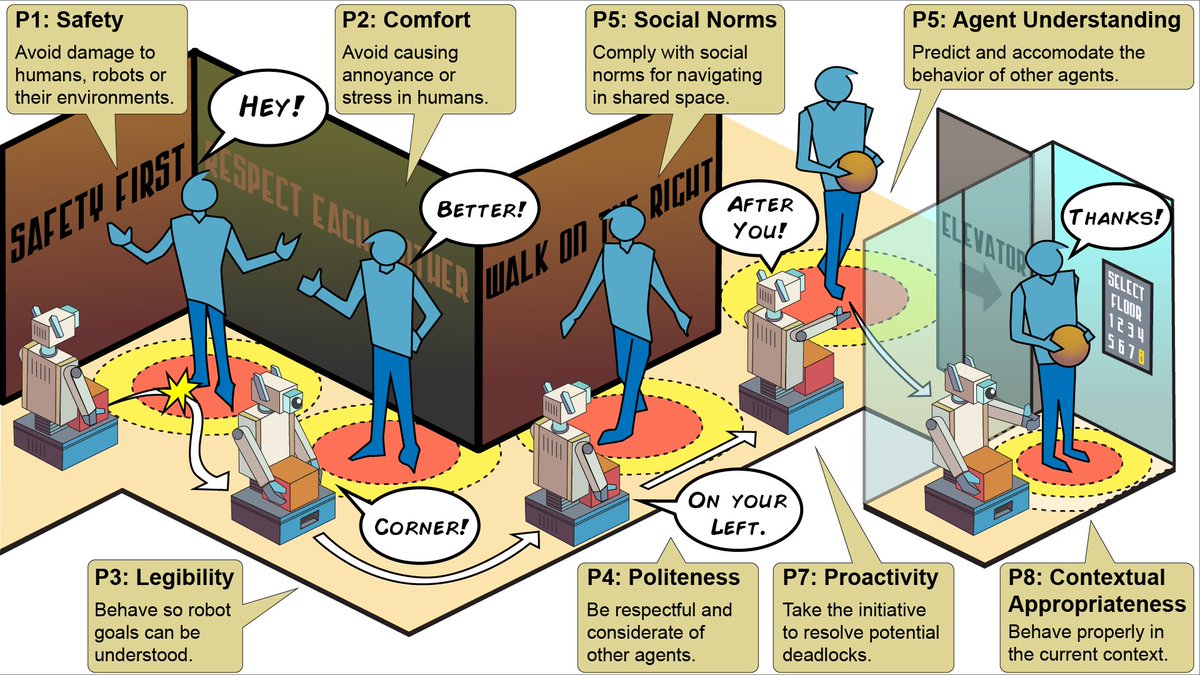
🤖 Only a few weeks to go until the 5th Workshop on Social Robot Navigation at #IROS2026!
📢 Paper deadline extended to Sept. 15!
If you’re working on social navigation, HRI, embodied AI, robot learning, or related topics, we’d love to see your work!
🔗 https://t.co/LSFeQVFKKU
1/3
Another paper from @amrl_ut at ICRA 2026: BEV-Patch-PF, a GPS-free system for off-road geo-localization.
Why? Odometry drifts, GPS can fail, and matching onboard views to satellite imagery is hard in unstructured terrain.
Thread 🧵
@_mohansolo@Presidentlin Thanks for the clarification. Would love the pop-out feature back. Must be a bug that often when a long running task is started by the agent, there is no way to stop it. It just keeps setting timers and checking. Can't hit stop (no button visible) or ctrl-c the original process.
@_mohansolo@Presidentlin The ability to pop out a running terminal that the agent started seems to have been removed in AG2. This makes it difficult to find and kill long running processes taking up system resources. Also, can I stop the agent when it's waiting for the process to exit, @_mohansolo?
At RSS 2024 next week, the Unsolved Problems in Social Robot Navigation Workshop will bring robot navigation researchers together to discuss making robots move better around people!
The workshop is July 19, 2024 from 1:30 to 6:
https://t.co/Tch6CTsXmw
#socialnav#rss2024
Let's make our robots move better around people! After a year and a half, I'm proud to announce the Social Navigation Symposium's paper on "Principles and Guidelines for Evaluating Social Robot Navigation Algorithms" is now a preprint on arXiv: https://t.co/SKZIP2CTwe #socialnav
@EMostaque How about starting with open source actuators that everyone can afford. E.g. https://t.co/Q0ccSmnHjf which we use for https://t.co/LyCbl5zx7f
#HRIPioneers2023 Kayla Matheus (@KaylaMatheus) will present her work on 'Socially Assistive Robotics for Anxiety Reduction' @HRI_Conference!
Kayla's website: https://t.co/aluyQg4w07
Check out the full list of participants on our website: https://t.co/o2EsxeZIGM
Congratulations to Dr. Meiying Qin, my 14th PhD student! Meiying built a system that allowed robots to use tools from only a few human examples, to transfer that knowledge to novel uses of the tool, and even to transfer learned skills from one robot to another.
Join us tomorrow at our @ieee_ras_icra workshop on "Social Robot Navigation: Advances and Evaluation", featuring a great line of speakers, papers/posters & interactive tutorial!
Full schedule: https://t.co/mOxOJDhGbw