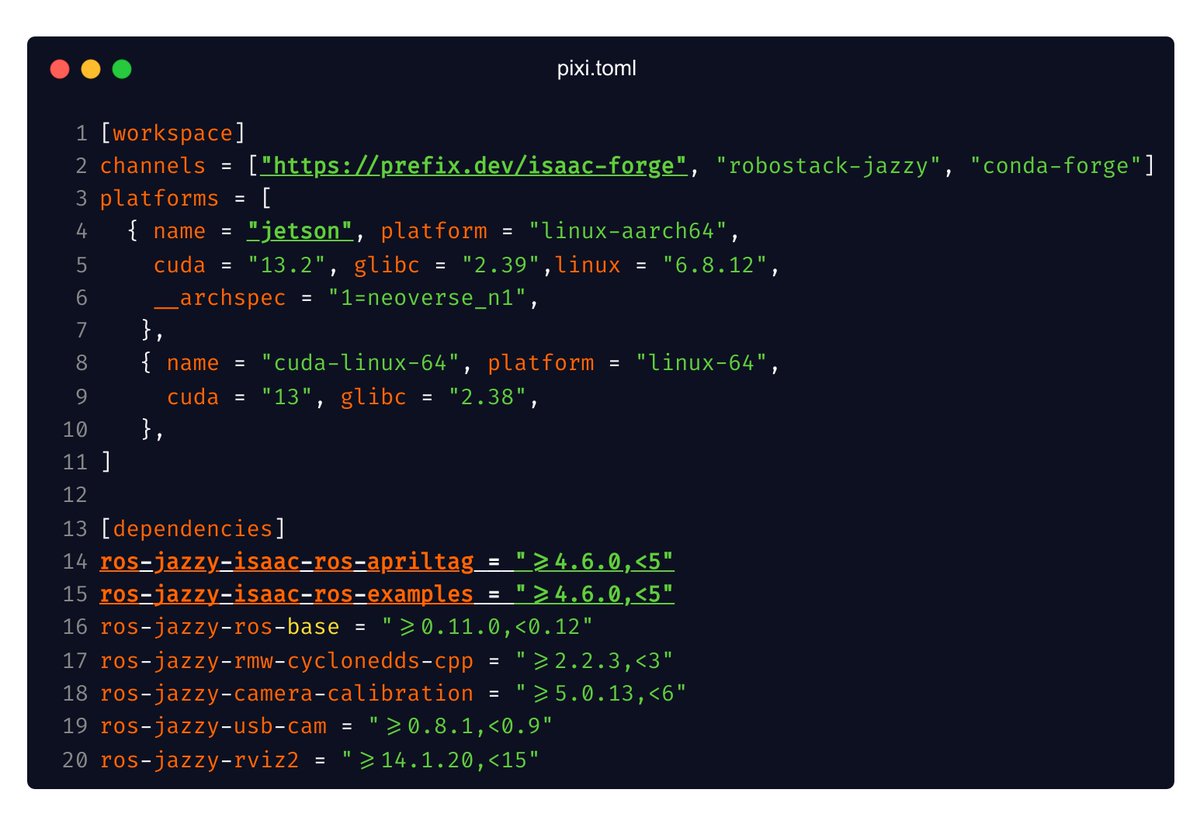
We wrote a blog that's a little different from what we normally publish.
It's more focused towards starting out with ROS, and avoiding the complexity of installation. Is this interesting content for you? Should we make more of this?
https://t.co/PcwZ7Q969K
#ROS#ROS2#robotics
Building bridges between open-source projects is a big part of why I joined @marimo_io.
I got to know the @prefix_dev folks through @SciPyConf, and worked together to make computational research easier to reproduce and share.
Special thanks to Julian and @rarts_ruby!
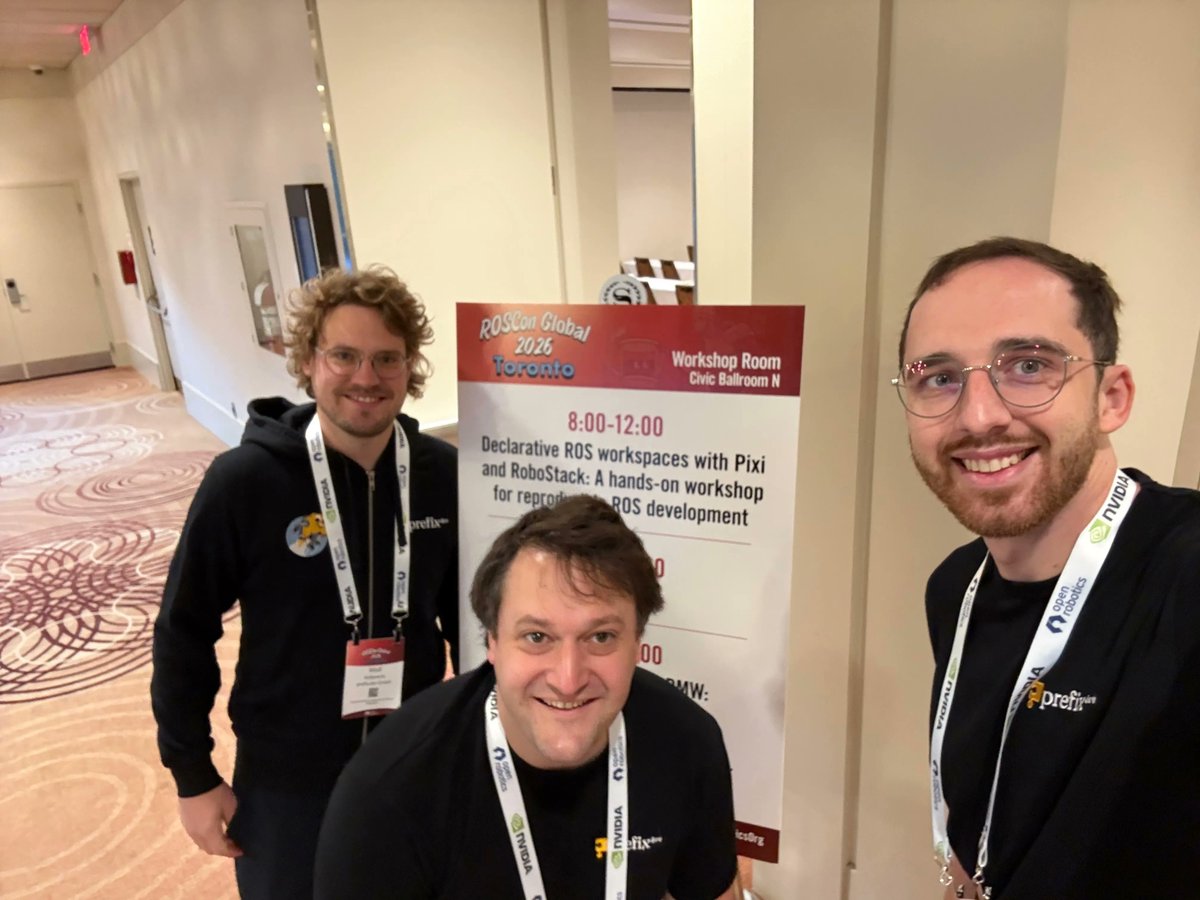
The Pixi team is at ROSCON in Toronto - come find the yellow backpacks if you want to chat! We keep spotting Pixi in so many cool robotics projects and it's making us proud. To get a glimpse of what we're working on, join the talk about the EU CRA this afternoon!
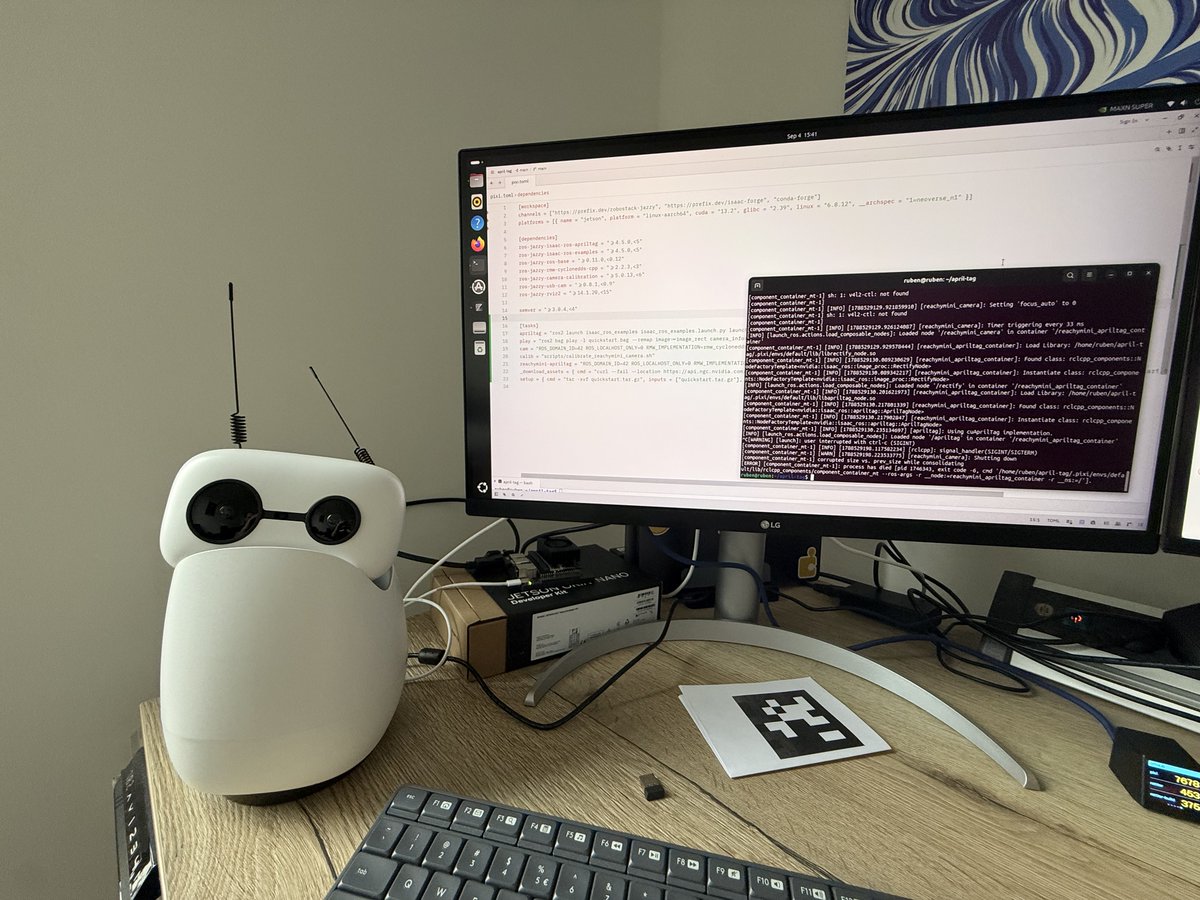
We made it easy to install Isaac ROS! The new `isaac-forge` repository contains many upstream NVIDIA Isaac ROS packages to make them installable with Pixi. You can test it today on your #NIVIDA#Jetson!
No docker needed!
https://t.co/m4HyXF9wRg
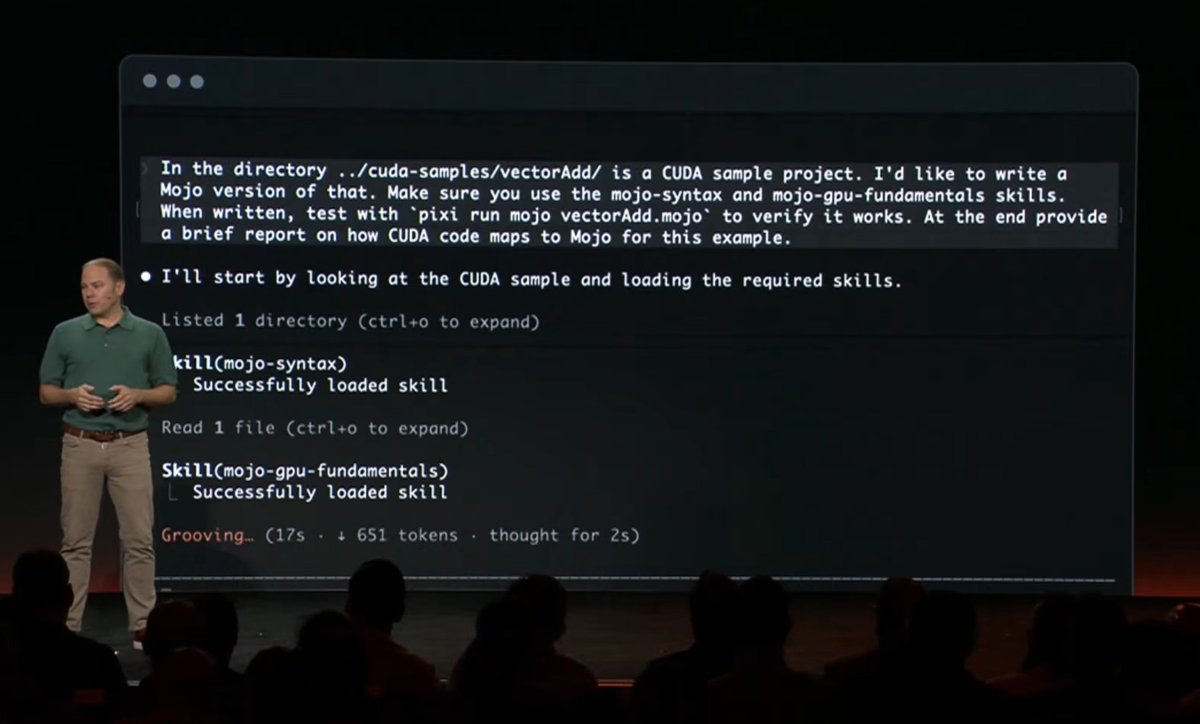
Congratulations to the Mojo 1.0 release @Modular! So glad to have you in our community, and seeing @clattner_llvm on stage with `pixi` in the background was definitely a highlight for us.
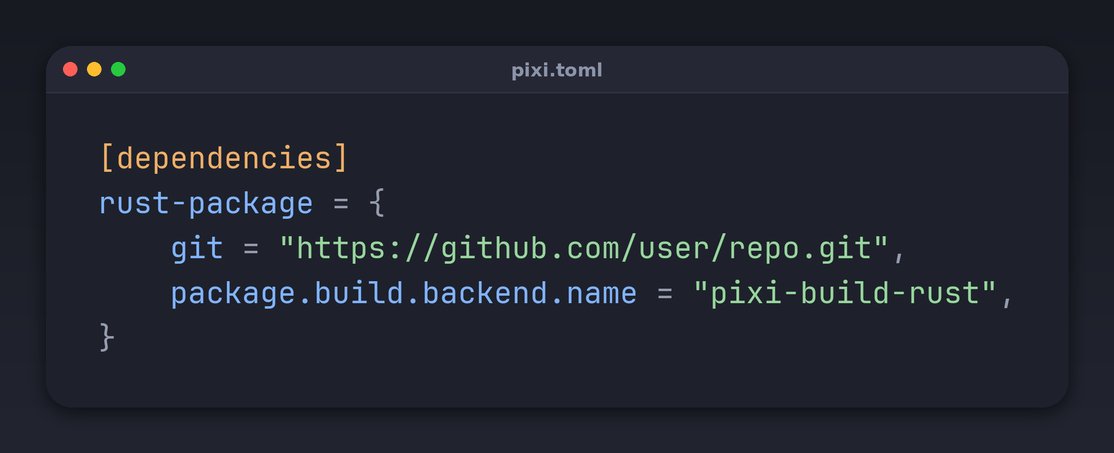
Use pixi global to install any project from source now.
Pixi global supports the full package spec to configure the neccesary information to install it directly, without a pixi.toml.
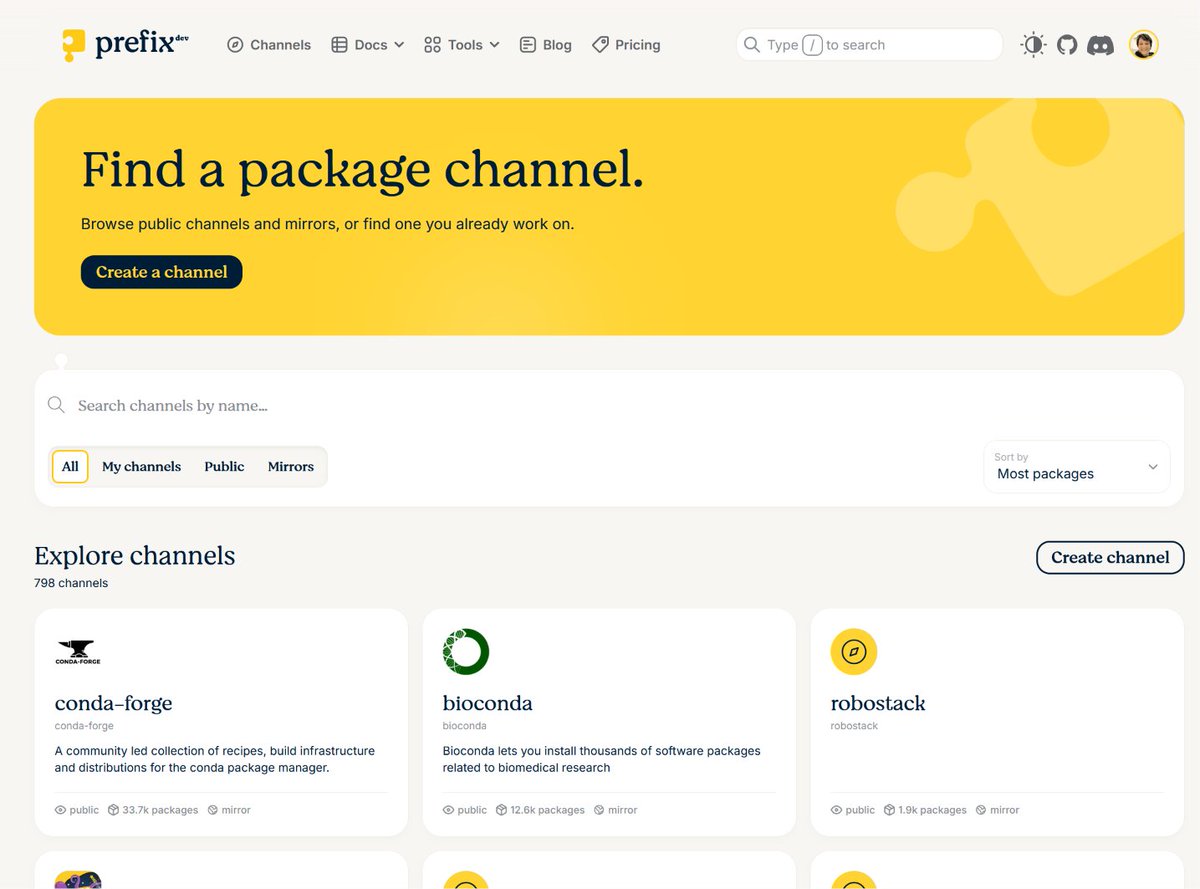
As our server grows (600+ channels!) we had to redesign our channel page. It offers you an easier way to find your own or other interesting channels to fetch packages from!
We've been driving one of the biggest changes to the conda ecosystem since its inception: repodata v3.
Extras, conditional dependencies, and variant flags, expressed directly in the repodata. Now in beta 👇
https://t.co/L0UuazsbHO
🛠️ Talk Spotlight: Why does scipy use pixi.toml? @rarts_ruby explains how Pixi solves scientific Python's toughest dependency challenges; C++, Rust, CUDA, Fortran, all in one tool 🚀 #SciPy2026 🔗 https://t.co/C08CDhqkNQ