We taught a robot how to move around in only 15 minutes.
That’s all the mobility data our Direct Video-Action-powered robot needed to accomplish a task that requires mobility and manipulation.
Robotics founders tell me constantly: Jay, it's never been easier to get a pilot today but its getting harder than ever to get that damn purchase order.
So I asked @startupjag how @rhodaAI solved for this in front of 200+ founders at Dirty Jobs. Between Infinera, QuantumScape, and now Rhoda, Jagdeep Singh is possibly the most successful person at selling frontier tech to skeptical buyers.
His advice to startups: More buyers want pilots today than Physical AI startups can possibly fulfill. So the hard job is ruthlessly prioritizing the ones that have the highest chance to convert to paid POs.
Oh and make sure to check the factory Wifi first. Just trust him on that one. Ep 105 with lots of tactical advice from among the best to ever do it.
Live from Dirty Jobs 2026 👇
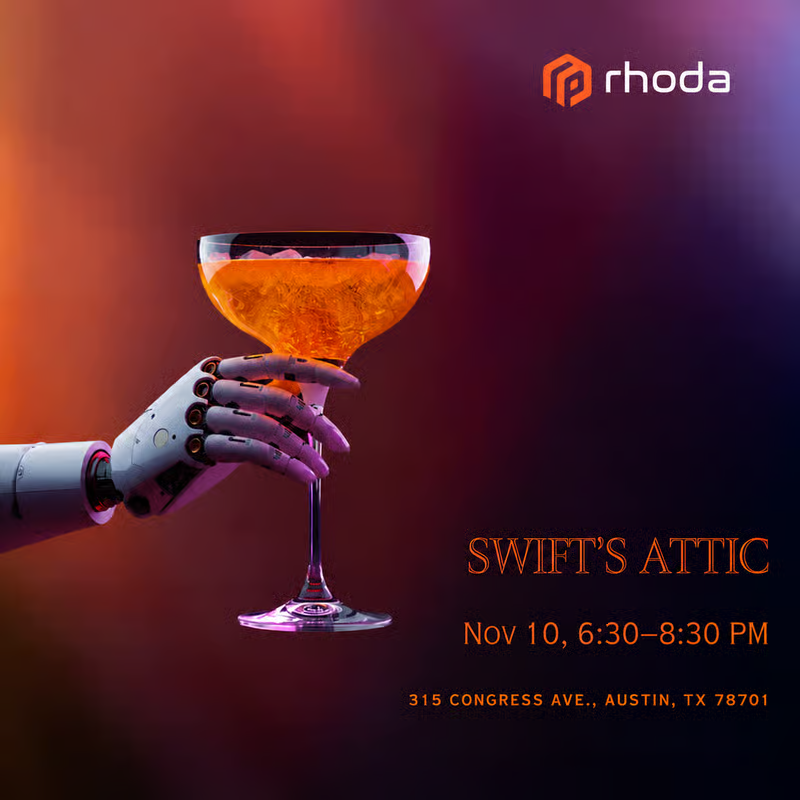
Thank you to everyone who joined our Video Models Meet Robotics reception at #CoRL2026 last night 🍸
200+ came through Swift’s Attic, and the conversations kept going on the sidewalk well after we closed!
Great meeting so many of you in Austin 🤖
Rhoda will be at #CoRL2026 in Austin 🤖
🍸 Tue Nov 10, 6:30–8:30 PM: Video Models Meet Robotics reception at Swift's Attic. Invite-only, request a spot: https://t.co/xIXYGuSu2f
🎤 Thu Nov 12, 11:25 AM: Vincent Sitzmann @vincesitzmann speaks at the "Do Robots Need World Models?" workshop
https://t.co/8cxdELBfoM
How? DVA imagines what it should see next, then turns that predicted video into arm and base actions.
Web-video pretraining and existing manipulation skills do the heavy lifting, so a little mobility data goes a long way.
Research + demos: https://t.co/NfgkMk1WKJ
We taught a robot how to move around in only 15 minutes.
That’s all the mobility data our Direct Video-Action-powered robot needed to accomplish a task that requires mobility and manipulation.
The Rhoda Direct Video-Action (DVA) model handles both mobility and manipulation. It can move, handle objects, and adapt to changes in the environment. One policy. No maps. No SLAM. No navigation planner.
Robots rarely fail on the clean runs. They fail on the edge cases.
On Field Trips, @schrep and @gigascale watched our robot hit one live on camera and work through it on its own, with no human stepping in.
That's what out DVA model is built for.
🎥 https://t.co/xq21Kfe8VW
What can a robot do without vision?
We gave our robot a sense of touch and showed it can recognize and retrieve objects with its cameras blindfolded.
Introducing Rhoda’s new tactile sensor—it feels pressure, texture, vibration, slip, and temperature, just like your fingertips.
As humans, our sense of touch complements vision, helping us manipulate objects even when we can’t see them clearly
Giving robots a sense of touch will help them pick parts from cluttered bins, align connectors, and adjust their grip as objects slip—even when vision falls short
As humans, our sense of touch complements vision, helping us manipulate objects even when we can’t see them clearly
Giving robots a sense of touch will help them pick parts from cluttered bins, align connectors, and adjust their grip as objects slip—even when vision falls short
At Rhoda, we turn real-world robotics challenges into opportunities for fundamental research.
Interested in building the future of robotics? Explore opportunities and apply: https://t.co/3gRRfieuTM
Continuing our RhodaAtWork series with another look at Direct Video-Action (DVA) in action.
This time, a single model handles multiple tasks across two home appliances: refrigerator EPS foam installation and washing machine drain hose routing.
In addition to contact-rich interactions, this application showcases other examples of coordination between the two arms.
Here, the right arm hooks and opens the strap while the left arm routes the drain hose behind it.