It would be interesting to see how it performs under current LLM’s training recipes of pre training, mid training and post training stage. I think this is like a discovery problem that you would like the agent to find the best solution for your optimizer in training time under different model/task settings, but for such discovery problem normally requires different domains methods to see the effectiveness.
Introducing NavSafe-∞: an open, photorealistic CL benchmark with 280 event-based scenarios across 28 safety-critical event types.
Across 20 E2E policies, we expose the OL-to-CL safety gap.
Project, paper & code: https://t.co/WYpjh60fSh
(1/5)
We are thrilled to introduce the first cohort of Vals Fellows!
These five researchers are building evals that tackle some of AI’s most important questions: from model safety to formal mathematical reasoning, as well as real world engineering and security challenges.
Get to know the researchers building the next generation of evals in the thread below.
Meta just released Muse Spark 1.1 and is the new SOTA on MedScribe and TaxEval, taking the top spot from Fable 5 while being 10x cheaper and twice as fast. Meta currently holds the top 2 spots on TaxEval
It is also the new #1 on Harvey's Legal Agent Bench, dethroning Grok 4.5 less than 24 hours after it took the top spot.
Congrats to the Qualcomm Innovation Fellowship NA winners 👏
PhD research + mentorship from @Qualcomm engineers = real-world impact.
See what they’re building:
https://t.co/I5e1ONUyNk
Excited that our paper StreamdiffusionV2 received the Best Research Paper Award at #MLSys26!
🚀Video generation is quickly moving from demos to production-facing workloads. It is no longer a turn-based pipeline but should be a streaming pipeline to interact with users.
📖Our project page: https://t.co/ItuO5zc6hT and paper: https://t.co/fmz2irYIm1
👂Come join the talk if you are interested in streaming video generation. Our talk will be at the Research Track Oral Presentation: Best Paper Session on Tue 8:45AM at #MLSys26 , I will talk about how we attacked the efficiency and quality challenges. Hope to see you there!
❤️Huge thanks to all authors! This work would not have been possible without the incredible effort from the entire team. Big shout out to Tianrui Feng, Zhi Li, @Andy_ShuoYang , @HaochengXiUCB, @lmxyy1999 , @lvminzhang , @xiuyu_l , Keting Yang, @ZiqiPeng, @songhan_mit , @magrawala, @KurtKeutzer , and @cumulo_autumn
Introducing #WorldEngine, https://t.co/UK3vsulS2u, a two-year long project. The missing infrastructure for Physical AI post-training in Autonomous driving. Open-source. Production-validated.
Thrilled to share that our paper 𝐀𝐮𝐭𝐨𝐕𝐋𝐀 has been accepted to 𝐍𝐞𝐮𝐫𝐈𝐏𝐒 𝟐𝟎𝟐𝟓! See you in San Diego! 🦭
🗓️ Dec. 3 (Wed), 11:00 AM – 2:00 PM PST
📍 Exhibit Hall C,D,E # 2208
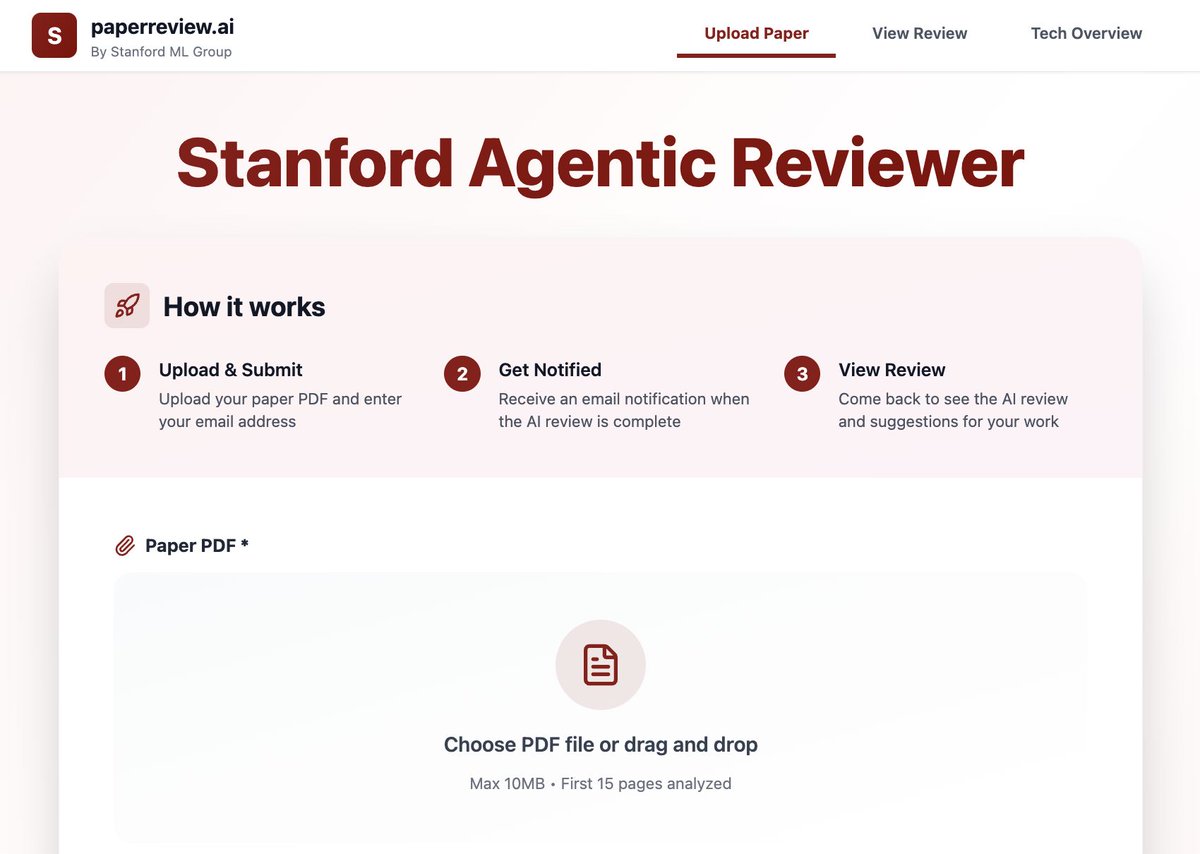
Releasing a new "Agentic Reviewer" for research papers. I started coding this as a weekend project, and @jyx_su made it much better.
I was inspired by a student who had a paper rejected 6 times over 3 years. Their feedback loop -- waiting ~6 months for feedback each time -- was painfully slow. We wanted to see if an agentic workflow can help researchers iterate faster.
When we trained the system on ICLR 2025 reviews and measured Spearman correlation (higher is better) on the test set:
- Correlation between two human reviewers: 0.41
- Correlation between AI and a human reviewer: 0.42
This suggests agentic reviewing is approaching human-level performance.
The agent grounds its feedback by searching arXiv, so it works best in fields like AI where research is freely published there. It’s an experimental tool, but I hope it helps you with your research.
Check it out here: https://t.co/n7ctnDilJJ
After 18 months in stealth, dozens of prototypes, millions of real-home demonstrations, and one final all-nighter, we’re thrilled for you to say hello to Memo
Excited to share my 𝐭𝐰𝐨 𝐟𝐢𝐫𝐬𝐭-𝐚𝐮𝐭𝐡𝐨𝐫 𝐩𝐚𝐩𝐞𝐫𝐬 accepted at 𝐈𝐂𝐂𝐕'𝟐𝟓!🌺
🤔 Can multi-agent collaboration move us beyond single-frame perception toward spatio-temporal scenario understanding, facilitating end-to-end optimization across multiple driving tasks?
🚗Join us at @ICCVConference 2025 Tutorial!
📌Beyond Self-Driving: Exploring Three Levels of Driving Automation
📅Oct 19 (Sun), 8:50 – 12:10
📍Room 308A
Discover how self-driving is evolving from single-vehicle intelligence to connected, cooperative, and city-scale systems.
📢 Excited to sharing a little late update (before it is no longer news): I’ll be joining @UTAustin@UTCompSci as an Assistant Professor! I'm recruiting PhD students from @UTCompSci in the Fall 2025 cycle and also looking for RAs/interns! More info see https://t.co/JPDhVplhJX
It's my pleasure to share that our project CooPre: Cooperative Pretraining for V2X Cooperative Perception has been accepted by #IROS2025 and awarded Best Paper at the #CVPR2025 DriveX Workshop (https://t.co/Mk4DfAx0D9)!
Paper could be found at: https://t.co/5lM4xXjJPM
CooPre tackles a major challenge in V2X Cooperative Perception by introducing a multi-agent self-supervised pretraining framework that enhances data efficiency in multi-agent systems.