Our human-to-sim-to-real pipeline works surprisingly well with GR00T 2! 🤖🔨
👀 One egocentric human video
🛠️ Reconstruction → RL → visual rollouts
🧠 SFT GR00T 2 on 1.5K simulation-only rollouts
🚀 Zero-shot real-world deployment
No real robot training data!
🧵 for details.
Human → Sim → Real: turning human videos into robot skills.
Join us at CoRL for “From Human Videos to Dexterous Robot Capability: A Hands-on Tutorial”! https://t.co/92R9yMjv6c
📅 Thursday, November 12, 2026 | 2:00–6:00 PM CST
📍 Hilton Austin, Salon D · Austin, Texas
We’ll share a detailed walkthrough of the complete end-to-end video-to-data pipeline that enables “Human → Sim → Real” adaptability for GR00T 2—from human demonstration videos through simulation to training data for real-world robot skills. https://t.co/LwhBs3yfO1
We’ll also feature:
• A panel on the future of robot learning from humans, exploring opportunities and open challenges.
• The announcement of the V2D Challenge winners, followed by presentations from the winning teams on their solutions.
Kudos to the panelists, instructors, and organizers bringing this tutorial to life!
Panelists:
• @Jeannette Bohg — Stanford University @leto__jean
• @Kuan Fang — Cornell University @KuanFang
• Yuting Ye — Meta
• Kaifeng “Alex” Zhang — Sharpa
• @Roei Herzig — UC Berkeley @roeiherzig
• Louis Lian — Lightwheel
• Javier Romero — Meta
• Yan Chang — NVIDIA @Dr_YanChang
Instructors: @zhu_xinghao, @Mrinal_Verghese, @bowenwen_me, Zeo Liu, @shalin_sj, @Naema Bhatti, and @_abraranwar .
Organizers: Xinghao Zhu, Yan Chang, Zixi (Zeo) Liu, Bowen Wen, Mrinal Verghese, Shalin Jain, John Welsh, Daniel Zou, Abrar Anwar, Naema Bhatti, Michael Lin, Kuan Fang, and Joydeep Biswas.
Thank you for sharing your expertise and making this hands-on learning experience possible!
Explore the agenda and join us: CoRL tutorial details.
#CoRL2026 #RobotLearning #PhysicalAI #GR00T #VideoToData #NVIDIA
Huge thanks to all the collaborators from @NVIDIARobotics! See more details on our project websites.
🌐 Project Website: https://t.co/6FU88WVCZH
🌐 Gr00t 2: https://t.co/NWCr8SSsth
🌐 Video 2 Data: https://t.co/ctpT4m6AXD
In Austin for CoRL 2026! I’ll be sharing “Learning Dexterous Manipulation Using Contact Wrench Guidance From Human Demonstration” with my co-authors @zhu_xinghao, Zeo Liu, @Dr_YanChang.
We propose CHORD, which we used to teach Gr00t 2 dexterous tasks only in sim! Details ⬇️
Excited to chat throughout the rest of the week, you can find me at,
📋 Poster session 3 • Wed 11/11, 10:30 AM–12:00 PM
🤝 NVIDIA Meet the Researchers • Tues 11/10 4:30-5:30
🗂️ Co-organizing “From Human Videos to Dexterous Robot Capability” • Thurs 11/12 2:00 PM - 6:00 PM
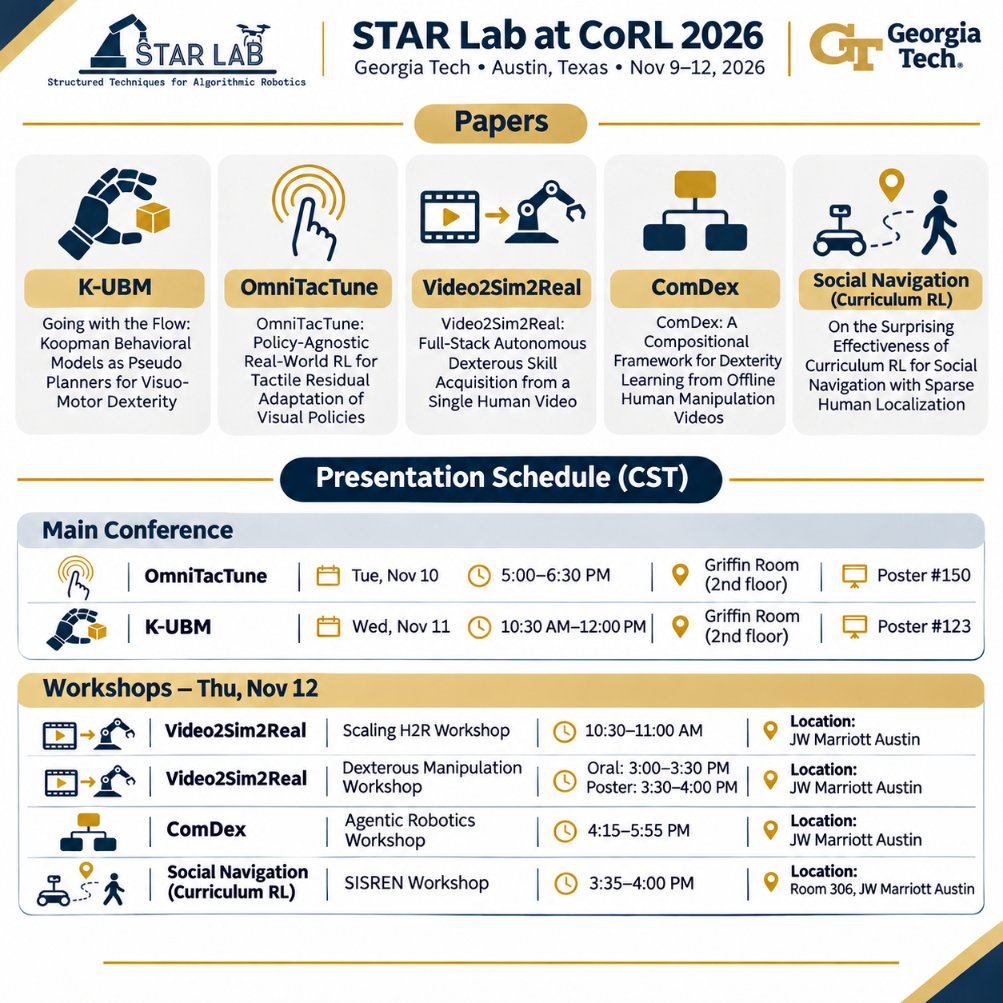
Heading to #CoRL2026. Students from our lab will be presenting on various projects, ranging from behavioral dynamics to social navigation!
📢 I am hoping to recruit a PhD student and a post doc for Fall 2027. Please feel free to come say hi!
Looking forward to catching up with old friends and meeting new people.
P. S. Foundation models have made me too lazy to manually create visuals and obsess over every detail! But I honestly don't know if I love or hate this!
Training scales from a single GPU to an entire cluster, targeting demanding perception-in-the-loop workloads.
Massively parallel simulation lets policies learn from a wider range of experiences, supporting more generalizable skills and increasingly complex tasks.
(5/7)
What could robots learn from the videos we already have?
Join the Video to Data (V2D) Challenge to help turn human demonstrations into robot skills for 3 tracks:
🔹 4D Reconstruction
🔹 Robotic Grounding
🔹 Egocentric Video-to-Policy.
You'll have the opportunity to:
🏆 Earn recognition at #CoRL2026, where the winning solutions will be announced
🛠️ Receive evaluation at scale, with top teams invited to integrate their code into a maintained repository
📋 Contribute to the challenge’s technical report
Register here by September 21, 2026:
https://t.co/gYuCSSZc7h
Super excited to share CHORD, our work on learning bimanual manipulation from human demonstrations.
CHORD demonstrates strong capabilities in mimicking human dexterity from both egocentric and third-person-view videos, across platforms including mobile manipulators and humanoid.
Contact-rich dexterous manipulation continues to be hard, even with human demos. In our work, we propose using the contact wrench space to capture diverse human manipulation behaviors, tackle long horizon tasks, and transfer to different embodiments — in a single objective!
How can robots learn dexterous manipulation from human demonstrations at scale?
Excited to share CHORD: Learning Dexterous Manipulation Using Contact Wrench Guidance From Human Demonstration.
CHORD learns from human demos by focusing not only on where contact happens, but how that contact moves the object through force and torque guidance.
This unified contact-wrench representation carries human manipulation skills across diverse behaviors, long-horizon tasks, whole-body embodiments, and real-world hardware.
We evaluated CHORD on large-scale, long-horizon, contact-rich tasks paired with human demonstrations, spanning rigid, articulated, and multi-object manipulation.
At scale:
* 82.12% average success across 1,831 tasks
* 90.77% whole-body manipulation success
* 4,739 sim-ready dexterous manipulation benchmark
* Transfer to real dexterous hands
Project page: https://t.co/cAnHaJUy6P
Tech report: https://t.co/oWMzszwrgw
Code will be released soon as part of Video to Data repo https://t.co/spdPL4Gxt6, our end-to-end pipeline for converting human demonstration videos into simulation-ready assets and physics-grounded robot training data.
Huge thanks to amazing contributors: @zhu_xinghao , Zixi Liu, Shalin Jain, Chenran Li, Milad Noori, Huihua Zhao, John Welsh, @michaelv03, Wei Liu, @TingwuWang , Xingye (Dennis) Da, @zhengyiluo, Vishal Kulkarni, @sNaema, @yukez, @DrJimFan, @bowenwen_me, @danfei_xu, @SohaPouya, @Dr_YanChang.
#Robotics #PhysicalAI #DexterousManipulation #RobotLearning #NVIDIA
Can a robot acquire real-world dexterous manipulation skills from just human videos?
Meet Video2Sim2Real: full-stack autonomous dexterous skill acquisition from a single RGB-D human manipulation video — without robot data or expert intervention.
Project: https://t.co/gegklCcs5A
Paper: https://t.co/5AcK8NFQAM
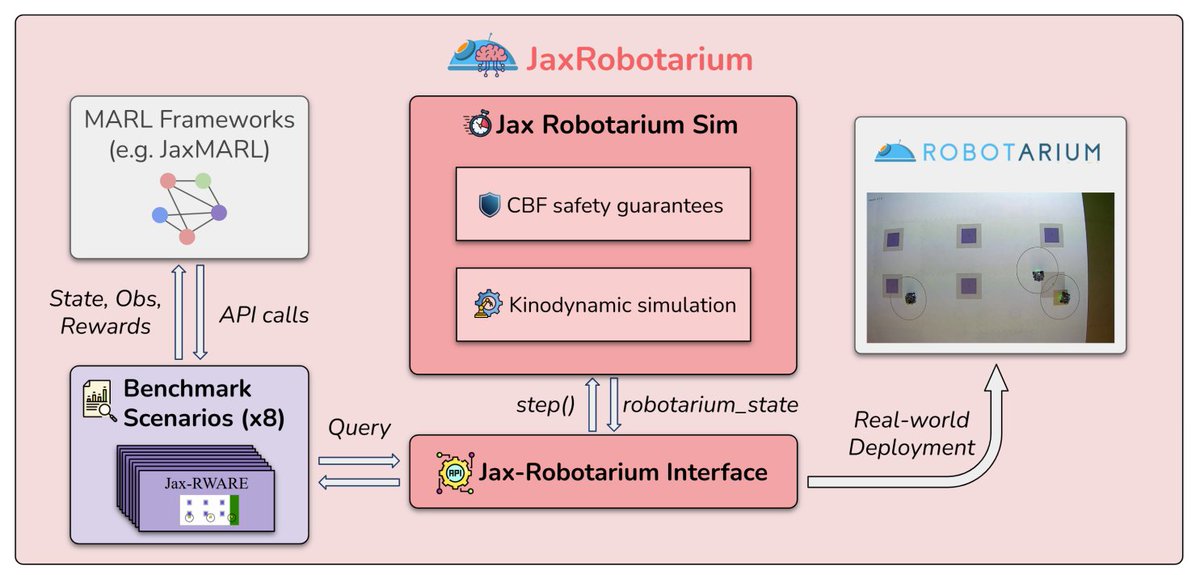
At #RSS2025 WS on multi-robot systems, Shalin Jain will introduce JaxRobotarium, a Jax-based open-source framework for *anyone* to train and *physically* deploy MARL policies in *minutes*!
🕤2:30pm PT
🏢OHE 132
🪧Poster 43
🌐 https://t.co/a09qdbcQdh
🔗 https://t.co/4IRTdNTVVC