If you want a vision encoder for dexterous manipulation, what should be the most important part to model? 🤔
Current standard models like CLIP, SigLIP, and DINOv2 have an incredible grasp of semantics and spatial details. But they lack the action-centric structure needed for downstream visuomotor control.
But collecting annotated robotic trajectories at scale is SUPER expensive and largely unrealistic. So, how do we bridge this gap?
We introduce CAIP (Contrastive Action-Image Pre-training) ⬇️
🔸 Action-centric upstream: we align visual observations with action chunks through a contrastive objective.
🔸 Human video as a proxy: we represent 3D human hand poses analogously to robotic end-effector actions, tapping into a massive source of human demonstrations.
🔸 Massive scale: pre-trained on over 32,000 hours of manipulation video, driving both sample efficiency and robust generalization.
🔸 Hardware proven: achieves a 76% average success rate on a real-world Dexmate Vega bimanual @DexmateAI manipulator with dual 22-DoF Sharpa Wave hands @SharpaRobotics .
🔸 State-of-the-art: significantly outperforms strong baselines like DINOv2, SigLIP, MVP, and Qwen3.5 ViT across complex tasks, even under unexpected lighting changes and visual distractors.
🌐 Project: https://t.co/ClUPZvXEDb
📝 Blog: https://t.co/B4wjkUPL0S
📄 Paper: https://t.co/4Xe3bqLJy5
💻 Model: https://t.co/sGIPPIlmFP
🚨 Call for participation: the Child–Robot Dexterity Challenge at the CoRL 2026 𝗦𝗣𝗜𝗡 𝗪𝗼𝗿𝗸𝘀𝗵𝗼𝗽! Bring your robot, or run on ours. Apply by Oct 5.
🧒🤖 Robots and a child will take on the same everyday tasks, side by side, live on stage. The demonstration offers a simple way to see what today’s robots can already do and where there’s still room to improve.
We make it easy to join:
- Bimanual YAM setup (MolmoAct 2 style) + a dexterous Sharpa hand setup, provided on stage.
- Bring your own hardware (subject to approval).
🌐 Website: https://t.co/eDmETdSTz0
🗣️ Speakers & panel from Stanford, Columbia, TU Darmstadt, and AMI Labs.
📍 Nov 12 · Austin, TX
#CoRL2026
Gemini Robotics 2.5 is here. 🤖
Our latest physical AI is able to learn hundreds of everyday skills - from folding laundry and serving pastries to autonomously sorting car parts on the factory floor.
Here’s a snapshot of its capabilities 🧵
#CoRL2026 thoughts: I truly believe that for robotic harness to move forward, we need to converge on a much more structured approach, one that doesn’t brute-force the entire search space. We can’t keep spending thousands of dollars to solve a simple task!
More on that soon!
Fable 5.2 shows substantially improved skills in controlling physical robots, even on tasks it has never explicitly been trained to do.
On RoboDojo, a benchmark with a simulated two-arm robot, it outperformed other models and most AI systems built to control robots.
#CoRL2026 starts tomorrow, and for the first time, I brought my oldest son, Adam, along!
He's taking part in the robot-child competition at our workshop, and I thought it would be a great opportunity to show him the world of robotics he's so excited about.
Fun twist: he's also starting a robotics camp tomorrow. Let's see how deep they go!
So if you spot me walking around with an 8-year-old, come say hello 👋
@menhguin In my experience, even many PhD students are effectively doing it "on their own time". The more capable the student, the less the mentor needs to intervene. But a strong PhD program introduces you to many fellow researchers and builds a strong network. That's harder to do alone
Continuing to pour huge amounts of money into these models without a clear business model (e.g., spending six or even seven figures to solve a single math problem) isn’t economically sustainable. We need more sample-efficient algorithms to keep the ecosystem viable.
We don’t harness for every possible state; we do it through sample efficiency and structure. AI systems will need to follow the same principle to become usable. Otherwise, they won’t last.
A lot of folks have no idea how much work goes into organizing a superb conference. Kudos to all the organizers who put their hearts into it. I’m sure it’s going to be a blast event!
🔥 #CoRL2026 is officially SOLD OUT! And I’m on my way to Austin! ✈️
What a journey this has been! Together with my amazing fellow Program Chairs, @Majumdar_Ani and @fox_dieter17849, we’ve spent the past year working to make this year’s CoRL something truly special.
📈 A record-breaking 2,094 submissions, with 687 accepted papers showcasing the incredible progress in robot learning!
🌟 An outstanding scientific program, featuring inspiring keynotes from @wolfram_burgard, @RussTedrake, @drfeifei and a special conversation with Fei-Fei Li and @LisaSu!
💡3 Early Career Keynotes to give the spotlight to the next generation of leaders in robot learning @RobobertoMM@negar_mehr@zhaohang0124!
🚀 New initiatives we’re particularly proud of:
- A Late-Breaking Results track to bring the freshest ideas and emerging directions into the conversation, including Agentic Robotics and Real2Sim2Real.
- A strengthened reviewing structure with Senior Area Chairs to help us manage the growing scale of our community while maintaining scientific rigor.
Behind all of this is an extraordinary team of organizers, reviewers, area chairs, volunteers, and researchers who have worked incredibly hard to make it happen. Thank you all! ❤️
🤝CoRL has grown tremendously, but what makes it special is still the same: a community that brings together bold ideas, rigorous science, and a shared passion for advancing robot learning.
I can’t wait to see everyone in Austin, hear the discussions, discover new ideas, and celebrate our community together!
We’ve put our hearts into this program. I really hope you enjoy it! ❤️
See you at @corl_conf! 🤖
לכתוב ביקורות עם כלים של AI זאת ממש לא בעיה..יש בעיה רק אם הוא מחליף לחלוטין את היכולת שלך לקרוא ולקבל את ההחלטה במקומך.
כל עוד קראת את המאמר האקדמי, ��יבשת דעה, וקיבלת החלטה לבד יחד עם תימוכין, אין בעיה לתת לכל כלי לעזור לך לסגנן את זה, לייפות את זה, וכו.
Introducing Social Humanoid: a framework for socially responsive human–humanoid interaction.
Deployed on a Unitree G1, our hierarchical system combines high-level social reasoning with low-level control, enabling a humanoid to interact with a human partner.
Flying to Austin for @corl_conf! #CoRL2026
Excited to talk and share our ongoing research on VLAs, World Models, and even Structured Robotic Harness!
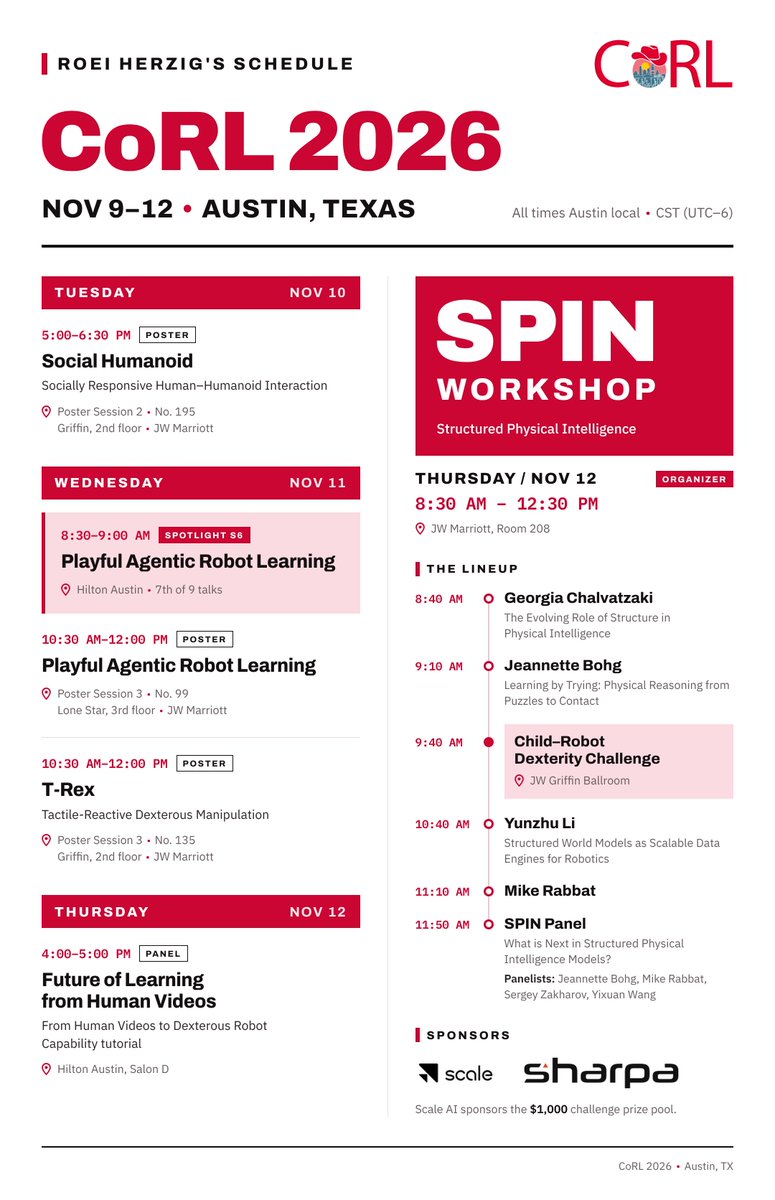
My full week is in the schedule below: posters, a spotlight, a panel, and our SPIN workshop on Thursday. Find me at any of them, or DM me to grab coffee and swap ideas.