Hard lighting cut our expert-only π0.5 checkpoint's success roughly in half. The same lights cost the full fine-tune nothing.
New from @castorhat: the fine-tuning ablations behind our IROS demo. https://t.co/JciqcCBMYy
We built a robotics data engine with Astra-level performance at 125x lower cost. And we are open-sourcing the weights today! Introducing Flora, a suite of open models to parse the physical world and turn raw footage into rich training signals.
Flora already powers our in-house data engine, labeling 200K hours of videos a day on 500 GPUs. We created it to scale the frontier for robot learning. Now you own the weights too.
Flora gives you:
- High-quality, timestamped captions to curate and filter human egocentric and robot data;
- Dense progress rewards for quality control and RL post-training;
- Rubrics scoring for real-world benchmarking
Try it today, links in thread:
X Square Robot has introduced TwinDEX: a co-designed pair of three-finger, 9-DoF dexterous hands, one wearable for data collection, one matched robot end effector for deployment.
The wearable and the robot hand share the same kinematics, geometry, materials, look, and sensors, so human demos map straight to the robot without retargeting.
Human data collection improves throughput 5.3x compared to teleoperation, and a policy can be trained with a few hundred episodes without any robot data.
UMI, but for humanoid hands.
UMI-style capture already works great for simple grippers. For a high-DOF hand, where the action space is huge and contact force carries the important signal, matching the data collector to the hand matters even more.
Chestnut just announced that pair:
Aero Hand, an 18-DOF human-sized dexterous hand (tendon/linkage hybrid, tested for 3M+ cycles), and
Aero UMI, a wearable exoskeleton whose kinematics exactly matches the robotic hand, with direct per-joint angle sensing accurate to 0.1°.
Zero embodiment gap for human data collection. Doubles as a teleop rig.
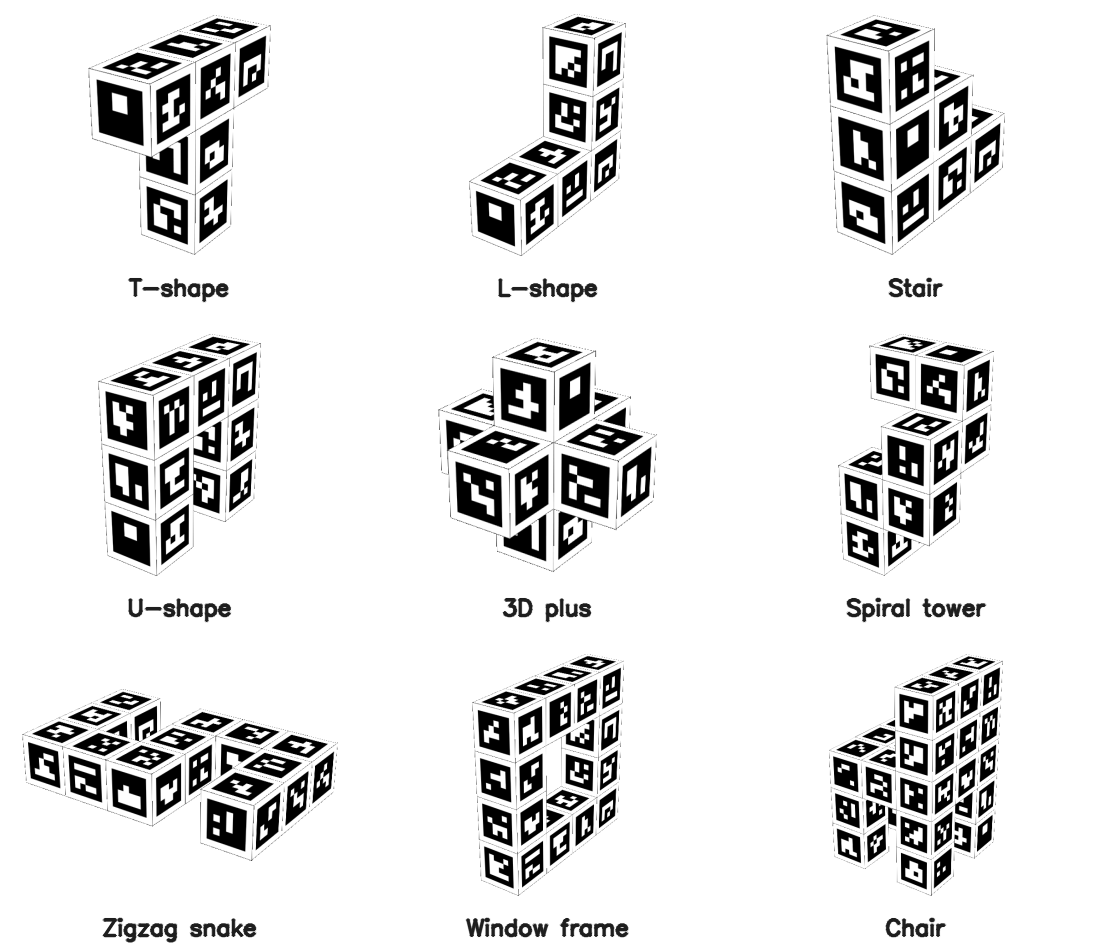
aprilcube
Generate 3D-printable cubes/cuboids with ArUco or AprilTag fiducial markers on all 6 faces, then detect their 6-DOF pose from a camera.
https://t.co/6mxt0B5ElF
GPT-6 Astra can solve some seriously tricky spatial constraint tasks: from unlocking interlocked parts to threading a rope through three rings.
Try it yourself now 👇
https://t.co/him6NbTI2a
@danfei_xu Can Insta360 provide accurate end-effector 6DoF pose estimation? Is the accuracy only at the centimeter level? Is this sufficient for pre-training?
Tesla Optimus Ankle Design
Paper discussed in this episode "A Framework for Optimal Ankle Design of Humanoid Robots" https://t.co/ByjjJTlAD6
Video: https://t.co/KdG5vmCx4V
@GoingBallistic5
Finally got to see the real @UnitreeRobotics R1 demo. Impressive hardware performance consistency — side flip 10 times in a row without much degradation.
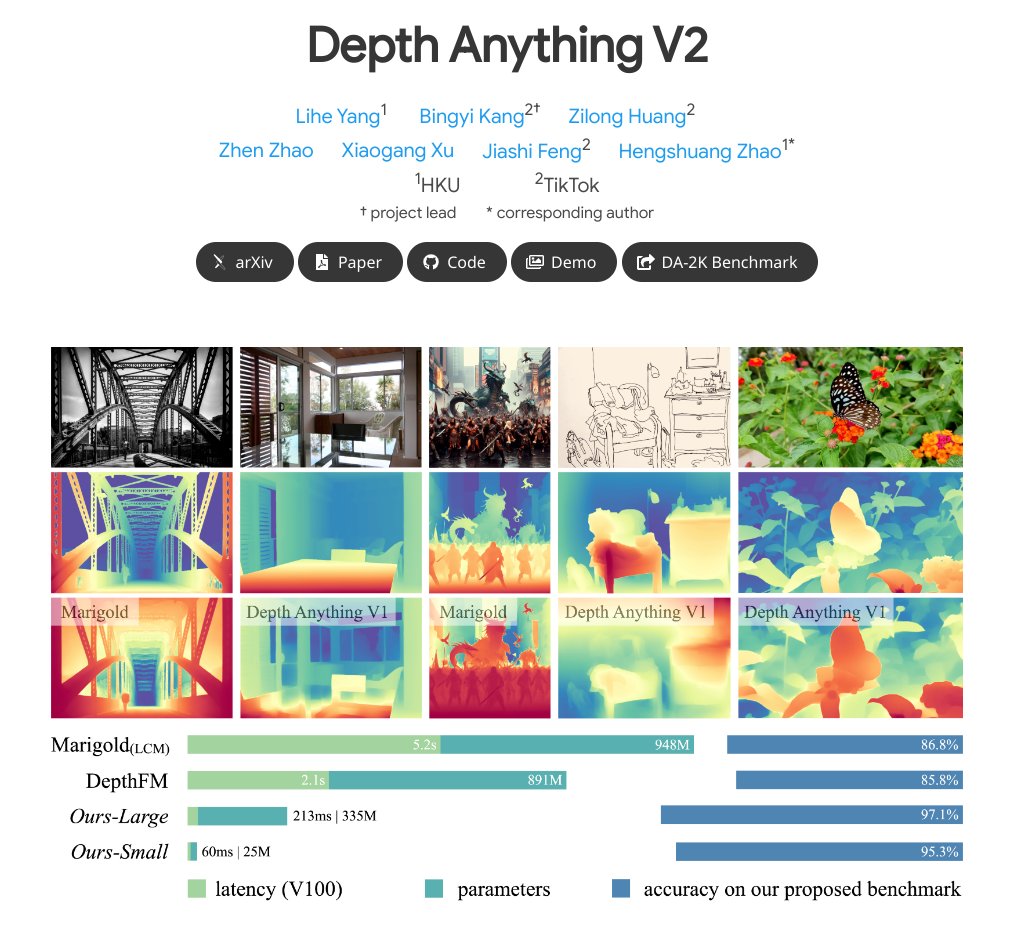
TikTok presents Depth Anything V2
Trained from 595K synthetic labeled images and 62M+ real unlabeled images, providing the most capable monocular depth estimation model
proj: https://t.co/KaOQauiOST
abs: https://t.co/9HxIpsPWJJ