@MKBHD I’m not. Will use SpaceX cold gas thruster system with ultra high pressure air in a composite over-wrapped pressure vessel in place of the 2 rear seats.
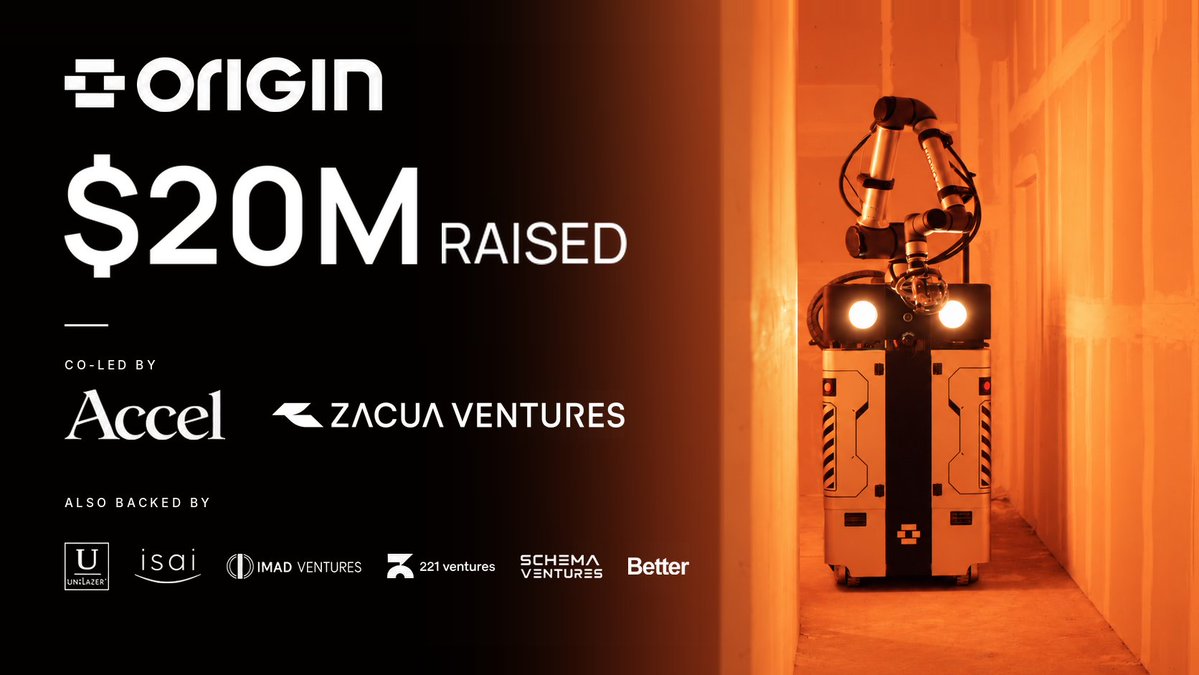
Thrilled to announce that @origin_autonomy has raised $20M in total funding, co-led by @Accel and @ZacuaVentures.
Excited to be building this with @ashishxdaga, @tusharmakkar08 and the super talented team at @origin_autonomy. We’re building general-purpose robots for interior construction.
Special thanks to @johnkoetsier at @Forbes for covering our journey.
News Article: https://t.co/YxjoyLdAfi
One of the largest announcements in the Physical AI Industry is coming soon 🤖🔥
If there is one page to follow very closely in the next 24 hours in the Physical AI space, it is @origin_autonomy ... 🦾
As I keep saying ... Physical AI is the next Trillion Dollar Market and we are so early to it 🔥
@yogesh_origin | @tusharmakkar08
@SahilBloom we’ve really convinced an entire generation that sitting on a couch without monetizing the experience is a character flaw. linkedin has done irreversible damage to the human brain.
What’s happening in the AI-powered reverse engineering and decompilation is absolutely insane. Pretty soon all software will be de facto open-source.
AI is coming for everything and everyone.
Your ROS 2 Robot Has a Heartbeat. What Happens When It Stops?
ros2_pulse is a clever low-overhead tool for watching your ROS 2 graph in real time.
It uses an LD_PRELOAD shim over the existing tracetools instrumentation, so there is no ROS rebuild, tracing session, extra DDS traffic, or special privileges needed.
It tracks per-topic message rates, node liveness, inter-process and intra-process traffic, and can also detect jitter and stalled topics.
The performance numbers are impressive too. In the project's stress tests, it added about 2% CPU overhead at roughly 4,900 messages/sec, while the hot-path counter measured around 0.3 ns/op on a fixed endpoint.
It supports ROS 2 Humble, Jazzy and Kilted, with JSONL output for feeding the data into monitoring systems or log pipelines.
For robots running perception, planning and control loops, this is the kind of small tool that can make debugging much easier.
Ramanujan wasn’t skipping proofs. He was hiding his chain of thought to prevent distillation.
Hardy: “Show your work.”
Ramanujan: “Sorry, reasoning tokens aren’t exposed via the API.”