@RosheedAkip7d Thanks! The KB is built entirely in sim for now, transfers directly to real tasks, and keeps refining and improving physical understanding during online solving.
What is the bottleneck for current robot RSI (recursive self-improvement) methods? They need to really understand the physical world instead of residing in virtual space.
We introduce RoboAuto: autonomous robot program search through multi-level physical understanding.
Paper: https://t.co/hxkExVxLet
Webpage: https://t.co/ny2Emx4eC2
🧵1/8
🔗 Browse the knowledge base, replay the search runs, and step through the method on our website!
📝 Paper: https://t.co/hxkExVxLet
🌐 Website: https://t.co/ny2Emx4eC2
Huge thanks to my co-leads @remi_ye and @XiuYuan0216, to my amazing collaborators @Jackson99f, @ChengsongH31219, and @persimmonmaxx, and to my advisors @YevgeniyV55066, @n1ngzh, and Chongjie Zhang.
🧵8/8
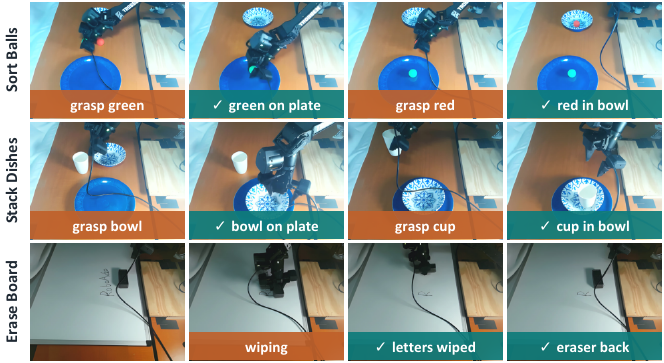
Real robot. Three challenging long-horizon tasks on a WidowX arm, each requiring precise manipulation: Sort Balls, Stack Dishes, and Erase Board. RoboAuto solves all three with near-perfect success.
🧵7/8
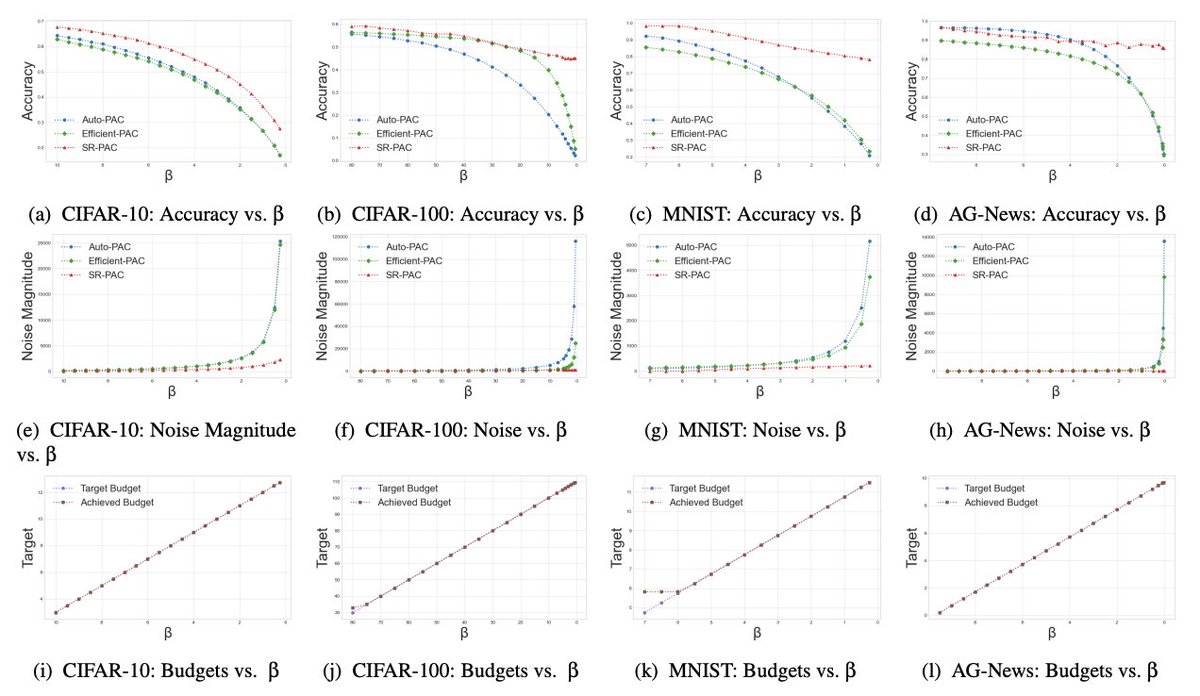
New paper from our group at USENIX Security 26: Residual-PAC Privacy: Automatic Privacy Control Beyond the Gaussian Barrier.
Led by @TaoZhang10086 and advised by @YevgeniyV55066
i gave astra a robot, a paint brush, and a camera then asked it to paint the golden gate bridge in real life!
it figured out how to control the robot, and progressively got better throughout its attempts. the timelapse is sick
✨ Egocentric videos are becoming an important source of embodied data. Recent works have explored how to use egocentric videos for robot foundation model pre-training and policy learning. We ask a complementary question: can egocentric videos be treated not only as action data, but also as a large-scale repository of behavioral prior knowledge? Can we build a structured memory bank from long-horizon human experience to support embodied question answering and robot planning?
🎉Of course we can ! Check out our new paper: "Memora: Embodied Action Memory from Egocentric Videos for Reasoning and Planning" presented as Oral Presentation at Foundation Model for Robot Planning Workshop at #RSS2026, led by my amazing mentee Zihao Yu.
🔗https://t.co/IAofu7NCTo
🧵 Read more below!
#Robotics #EmbodiedAI #AgentMemory #RobotLearning #Humanoid
2/ The intuition originates from GEPA's Pareto selection, which ensures broader exploration and reduces budget wasted on locally optimal lineages. Parallel proposals extend the idea by committing each step's budget to several extensions of the frontier at once.
https://t.co/0TTCz0zpun
1/ We just made GEPA’s optimization loop much faster, along with improved generalization!
Instead of proposing and evaluating one candidate at a time, each GEPA step now proposes a batch of candidates and evaluates them all concurrently. Parallel proposals significantly cut wall-clock time (3–4× faster) while, surprisingly, also generalizing better (up to +11 pts). 🧵