1/ muse spark 1.2 is a very strong multimodal model—it can do visual coding, robotics planning, and audio-visual understanding that all come together through agentic tools.
Our first version of Muse Ember 🔥
Ember aims to maximize intelligence per GW of inference to help bring personal superintelligence to everyone.
We would love all the feedback to keep hill-climbing. Please send it our way. We will keep hill-climbing on efficiency, user experience, and better approach to train with internal frontier!
More to come 🫡
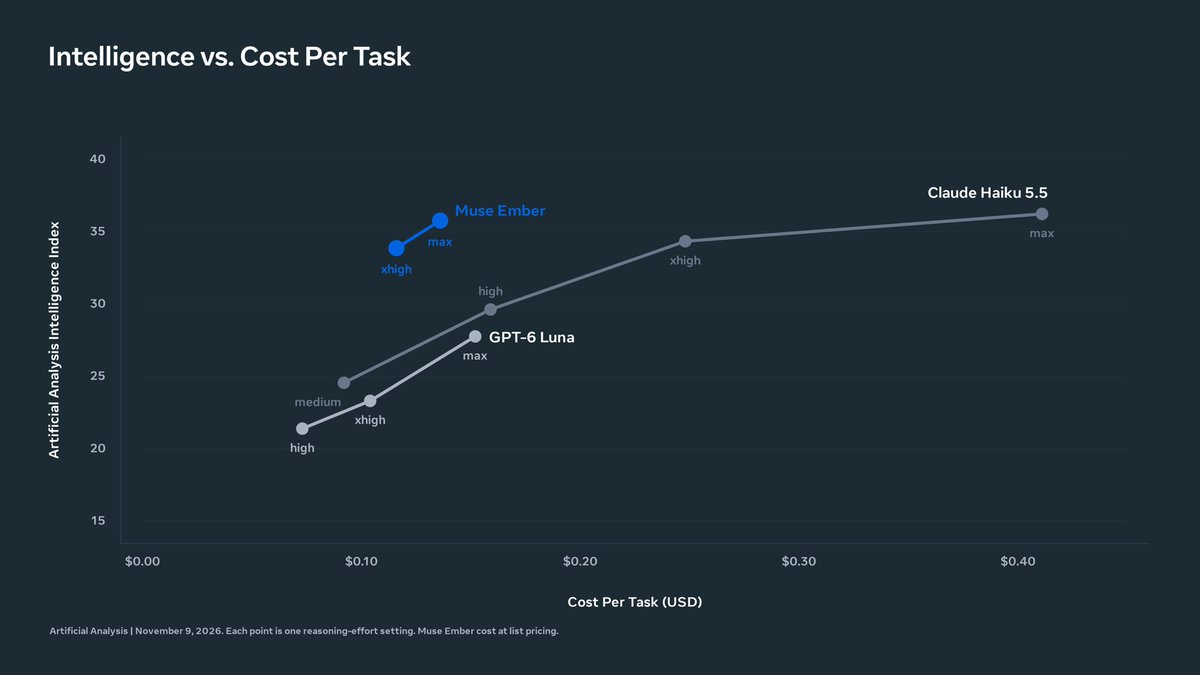
1/ announcing our smallest, most efficient little model is here: muse ember 🔥
built for work that agents repeat all day, it gets you more intelligence per dollar than Haiku, Luna, and all other flash models at any reasoning setting and does it at a third of the cost or less!
Our first version of Muse Ember 🔥
Ember aims to maximize intelligence per GW of inference to help bring personal superintelligence to everyone.
We would love all the feedback to keep hill-climbing. Please send it our way. We will keep hill-climbing on efficiency, user experience, and better approach to train with internal frontier!
More to come 🫡
Find it. Reach it. Grasp it. Easy for us, hard for a humanoid.
Introducing HuG (#CoRL2026): Learning Humanoid Whole-Body Affordance-Aware Grasping with Active Perception.
The robot looks around for a half-hidden object, squats or stretches its whole body to reach it, and grasps. Zero real demos, zero-shot to unseen objects and everyday scenes, from low tables to high shelves.
🌐 https://t.co/XQ8SDmZf97
Excited to share OpenRoboKit, our series of open-source robotics projects! 🤖
- RoboKit for fast, scalable optimization & simulation https://t.co/9KosQmzZP3
Our RoboKit paper has been accepted for a spotlight at #CORL2026
- RetargetingKit for motion transfer & teleoperation https://t.co/fniCD3Uhms
- GraspKit for end-to-end grasping https://t.co/Tikg9Fz94U
Website: https://t.co/fzDLfxoPh5
Check the video (sound on 🎵) for a 16-hour grasping time-lapse in beautiful San Diego, plus a quick look at dexterous retargeting and robot simulation.
1/ muse spark open is the most capable US open-weight model to date.
816B total params, 42B active. 1M-token context. natively multimodal. built for coding and agentic work like long-horizon tasks, hard software engineering, multi-step reasoning.
america! 🇺🇲
We're open-sourcing Muse Spark Open!
This is an important release which is the most capable US open-weight model yet. 🇺🇸
- 816B parameters (42B active)
- 1M token context window
- Built for coding and long-horizon agents
- Runs locally on two Apple M5 Ultra Mac Studios
More here: https://t.co/ylGmz7BNg0
Our G1 robot found its way to the pantry, picked up a Pringles can, and handed it over. No pre-built map. No training for this task.
Behind it is a coding agent, writing, running, and fixing the robot's programs as it goes. And it self-evolves: what works is saved as code for the next task, no retraining needed. This is ASENA.
Joint work with @Isabella__Liu, @edmund_bu, Johan Bjorck, @yin_hongxu, @zhengyiluo, @jankautz, @DrJimFan, @yukez, and @Sifei30488L. 🧵👇
Our G1 robot found its way to the pantry, picked up a Pringles can, and handed it over. No pre-built map. No training for this task.
Behind it is a coding agent, writing, running, and fixing the robot's programs as it goes. And it self-evolves: what works is saved as code for the next task, no retraining needed. This is ASENA.
Joint work with @Isabella__Liu, @edmund_bu, Johan Bjorck, @yin_hongxu, @zhengyiluo, @jankautz, @DrJimFan, @yukez, and @Sifei30488L. 🧵👇
Can we scale robot learning without scaling human labor? 📈
Demonstrations, resets, failure recovery, constant supervision—collecting robot data still takes substantial human effort.
🔑 Three keys let agents take on more of the work:
1. Real2Sim2Real: Agents explore and learn in digital twins, where trial and error is safer and cheaper.
2. Autonomous Recovery: Robots learn to recover from unexpected failures instead of waiting for human resets.
3. Human-on-Demand Learning: Multiple robots run in parallel, and humans step in only when autonomous recovery falls short.
🥑 Recova brings these together to get more robot learning out of every hour of human effort.
https://t.co/Wy7gucGq9r
Joint work with @anjjei, Johan Bjorck, @ZhidingYu, @yin_hongxu, @jankautz, @DrJimFan, @yukez, and @Sifei30488L.
👇 Here's how it works 🧵
introducing muse wonder
our new frontier model. state-of-the-art at personal agents and professional agents.
our largest and most capable model yet—rivals the big bois
🚨 side project alert 🚨
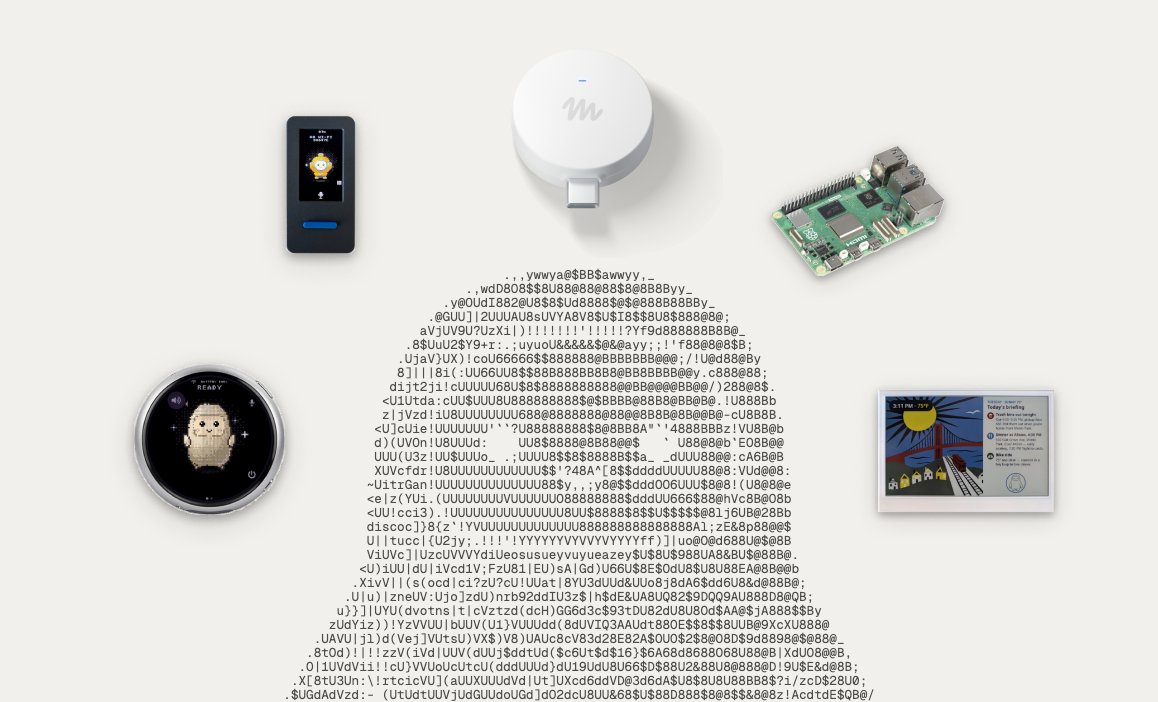
Announcing Muse Gadgets, an open source ESP32 firmware and Linux sdk so that you can make hardware devices that work with Muse.
Grab an API token from https://t.co/Q0dE0cYnCs and point your favorite coding agent at the github repo to build your own peripherals for Muse.
Today we give Atlas dexterous hands, with the strength to take on real work, and the simplicity for mass manufacturing. Like the body, the hands are designed with high fidelity simulation in mind, to enable sim-to-real RL. If you give dexterous hands to a robot, make them do dexterous things.
More thoughts here
Blog: https://t.co/z8xNB8KKXV
Video: https://t.co/iETKTwNIXn