📡 Beyond the Flat Seafloor: A Two-View Constraint for Sidescan Sonar Reconstruction – Kalin Norman
https://t.co/c0SRmyal1T
Thanks to everyone we met and spoke with! #MarineRobotics#Robotics
🌊 Coastal Environment Generation with HoloOcean – Abigail Austin
https://t.co/hihcMwLrfN
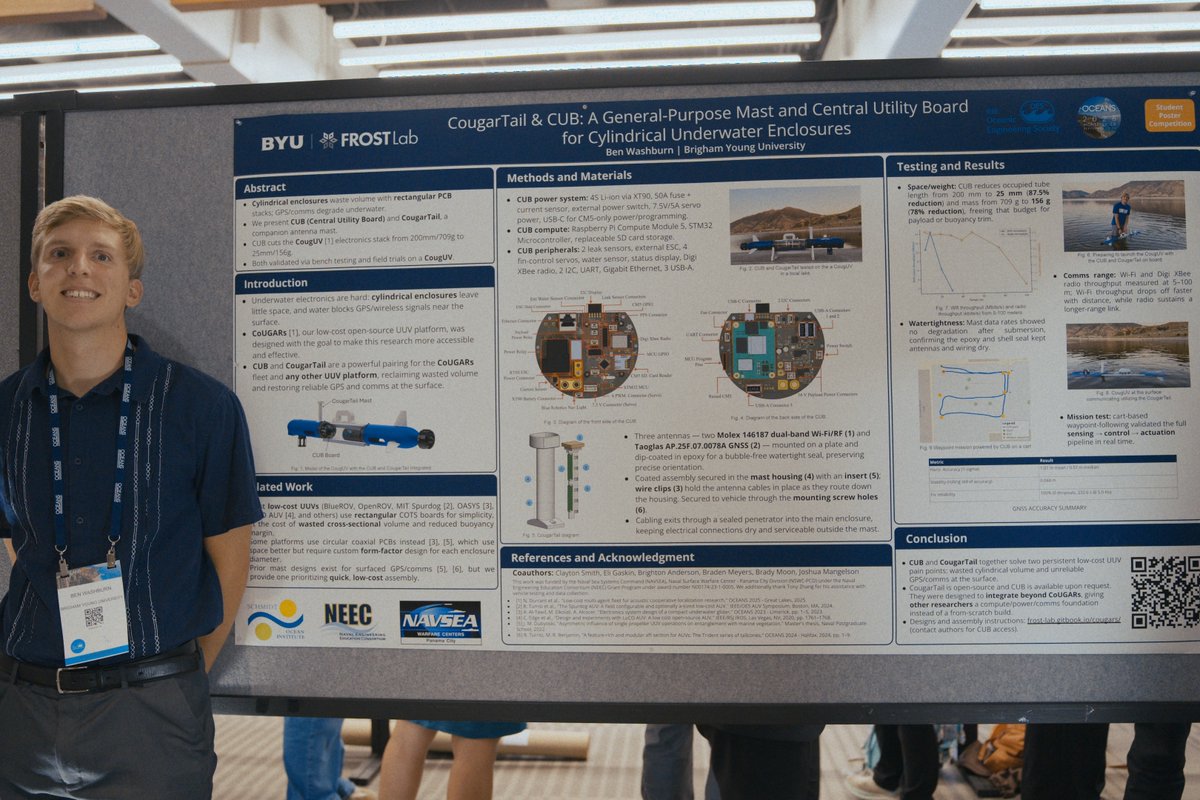
��� CougarTail & CUB: A Mast and Central Utility Board for Underwater Enclosures – Ben Washburn
https://t.co/fAp9cXjySC
🛠️ Our lab had a great time at #OCEANS2026!
A highlight: Josh Mangelson presented #HoloOcean, our in-house marine robotics simulator, in a discussion on the future of simulation for marine research.
We also presented five posters 🧵👇
Our lab was glad to be part of #IROS2026! 🤖🌊
We helped organize the AQ²UASIM workshop and the Workshop & Competition on Intelligent Information Gathering for Single and Multi-Robot Systems: 27 paper submissions combined. Thanks to everyone involved and to our sponsors!
At AQ²UASIM:
• Gabe Slade presented Derek Benham’s work on coastal LiDAR localization for surface vessels
• Sarahí Ortega presented Braden Meyers’ SNR-driven DVL beam dropout model + HoloOcean sonar improvements
• Carter Noh helped lead a panel on marine robotic simulators
🚀 New from the Frost Lab! Marine robotics sim is great for testing autonomy & perception — if you have environments to test in. We built an Unreal Engine 5 pipeline that auto-generates coastal environments for HoloOcean from overhead imagery. 🌊🛰️
📄 "CougarTail & CUB: A General-Purpose Mast and Central Utility Board for Cylindrical Underwater Enclosures"
Presenting at #OCEANS2026
✍️ Ben Washburn, Clayton Smith, Eli Gaskin, Brighton Anderson, Braden Meyers, Brady Moon, Josh Mangelson
🔗 https://t.co/fAp9cXjySC
🚀 New from the Frost Lab! Cylindrical UUV/ROV hulls waste space when electronics sit on rectangular PCBs. Enter CUB (circular Pi CM5 + STM32 board) and CougarTail (GPS/WiFi antenna mast) — cutting CougUV's electronics footprint 87.5% shorter, 78% lighter. 🌊🤖
We're grateful for the opportunity to share our field analysis of open-set, VLM-based 3D Scene Graphs for outdoor field robotics — evaluating these systems across diverse environments to identify their potential and remaining challenges for robust deployment.
📄 "A Distributed Consensus Particle Filter for Target Tracking using Autonomous Surface Vessels"
Carter Noh, Kyle Crandall, Connor Yates, Corbin Wilhelmi
🔗 https://t.co/7x75693rGy
#Robotics#MultiAgentSystems#MarineRobotics#AUV#USV
🚀 New paper accepted at #OCEANS2026! We built a distributed particle filter that helps multi-agent USV teams keep tracking targets even when they lose contact with each other — spreading out strategically to stay robust under spotty comms. Tested live on the water. 🌊
Our workshop, Intelligent Information Gathering for Single and Multi-Robot Systems, has been accepted to #IROS2026!
Join us in Pittsburgh for invited talks, paper submissions, and an Indoor Exploration Competition.
#Robotics#IIG
Excited to share that our lab at BYU has received support through the NVIDIA Academic Grant Program! This award will help advance our robotics research in multimodal information gathering. Thanks to NVIDIA AI for supporting our work!
#NVIDIAGrant#Robotics#AI@byuengineering
Workshop Contributions
- @JoshuaMangelson helped organize and run the Workshop on Field Robotics:
https://t.co/tHDuYrbeoD
- Kalin Norman helped organize and Josh Mangelson spoke at the workshop From Sea to Space: Advancing Perception in Harsh Domains:
https://t.co/DyKu6s0bWw
Great week for our Lab at #ICRA2026 in Vienna!
Presentations:
• Kalliyan Velasco: “Weighted Group-K Consistent Set Maximization for Outlier Rejection of Azimuth-Elevation Measurements”
• Chad Samuelson: “Terra: A Terrain-Aware 3D Scene Graph for Outdoor Mapping”