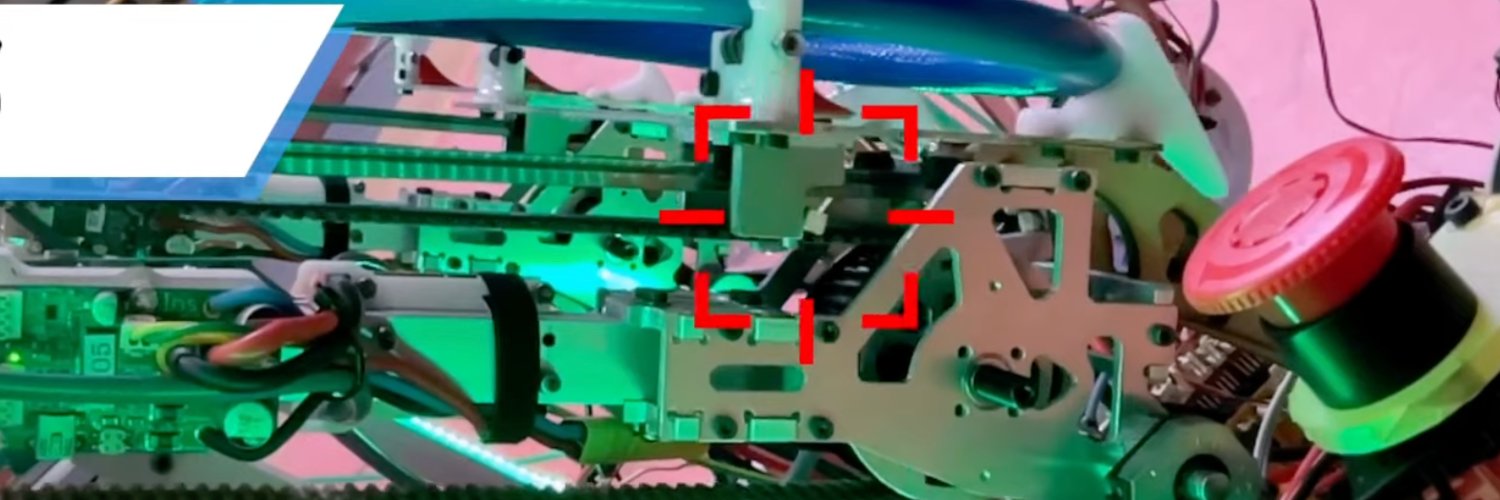
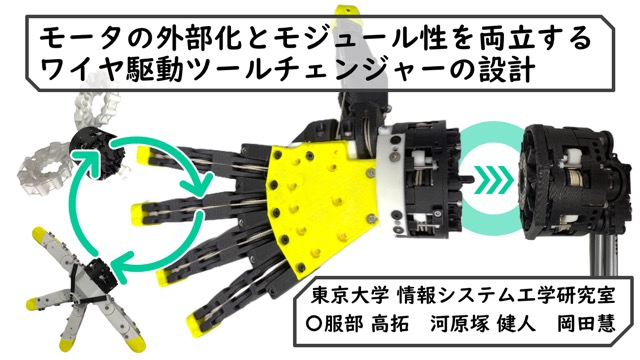
🎉Our new paper “Detachable Wire Drive: Reconfigurable Robot Architecture with Shared Actuators” is accepted to IROS2026!
This is a reconfigurable wire-driven robot system enabling actuator sharing across diverse morphologies!
https://t.co/wLTr9aSmJY
🎉 Our new paper, “A Morphing Aerial Robot With Thruster-Integrated Flexible Continuum Links for Shape Adaptive Aerial Manipulation,” has been accepted to #IROS2026!
Our novel aerial robot achieves versatile aerial manipulation via shape adaptability & expanded wrench space!
🎉 Our paper on a self-reconfigurable manipulator has been accepted to #IROS2026!
We developed an easy-to-operate, strong electromechanical docking mechanism that lets the robot dock/undock its own modules and reconfigure its body.
This work is based on my undergraduate thesis!
⚡️ High torque for acceleration, high speed after switching.
At #IROS2026, we’ll present trajectory optimization for humanoid motion exploiting our Variable Chain Motor, which switches its speed–torque characteristics on the fly.
🎉Our new paper, “Design of a Biomimetic Joint-Covering Skin with Tissue-Like Structure to Enhance Proprioception in a Musculoskeletal Humanoid,” has been accepted to #IROS2026!
Can a robot sense its posture through its skin?
We developed a tissue-structured joint-covering skin.
🎉Our new paper, “Robust Brachiation on a Life-Sized Dual-Arm Robot Using Waypoint-Guided Reinforcement Learning,” has been accepted to #IROS2026!
We propose WGRL and achieve robust brachiation, which requires precise hand movements and highly coordinated whole-body motion.
🚀 WARL (Wrench-Augmented Reinforcement Learning) has been accepted to IROS 2026!
Instead of exploring only in joint action space, WARL augments actions with virtual wrenches (forces & torques) to improve exploration during learning.
Check out the results below 👇
#IROS2026