Researchers ask what happens to SLAM algorithms during a snowfall. We argue that ❄️ snow gusts ❄️ cause safety concerns and are currently harder to investigate as they happen rarely in winter data sets.
@roboticscouncil@IID_ULaval#robotics#lidar#researchpaper#slam
this summer I decided to limit travel/meetings and had more time to think deeply and spend with my family. I also wrote a draft on how to use modern tools from statistics to get performance guarantees for outlier-robust perception in robotics & vision: https://t.co/E3VwKWhvxO
"Export considered harmful"
Because software rarely operate on "files in folders" anymore, "export" is increasingly the way software exposes data. But usually you don't want a dead snapshot; you want to "use this data elsewhere"—which requires repeatedly exporting & reconciling.
Going to start a thread of folks taking aim at the current scholarly publishing system and working for change. This is partly my attempt to find more of my friends. Let's work together! #openscience#AcademicTwitter
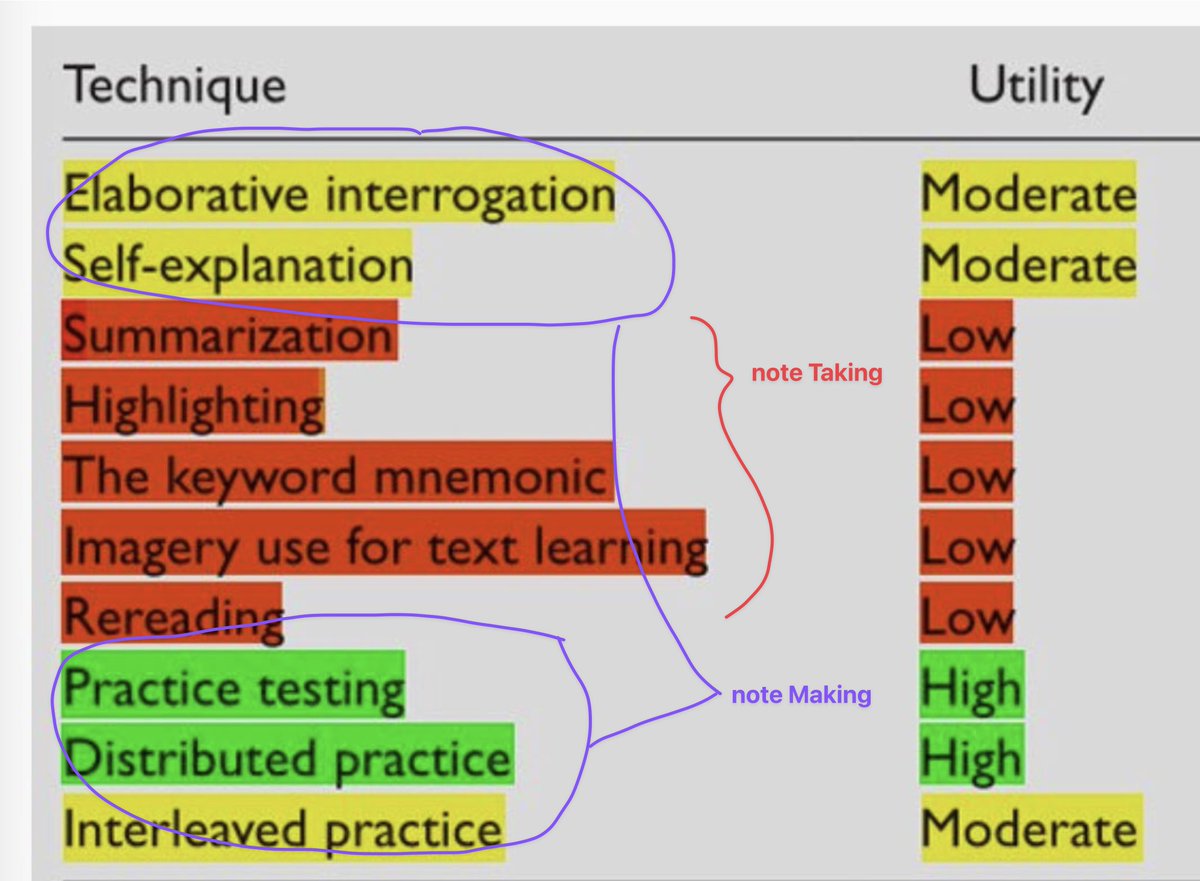
Hypothesis:
The red zone is for "note-taking" (as traditionally understood) - not particularly useful for learning and application
The yellow to green zone is for "note-making" (per @NickMilo / #zettelkasten) - it's how you construct knowledge to be deeply and flexibly applied
Hydra is now open source:
Code: https://t.co/miYkDEHYH0
Video: https://t.co/gDVFk0wU86
Paper: https://t.co/hjZBkN7vSo
#hydra is a real-time system to build 3D scene graphs from sensor data. It will be presented this week at #RSS2022#mitsparklab#robotPerception#mapping
Uncertainties are everywhere in robotics and are fundamental for probabilistic methods such as factor graphs. However, frames, conventions, and other concepts can make things confusing. I wrote 3 posts for https://t.co/TBnOuCMIOx invited by @fdellaert to explain this.
Excited to share our work https://t.co/vRRxh93odP at #CoRL2021 on learning observation models end-to-end in factor graphs! We show that learning observation models can be viewed as shaping energy functions that graph optimizers, even non-differentiable ones, optimize.🧵
1/
Come and learn about state estimation, matrix Lie groups and exponential coordinates for robotics, and perception in Mobile Robotics as I teach in Winter 2022.
All notes and files on Github: https://t.co/QfyZODj5IP
Lectures on YouTube: https://t.co/ktRj2gWkRQ
(1/6)
How can we learn to iteratively reason about the problems in the world? In our #ICML2022 paper, we introduce an approach towards iterative reasoning based off energy minimization :
Website: https://t.co/bnQTESGufy
w/ @ShuangL13799063 Josh Tenenbaum @IMordatch
@houshuang I thought this as another abstraction layer on top of Roam, serve as a foundation interface for light-weight plugins which are just choosing frontend view of our own data.
Calling all #roamcult!
Introducing: THE ROAMAN AGORA.
A place to gather, present, and discuss the Roam Games.
Find it hard to follow the #RoamGames? → Join the Agora.
Want to spread the word about your project → Join the Agora.
Want to find collaborators? → Join the Agora.