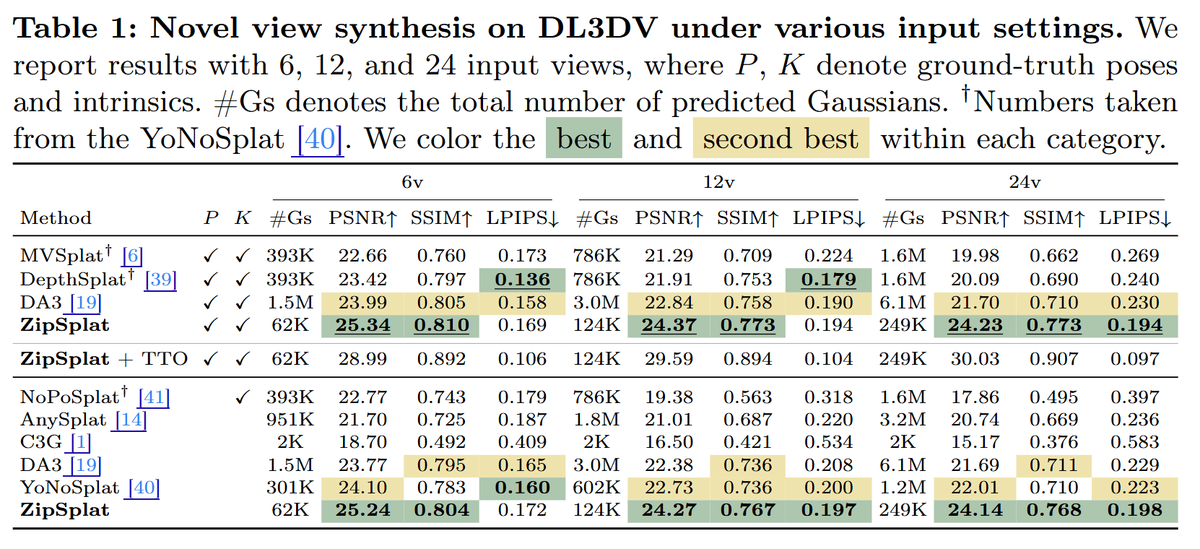
ZipSplat: Fewer Gaussians, Better Splats
@veichta, Sunghwan Hong, @majti89, @mapo1
tl;dr: predict Gaussians directly in 3D from a compact set of scene tokens->decouple primitive placement from the 2D pixel grid
https://t.co/LThIjljuUb
Today afternoon @CVPR: 𝐅𝐮𝐧𝐑𝐞𝐜 [Poster 654] 🌴
➡️Input: Egocentric interaction Video 👷♀️
⬅️Output: Functional 4D Reconstruction 🏡
-- come say hi at the poster! 🚀
/w @AlexDelitzas@mapo1@majti89@Stanford@ETH
@meta_aria This is very cool work! It’s a more unscripted version of what we did with HoloAssist (https://t.co/cVd4Fp9W65). I think these type of datasets are very valuable given the rich and purposeful interactions they capture.
Introducing EgoVerse: an ecosystem for robot learning from egocentric human data.
Built and tested by 4 research labs + 3 industry partners, EgoVerse enables both science and scaling
1300+ hrs, 240 scenes, 2000+ tasks, and growing
Dataset design, findings, and ecosystem 🧵
What a fantastic week at #CoRL2025 in Seoul! It was a pleasure for us on the 🇨🇭Zurich @Microsoft team to finally meet in person the colleagues we collaborate with from our global 🌍 AI teams in Tokyo, Cambridge, Redmond, Beijing and Seoul!
Welcome, @oier_mees ! It's been great to have you join our team.
If you too are excited about this topic, consider joining us! We have open positions for full-time and interns.
After two fantastic years at @UCBerkeley I'm thrilled to share that I've joined @Microsoft in Zurich🇨🇭to pioneer the next generation of multimodal foundation models to drive agents 🤖 that can seamlessly interact across the digital and physical worlds 🌍
We are hiring! 🧵
After two fantastic years at @UCBerkeley I'm thrilled to share that I've joined @Microsoft in Zurich🇨🇭to pioneer the next generation of multimodal foundation models to drive agents 🤖 that can seamlessly interact across the digital and physical worlds 🌍
We are hiring! 🧵
You're in Zurich or its zone of influence (Lausanne, Paris, BXL, Munich, London, ...) and like AI + Robots?
We (@openai) together with @mimicrobotics, @lokirobotics, and Zurich Builds are organizing a hackathon from Fri 9 May afternoon to Sun 11.
Limited spots, more below:
📢 Today, we release LabelMaker, a fully automatic tool to create semantic annotations for indoor scenes. LabelMaker will be presented as spotlight at #3DV2024 in March.
🔗 https://t.co/rWL0i7IseX
🛠️ https://t.co/STmXPfTYrv
with @hermannsblum , @FrancisEngelman , and @mapo1
I am overjoyed to announce I am hosting the "Workshop on Urban Scene Modeling" along with an amazing team at @CVPR 2024!
Submission deadline March 24
https://t.co/PAIUvL8ZyB
more two challenges, brand new dataset, and amazing keynote speakers soon...!
#CVPR2024#usm3d #usm3d2024
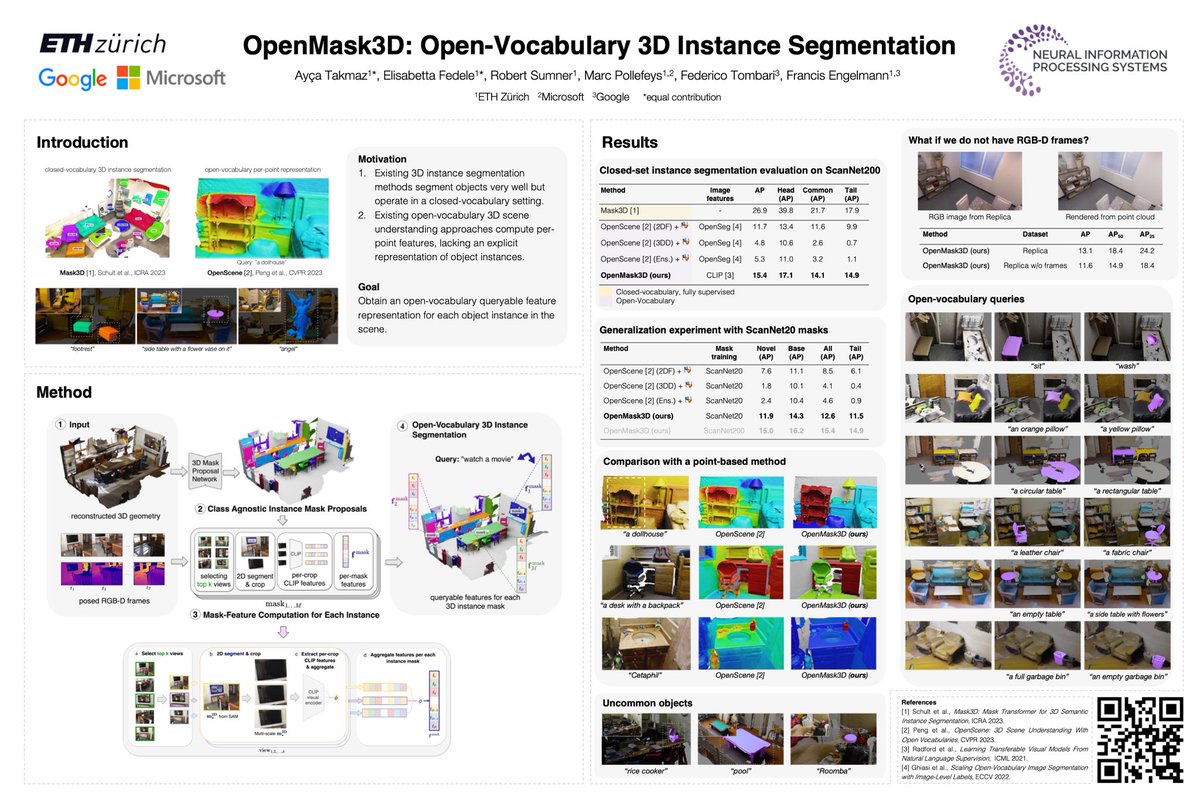
Today @aycatakmaz and I will present our paper OpenMask3D at @NeurIPSConf 🎷🚀
Come by to learn more about the project or to chat about related topics!
📍 Great Hall & Hall B1+B2 (level 1) #906
🕰️ 10:45-12:45
🌎 https://t.co/0JXLoAC4UV
@FrancisEngelman@fedassa@mapo1
Today @efedele16 and I will present our work OpenMask3D at @NeurIPSConf 🎷
Visit our poster to learn more about OpenMask3D or to chat with us!
📍 Great Hall & Hall B1+B2 (level 1) #906
🕰️ 10:45-12:45
🌎 https://t.co/FZr0it4NPs
@FrancisEngelman@fedassa@mapo1