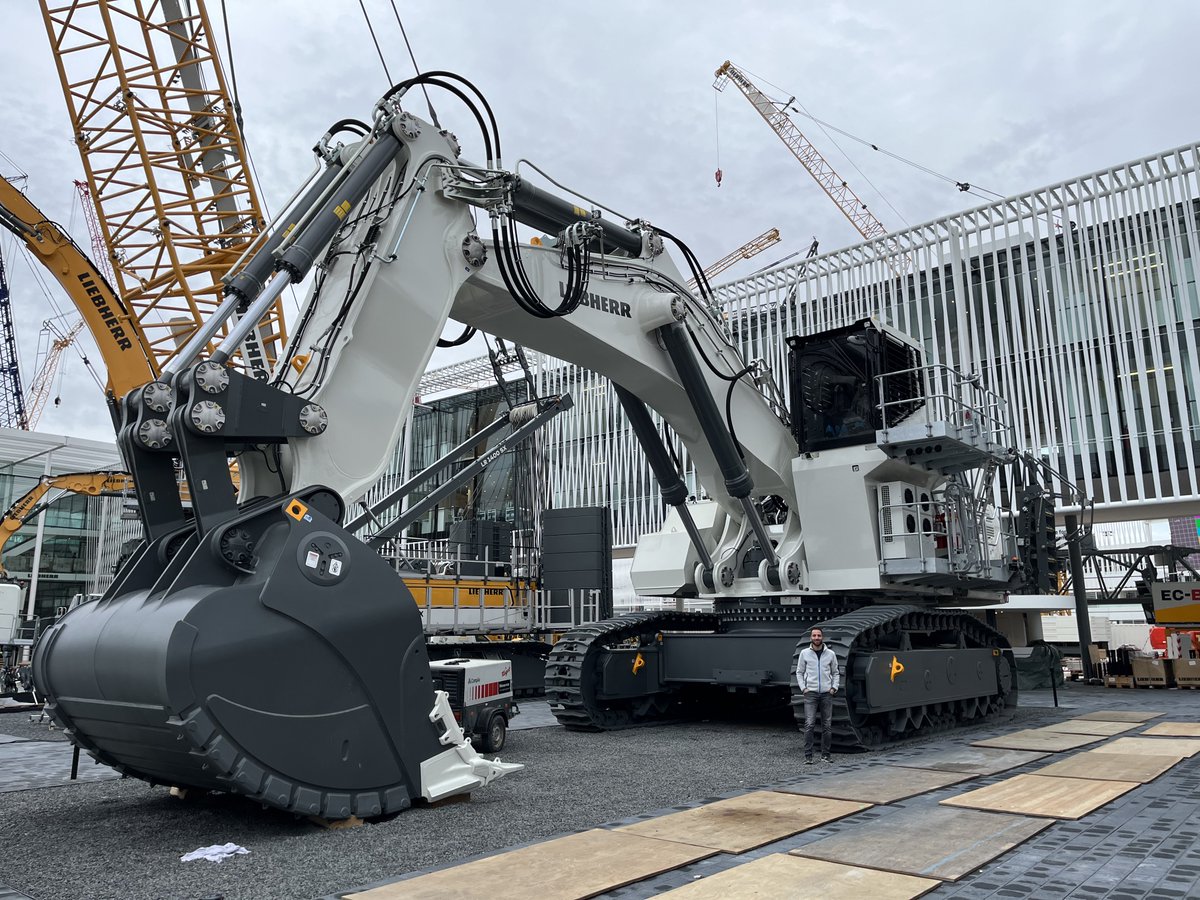
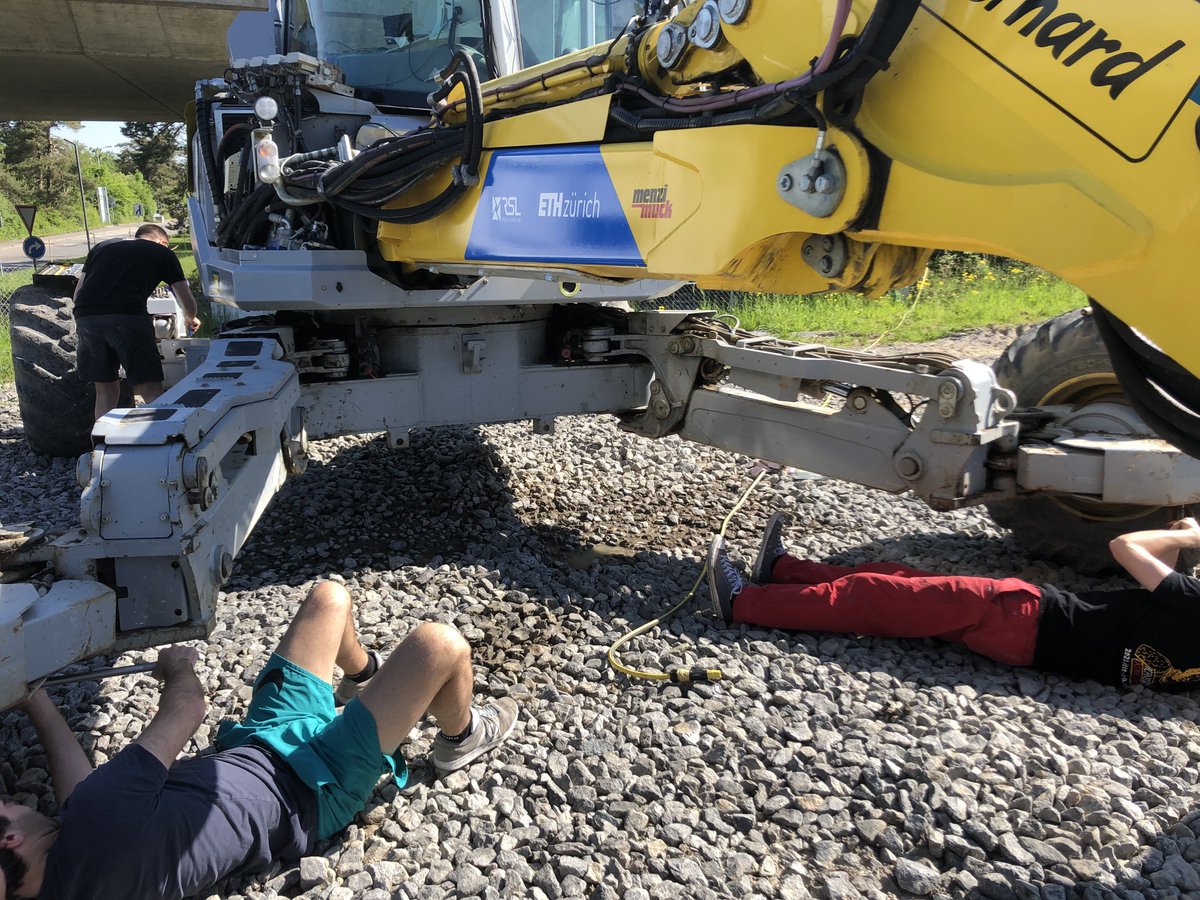
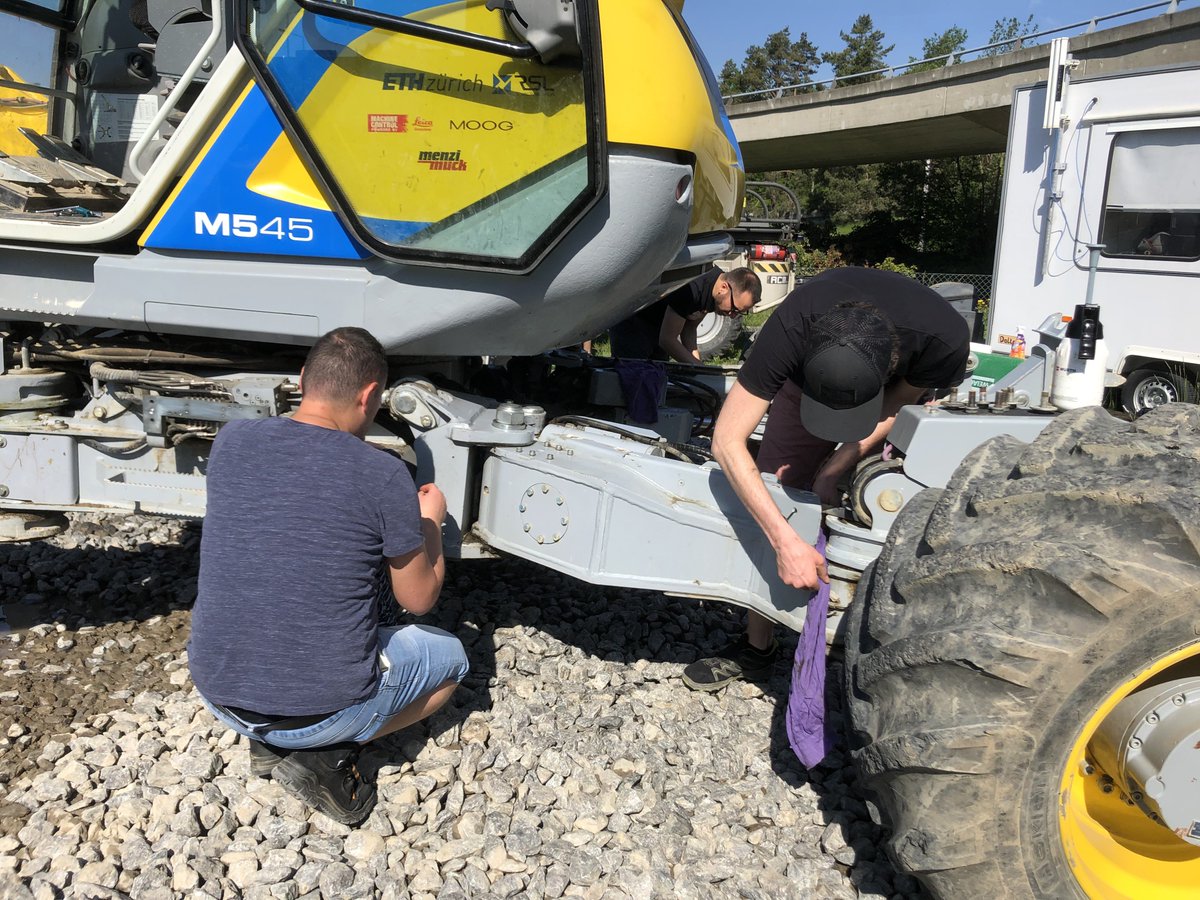
An autonomous 12-ton #Robot can build stable, dry stone walls and develop a 3D repository of objects used, making it easier to recycle materials if the original wall is no longer needed. @leggedrobotics@ETH_en
Learn more in Science #Robotics: https://t.co/VM89eJlwDv
We are looking for a skilled, passionate DevOps engineer to join our team at @GravisRobotics and push the development of our autonomous heavy construction machines.
#devops#devopsengineer#robotics#hiring
https://t.co/fwxTGiZCCI
I'm excited to share that a new adventure has started! With over a decade of experience in construction robotics, with a few colleagues from @leggedrobotics, we created @GravisRobotics to develop the world’s most advanced robotic excavators!
https://t.co/mmhanRYdIm
Our paper on how Team CERBERUS won the @DARPA Subterranean Challenge and the lessons learned is now accessible via https://t.co/QM08AM9NFr! Code+data at https://t.co/18U136AGhq - https://t.co/tP701kqzYB #SubTChallenge@arlteam@leggedrobotics@ASL_ETHZ@dynamicrobots @fly_ability
Talks from the 6th workshop on legged robots at #ICRA2022 are online.
I gave a talk on team @CerberusSubt approach for the DARA SubT Challenge Finals.
https://t.co/TDZVhqS71m
I'm thrilled to announce that @SciRobotics published our article about the winning run of Team @CerberusSubt in the DARPA Subterranean Challenge finals!
If you would like to do a PhD in the domain of autonomous aerial #robotics for digital forestry and accordingly support efficiency and the protection of our environment consider applying to this new position in our lab! https://t.co/MOrw2ilpME
We open source our fast GPU based elevation mapping software!
This includes features like traversability estimation and inpainting which are useful for navigation and legged locomotion.
It was used during the DARPA SubT Challenge by team @CerberusSubt.
https://t.co/pck5RSZrJz