📢 New paper out!
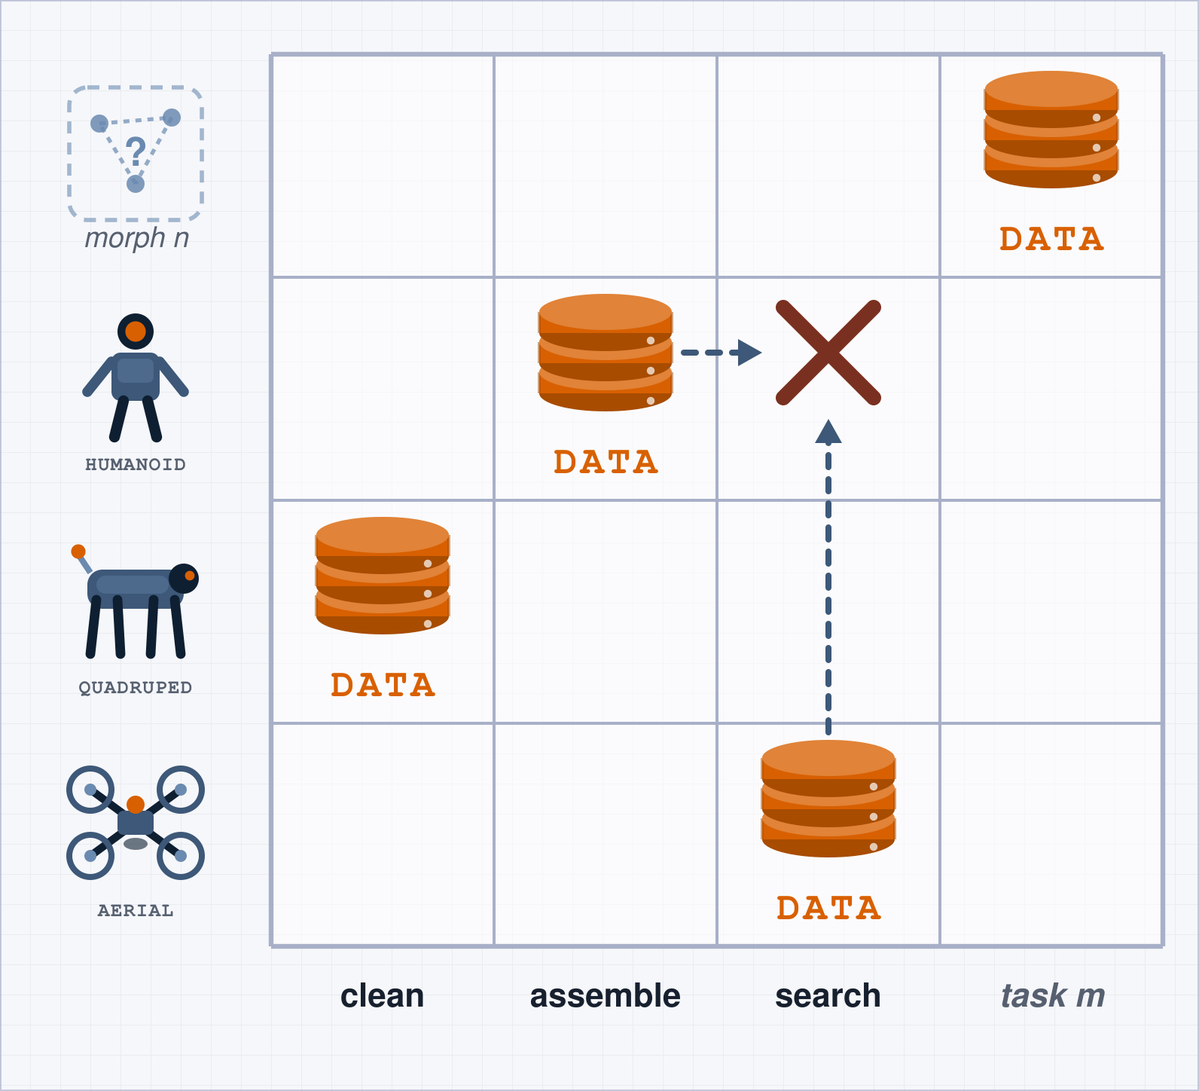
We introduce QWM: a single locomotion world model trained across 8 quadrupeds and deployed zero-shot on robots it had never seen by conditioning on their morphology specs: ANYmal-D and Unitree Go1 🦾
No fine-tuning, no warm-up, no retraining from scratch.
The key insight: robot morphology isn't a latent variable to infer from motion history, it's a known engineering spec sitting in the USD (or URDF) file. So we just use it directly.
What if one world model could control many different robots? 🤖🌍
That's QWM.
In this 2 minutes video we show keypoints about QWM: learning across heterogeneous quadrupeds, and transferring zero-shot to unseen morphologies.
No fine-tuning. No warm-up. No retraining.
Let's talk it further at CoRL 🥳
I am a day behind because #CoRL2026 is so exciting, but I ranked the 687 CoRL 2026 papers against my group's research and kept a prioritized reading list of 101 on RL fine-tuning, world models, VLAs, and learning from human video.
1/ What does a more open robotics ecosystem look like?
In their @corl_conf keynote, @micoolcho@DJiafei will share how open-source data, accessible hardware, and real-world evaluation can advance robotics research.
Catch the session at the Hilton Austin on Nov 9, 4:40 PM.
We've been using DexSuite internally in our lab for the past few months and nothing comes close to it!
The simplicity of combining different arms and hands, designing new tasks with realistic physics and visuals, and the speed makes it truly practical.
Highly recommended 🦾
Dexterous manipulation deserves better tools 🖐️
Excited to share DexSuite: an all-in-one, open-source simulation framework for dexterous manipulation, built on Genesis 🚀
Nobody said research paper videos need to be boring...
(put volume up)
🌐 https://t.co/v0bLv8yYtQ
I am writing an open textbook on robot learning; the first two draft chapters are online. Chapter 1: What robot learning is and how to make control less brittle. 2: Imitation learning, from ALVINN to today's VLA models, and why behaviour cloning is like walking a tightrope.
📢 New paper out!
We introduce QWM: a single locomotion world model trained across 8 quadrupeds and deployed zero-shot on robots it had never seen by conditioning on their morphology specs: ANYmal-D and Unitree Go1 🦾
No fine-tuning, no warm-up, no retraining from scratch.
The key insight: robot morphology isn't a latent variable to infer from motion history, it's a known engineering spec sitting in the USD (or URDF) file. So we just use it directly.
my co-first author at NeurIPS didn't get the invitation from the waitlist to register meaning he can't attend a conference he has a paper in. wondering who got it.
i thought the whole point of having 3 locations was to accommodate everyone. apparently publishing a paper doesn't guarantee you can actually attend your own conference.
really frustrating and ridiculous!
🎉 The CoRL 2026 accepted papers are out!
📄 687 papers
🎤 21 orals
✨ 72 spotlights
See you in Austin, Nov 9–11. Congrats to all authors 👏
https://t.co/LkzwCR7Pwh
#CoRL2026
In our latest work at @corl_conf, we introduce Quadrupedal World Model: a single morphology-conditioned dynamics model, where policies are trained entirely in imagination.
We found generalization emerges by conditioning the dynamics, not the policy.
🔗https://t.co/6Ptc7z7LQP
🌐Does modeling dynamics provide a better path to generalization than learning model-free policies alone?
🐕In QWM @corl_conf, a morphology-conditioned world model learns shared locomotion dynamics and enables zero-shot transfer to unseen morphologies.
🔗https://t.co/Q7ShO40wBz
What if one world model could control many different robots? 🤖🌍
That's QWM.
In this 2 minutes video we show keypoints about QWM: learning across heterogeneous quadrupeds, and transferring zero-shot to unseen morphologies.
No fine-tuning. No warm-up. No retraining.
Let's talk it further at CoRL 🥳