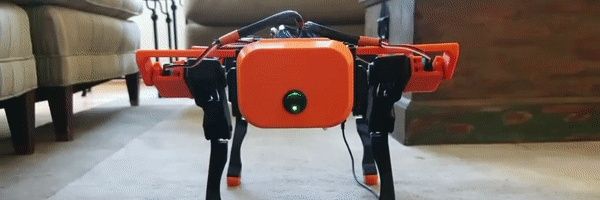
Super fun and accessible project! Check out the custom Pybullet Env (Gazebo coming soon) or learn how to build your own Spot for an affordable price! Stay tuned for real-world validation of our novel RL method for locomotion!
Excited to share "Spot Mini Mini", an open source Boston Dynamics inspired Spot robot for <$600 done by my student Maurice @NorthwesternU Robotics! We also develop RL wrapped IK with 12pt Bezier gait! Check out blog post+repo:
https://t.co/1WFCsSo5na
https://t.co/OTP9wcbk78
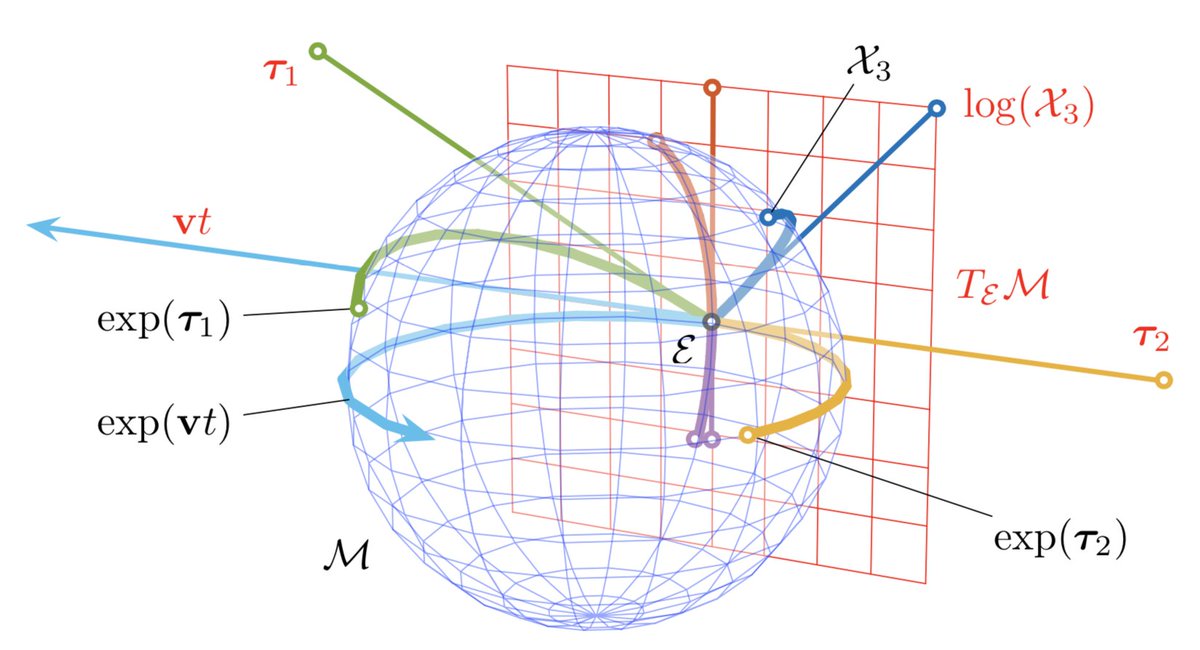
Ever wonder how rotation matrices, axis/angle vectors, and quaternions are really related? The exponential and logarithmic maps allow us to translate between representations—and even average rotations.
Learn how, interactively: https://t.co/Bwx2KKHuys
Here's a typical drive on Tesla FSD Beta, and why it's the opposite of useful. It's most certainly not even close to being "safer than a human", by any factor.
22-minute drive, 4.5 miles, and WAY too many interventions.
This summer I've been working to finally understand Lie Theory, the basis for proper estimation on over-parameterised manifolds like SE(3). There are some great tutorials for the roboticist out there; I especially like Micro Lie Theory by Solà et al. https://t.co/0j7fS4gAGL
Parkour is the perfect sandbox for the Atlas team to experiment with new behaviors. Through jumps, balance beams, and vaults, we push Atlas to its limits to discover the next generation of mobility, perception, and athletic intelligence. https://t.co/xZRNVnhrkc
🎉Life update🤘: Really excited to share that I'll be joining @YaleSEAS as an Assistant Professor in Mech. Eng. starting in Jan 22'!
My lab will focus on developing algorithms at the intersection of robotic learning and control with an emphasis on active learning.
Our paper "Whole-Body MPC and Online Gait Sequence Generation for Wheeled-Legged Robots" is accepted for #IROS2021 in #Prague!
Check out the full video: https://t.co/tSkjVEb8u1
#Robotics#Robots
Super excited to share my first PhD paper "Move Beyond Trajectories: Distribution Space Coupling for Crowd Navigation" at @RoboticsSciSys with Francesca Baldini, @PeteTrautman and @todd_murphey !
PDF: https://t.co/0z8ba3GdNc
Video: https://t.co/T5IddxzJez
ICYMI, #ROSWorld presentations have been uploaded. If you missed my technical session you can watch the full video here: https://t.co/2zFWoyqtbT . Thanks to @OpenRoboticsOrg for this great opportunity to share my work to the community.
Check out this very cool project developed by Marcel Bonnici—a member of our Master of Science in Robotics cohort—on fast food automation using LEGO bricks. https://t.co/NrkPBLcQQ2
@faraz_r_khan My go-to is https://t.co/6mIsNcD5MC it's browser based and super simple and intuitive to use. Pretty sure the schematic side of things is based on LTSpice, which I love!
"Dynamics and Domain Randomized Gait Modulation with Bezier Curves for Sim-to-Real Legged Locomotion" paper out in arxiv!
https://t.co/Wa2QU9W58K
Thanks @sim2realAIorg for RT!
Authors: @moribots, myself, Matt, @todd_murphey
Recorded Turing Lecture: Building dynamic robots with @BostonDynamics Marc Raibert is now up. Thanks Prof @sethuvij for hosting this. Full video here: https://t.co/XEnrh48g7U