With @JayHe748646@KehanWen170077@leggedrobotics , we push humanoid mobility to next frontier.
Achieved by a generalist contact planner + a generalist tracker + a generalized neural mapping, warmstarted from few human data.
Website: https://t.co/Y7cu3D4K4I
Promo Video 👇
Incredibly excited to return to ETH Zurich as Assistant Professor of Robotics and Artificial Intelligence next summer. I'll be recruiting PhD students to build a new lab on general-purpose embodied intelligence for humanoid robots and dexterous manipulation. Details coming soon!
We are releasing a dataset with human motions together with terrain reference collected both indoors and outdoors.
Now, contact signals can be extracted to help with learning terrain interactions.
Presenting in Nov 2026 @corl_conf!
Try out EgoHTR now!
🔗 https://t.co/GyjTrfbECC
We are releasing EgoHTR, a dataset with both human motions and terrain references, accepted @corl_conf.
📖 Paper: https://t.co/LHEQpqFrXG
🌐 Project Page: https://t.co/x12lTzVTDf
• 55 scene-aligned sequences • 150k+ frames • rough-terrain environments • multi-modal 3D scene
VLAs have become the fastest-growing subfield in robot learning. So where are we now?
After reviewing ICLR 2026 submissions and conversations at CoRL, I wrote an overview of the current state of VLA research with some personal takes:
https://t.co/OMMdB1MHtS
We're excited to share that five papers from AirLab 🚀have been accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025!
Papers are on the thread:
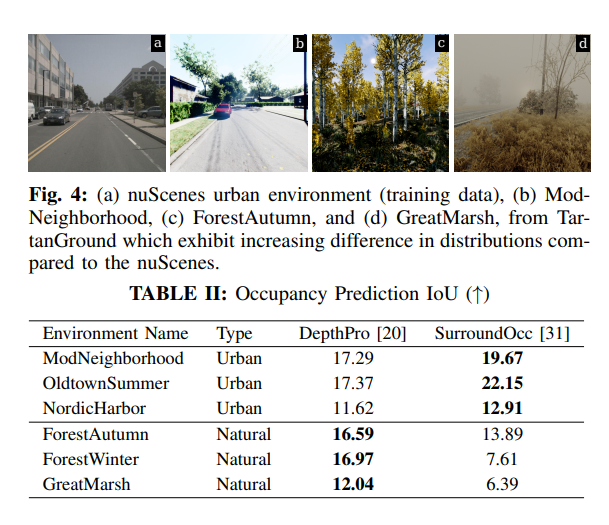
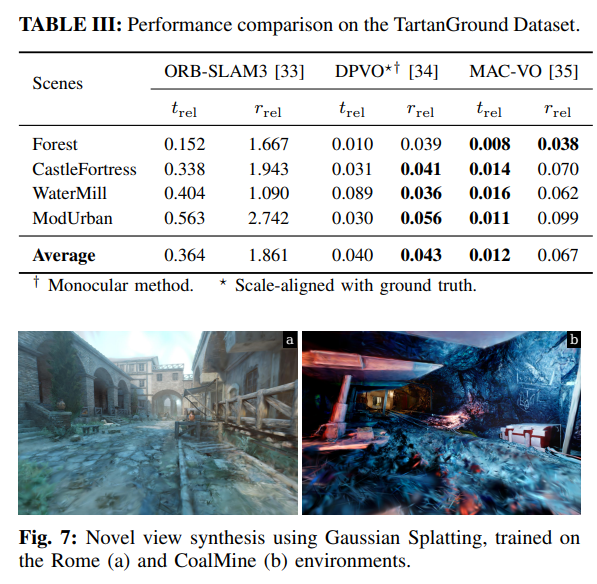
TartanGround: A Large-Scale Dataset for Ground Robot Perception and Navigation
@Manthan90921929, Fan Yang, @QiuYuhengQiu, Cesar Cadena, @smash0190, Marco Hutter, Wenshan Wang
tl;dr: 910 trajectories, 70 environments, 1.5 million samples, wheeled&legged robots
https://t.co/ca9TiflgfY
New research: Quadruped robots climbing ladders! 🦾🚀 Using RL-based control and a hooked end-effector, we're expanding robot capabilities in industrial environments. More info in the paper: https://t.co/Urv9pGLPib
Video: https://t.co/FxPs6OnKwx
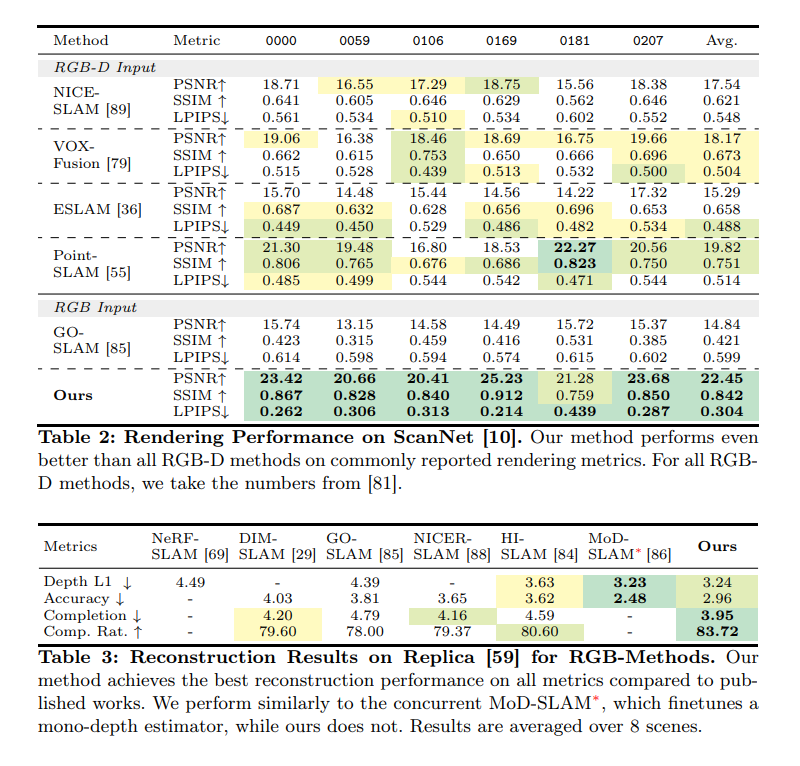
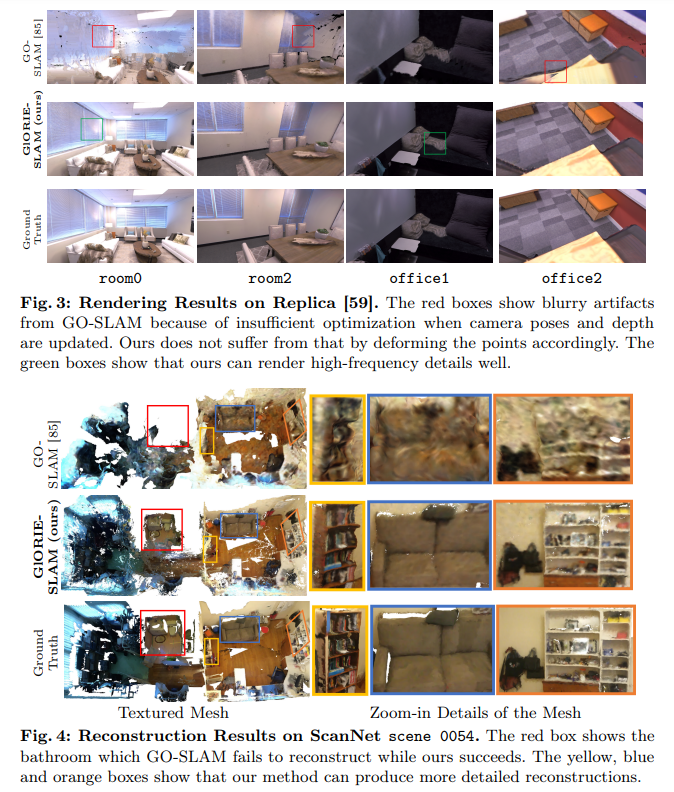
GlORIE-SLAM: Globally Optimized RGB-only Implicit Encoding Point Cloud SLAM
Ganlin Zhang, Erik Sandström, Youmin Zhang, Manthan Patel, Luc Van Gool, @Martin_R_Oswald
tl;dr: neural point cloud scene representation->RGB-only SLAM
https://t.co/RIcxev3s4G
Checkout our latest work on Collaborative SLAM which makes it possible to use any VIO front-end of your choice.
If you are at #icra2023 feel free to drop by at our poster on Tuesday, May 30th
Collaborative SLAM with different VIOs? Check out COVINS-G ti be presented at #icra2023 next week: Localization and Mapping 1 | 08:30-10:10 | Tue 30 May | Poster pod 56.
Video: https://t.co/eh3Lt5myl4
Paper: https://t.co/33cYFqcEbE
Code: https://t.co/3Yocia9Jfb
@Manthan90921929