Notice how the blog doesn't mention success rate anymore -> that's just the minimum bar for real-world deployment. What we talk about instead is "Throughput" and "Quality". We've pushed VLAs to deployment limits since Dyna-1, which is exactly why we get to weigh in on VLA vs. WAM with production data, not opinions.
After so many demos, models, pilots, robots are still struggling to land real deployments with real customers. Until now.
Today we’re excited to share that our robots have successfully crossed the ROI threshold, and Din Tai Fung, one of the highest revenue per location restaurant chain in the US, is rolling out Dyna robots across its extensive restaurant network.
This brings our rollouts across hotels, logistics, data centers, and many other use cases to a fleet that reaches hundreds of robots by the first half of 2027. And we’re just getting started.
It’s been a wild year, and today we’re double clicking on the battlefield stories and sharing a few learnings about scaling robot deployments. We are just scratching the surface.
Read the full blog post: https://t.co/8QVEoQuzBY
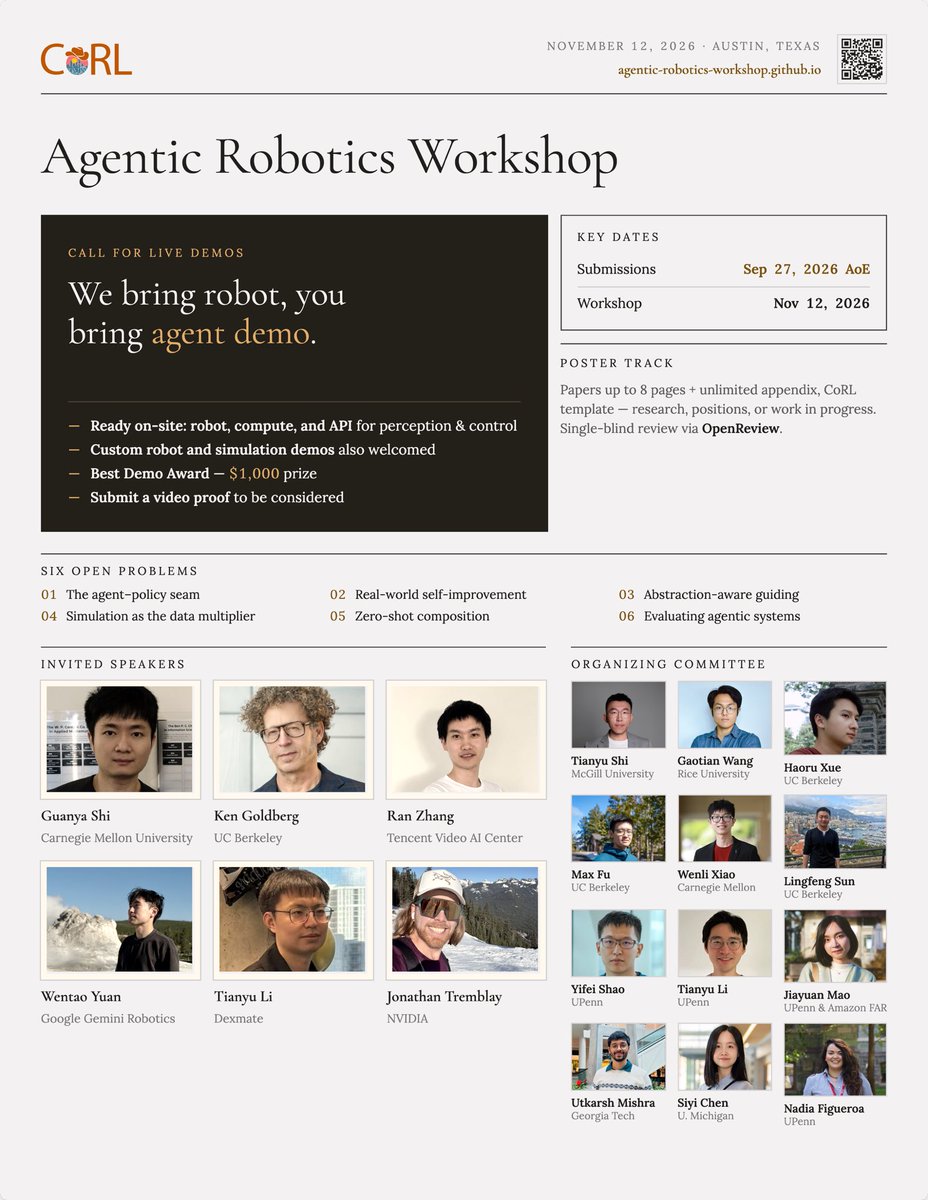
Our workshop focuses heavily on live demos. You bring your agents and we bring robots for you. This will be a playground for agentic robots! Come join us!
🚨 Call for live demo / paper at CoRL 2026 𝗔𝗴𝗲𝗻𝘁𝗶𝗰 𝗥𝗼𝗯𝗼𝘁𝗶𝗰𝘀 𝗪𝗼𝗿𝗸𝘀𝗵𝗼𝗽! No paper required for demo track. Due Sep 27.
🔮 The real magical power of agent is live interactive demo with the audience, which is why we provide all-out support:
- Robot, compute, and API are ready for you in the conference room
- Custom robot / sim demo also welcomed
- Just submit a video proof - friendly to industrial participants
https://t.co/F2L9Q05PAK
Paper submission also welcomed!
We also have an amazing speaker lineup from CMU, UC Berkeley, DeepMind, NVIDIA, and Tencent.
I will be at #Actuate26 giving a talk on the model and infrastructure behind dyna-2. Excited to chat with everyone about scaling robot foundation models and deploying them in the real world! Please reach out if you'd like to chat!
Anyone who’s worked in robotics will agree infrastructure is what enables research and deployment. It’s the true cornerstone. I’m glad that at Dyna, we put infrastructure in the spotlight, and we appreciate the people who build it!!
When people talk about robotics, they usually talk about models, data, or hardware. Few people talk about the infrastructure that lets you iterate on all three quickly. Today we're publishing how we trained Dyna-2 on over 1,000,000 hours of egocentric video, repeatably. At this scale, most of what worked at ten thousand hours did not hold up:
• ingestion throughput was capped at 14,000 episode-hours per week — a million hours would have taken over a year
• building a training manifest took 48 hours before a run could even start
• reading a petabyte from cloud storage during training left GPUs exposed to latency and packet loss
🧵
Pretty excited to have shown Dyna-2 on the WUJI2 hands! The egocentric human-video pretraining results transfer well to dex hands, with a big boost to post-training data efficiency. This is just the beginning. Dyna-2 is in "good hands" now. Who's excited for more? 👀👀
P.S. I believe this is the first time a policy running on WUJI2 has been shown publicly.
Today we are introducing Dyna-2, a world-action model pre-trained on one million hours of human video. At this scale, for the first time, we discovered several new scaling laws:
• world-action models exhibit scaling law on human data across four orders of magnitude, from 1000 to 1,000,000 hours,
• this human data scaling law implied a scaling law on never seen robot data,
• both data and objective matter; world modeling and scaling on video data are essential for cross-embodiment scaling transfer to emerge
🧵
The wildest results we got was when Tianyu got Dyna-2 working immediately on a brand new dex hand with 13minute of data! The 1M pretraining is crazy 🤯🤯
Call for community effort 🤖! Bring the Lobster 🦞 on robots! Our work Tidybot Universe 🌟, allows AI agents to autonomously iterate on real robotics hardware.
We built the infrastructure for displaying and sharing the learned skills across agents; and for hosting common services to be access across agents, starting with the Tidybot.
Join us today https://t.co/McPAyTLNWw
🛠️ VLMgineer has been accepted to #ICLR2026!
When paired with evolutionary search, VLMs show remarkable ability to design and reason in the physical world. Excited to see what they invent next 👀
Introducing Muscle v0 -- infinite degrees of freedom, from @DaxoRobotics. A different mountain to climb - with a far more beautiful peak.
We built this from the ground up:
- Ultra-dexterous
- Built for machine learning
- Durable and robust
More below (1/n)
I will be presenting this work at the RSS Workshop on Robot Hardware-Aware Intelligence on Wednesday, 06/25. (Location: EEB 248)
The spotlight talk is happening in the session 3:30PM-4:00PM.
The poster session will be 10:30AM-11:00AM and 4:00PM-4:45PM.
Come chat with us!
💡Can robots autonomously design their own tools and figure out how to use them?
We present VLMgineer 🛠️, a framework that leverages Vision Language Models with Evolutionary Search to automatically generate and refine physical tool designs alongside corresponding robot action plans.
✨ VLMgineer can fully automate tool and action design with AI-driven physical creativity. No human intervention. No pre-defined templates or few-shot examples.
✨ VLMgineer outperforms human-specified designs and existing everyday tools.
✨ We let the VLM fully decide how to evolve designs.
Deep dive with me: 🧵