🌏 World models need to capture a scene’s hidden physics properties, e.g., mass or friction, to generate predictions consistent with physical reality.
🚀 Excited to introduce PhysiCalWorld: In-Context Physics Calibration for World Models! We calibrate world models through an interaction clip, grounding future predictions in scene-specific dynamics.
🏷️ Supervision: trained without physics labels
⚡ Efficiency: minimal additional inference cost
⚛️ Generalization: extrapolation beyond the physics ranges seen during training
https://t.co/k9PRgg7qmR
More below 🧵
Robotic foundation models need memory, but existing methods still fall short
We’ll present RoboMME, a challenge organized w/ @YinpeiD, @jed_yang, @chelseabfinn, @NimaFazeli7, @SLED_AI at #CVPR2026 — a preview of our ICML Oral (0.7%) 🔥
Join us tmr (June 4), Room 703, 3:45 PM
🚀 RoboMME is accepted to ICML 2026 (Spotlight)! 🎉
Excited to push the frontier of memory-augmented robot manipulation 🤖🧠
We’re also hosting the challenge @ CVPR 2026 (FMEA workshop) - join us to build next-gen memory-based robotic policies! 💪🔥
🔗 https://t.co/79FpVd1ti3
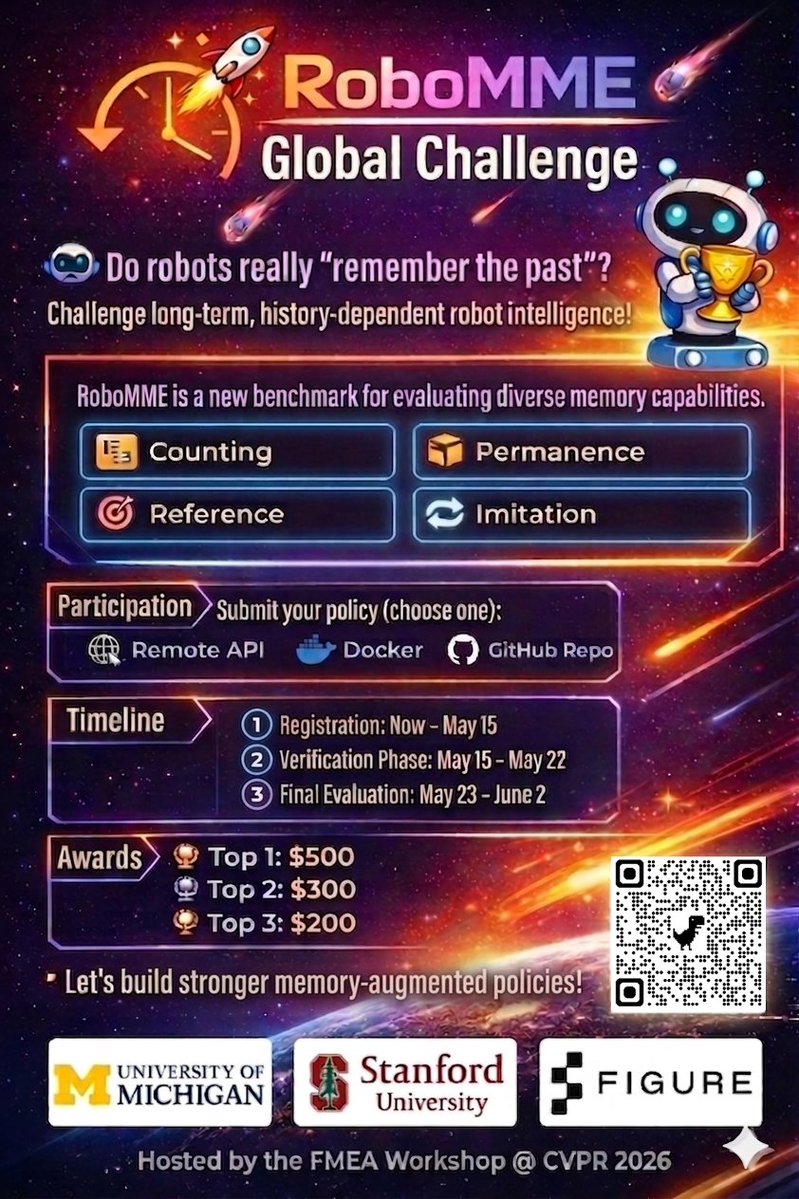
🚀 The RoboMME Challenge @ CVPR 2026 is now LIVE!
Timeline:
• May 15 — Policy submission
• June 3 — Winner announcement
🏆 Top 3 teams will be awarded $500/300/200
Let’s push the frontier for memory-augmented robotic manipulation together 💪
🔗https://t.co/79FpVd1ti3
@hirasava_ui Thanks so much! MIKASA-Robo was a great inspiration when we were building RoboMME — really glad to see more work pushing on memory in robot learning. Excited to see where you take the VLA direction!